Rotational Dynamics and Torque
4. Newton's Second Law for Rotation
Learning outcomes
- I can state the rotational form of Newton's Second Law.
- I can relate torque, moment of inertia, and angular acceleration.
- I can solve rotational dynamics problems.
- I can compare rotational and translational dynamics.
- I can analyze systems experiencing angular acceleration.
Newton's Second Law for Rotation
Newton's Second Law has a rotational form that describes how net torque produces angular acceleration.
In linear motion, a net force changes an object's linear velocity. In rotational motion, a net torque changes an object's angular velocity.
The rotational form of Newton's Second Law is:
Στ = Iα
where:
- Στ = net torque acting on the object
- I = moment of inertia
- α = angular acceleration
This relationship is one of the central equations of rotational dynamics.


From Linear Dynamics to Rotational Dynamics
Newton's Second Law for linear motion is:
ΣF = ma
The rotational equivalent is:
Στ = Iα
The quantities have direct parallels:
| Translational Motion | Rotational Motion |
|---|---|
| Force F | Torque τ |
| Mass m | Moment of inertia I |
| Linear acceleration a | Angular acceleration α |
| ΣF = ma | Στ = Iα |
Mass describes resistance to linear acceleration.
Moment of inertia describes resistance to angular acceleration.
Force produces linear acceleration.
Torque produces angular acceleration.
Understanding Στ = Iα
The equation tells us that angular acceleration depends on both:
- the net torque
- the moment of inertia
Rearranging:
α = Στ/I
Therefore, for a particular object:
larger net torque → larger angular acceleration
For a particular torque:
larger moment of inertia → smaller angular acceleration
Torque Produces Angular Acceleration
A force can produce torque when its line of action does not pass directly through the axis of rotation.
For a force applied at distance r:
τ = rF sin θ
For a perpendicular force:
τ = rF
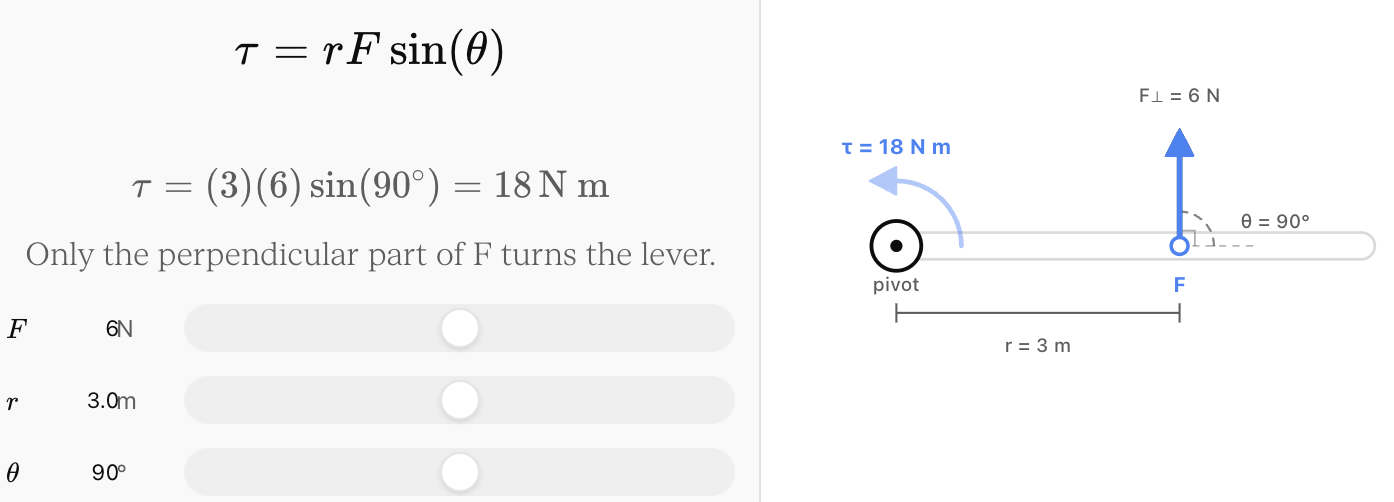
Increasing the force, increasing the lever arm, or making the force more perpendicular can increase the torque and therefore increase the angular acceleration.
Worked Example: Simple Rotational Dynamics
A wheel has moment of inertia:
I = 4.0 kg·m²
A net torque of:
τ = 12 N·m
acts on it.
Find its angular acceleration.
Use:
Στ = Iα
Rearrange:
α = Στ/I
α = 12/4.0
α = 3.0 rad/s²
The wheel's angular velocity changes by 3.0 rad/s each second.
Increasing the Torque
Suppose the same wheel experiences:
τ = 24 N·m
Then:
α = 24/4.0
α = 6.0 rad/s²
Doubling the net torque doubled the angular acceleration.
For constant I:
α ∝ τ
Increasing the Moment of Inertia
Now suppose:
τ = 12 N·m
but:
I = 8.0 kg·m²
Then:
α = 12/8.0
α = 1.5 rad/s²
Compared with the original 4.0 kg·m² wheel, doubling the moment of inertia halved the angular acceleration.
For constant torque:
α ∝ 1/I
Why Moment of Inertia Matters
Moment of inertia depends on:
- total mass
- shape
- size
- mass distribution
- axis of rotation
Moving mass farther from the axis generally increases I.
Therefore, the same torque produces less angular acceleration when more of the object's mass is distributed far from the axis.


Example: Moving Mass Outward
Suppose a rotating system initially has:
I = 2.0 kg·m²
and experiences:
τ = 10 N·m
Then:
α = 10/2.0
α = 5.0 rad/s²
The masses are then moved outward so that:
I = 5.0 kg·m²
With the same torque:
α = 10/5.0
α = 2.0 rad/s²
Moving the mass outward made the system more resistant to angular acceleration.
Net Torque
Usually, more than one torque acts on an object.
Newton's Second Law uses the net torque:
Στ = τ₁ + τ₂ + τ₃ + ...
A common sign convention is:
counterclockwise = positive
clockwise = negative
The torques must therefore be added with their signs before using:
Στ = Iα
Worked Example: Opposing Torques
A disk experiences:
- 18 N·m counterclockwise
- 6 N·m clockwise
Take counterclockwise as positive.
Στ = +18 − 6
Στ = +12 N·m
If:
I = 3.0 kg·m²
then:
α = 12/3.0
α = +4.0 rad/s²
The positive sign indicates angular acceleration in the counterclockwise direction.
Several Torques
Suppose a rotating object experiences:
- +20 N·m
- −8 N·m
- −5 N·m
- +3 N·m
Then:
Στ = 20 − 8 − 5 + 3
Στ = +10 N·m
If:
I = 2.5 kg·m²
then:
α = 10/2.5
α = +4.0 rad/s²
Always calculate the net torque before calculating angular acceleration.
Zero Net Torque
If:
Στ = 0
then:
Στ = Iα
0 = Iα
Therefore:
α = 0
This means the object's angular velocity does not change.
The object could be:
- stationary
- rotating at constant angular velocity
Zero net torque does not necessarily mean zero angular velocity.
Rotational Equilibrium
When:
Στ = 0
an object is in rotational equilibrium.
For example, if:
τ_CCW = +25 N·m
and:
τ_CW = −25 N·m
then:
Στ = 0
and:
α = 0
This connects Newton's Second Law for rotation directly to rotational equilibrium.
Torque from an Applied Force
Suppose a force of:
40 N
acts perpendicular to a lever:
0.50 m
from the axis.
Torque:
τ = rF
τ = (0.50)(40)
τ = 20 N·m
If the rotating system has:
I = 5.0 kg·m²
then:
α = τ/I
α = 20/5.0
α = 4.0 rad/s²
This type of problem requires two steps:
- calculate torque
- use Στ = Iα
Force Applied at an Angle
Suppose:
F = 60 N
r = 0.40 m
θ = 30°
Then:
τ = rF sin θ
τ = (0.40)(60)(sin 30°)
τ = (0.40)(60)(0.50)
τ = 12 N·m
If:
I = 3.0 kg·m²
then:
α = 12/3.0
α = 4.0 rad/s²
Only the component of the force perpendicular to the lever arm contributes to torque.
Force Through the Axis
If a force's line of action passes directly through the rotation axis:
τ = 0
Even a very large force can produce no angular acceleration if it produces no torque.
This explains why the location and direction of a force matter in rotational dynamics.
Force Applied at Different Distances
Suppose a 20 N perpendicular force acts on a wheel.
At:
r = 0.10 m
τ = (0.10)(20)
τ = 2 N·m
At:
r = 0.50 m
τ = (0.50)(20)
τ = 10 N·m
The same force produces five times the torque when applied five times farther from the axis.
If I remains constant, it also produces five times the angular acceleration.
Door Example
A door provides a simple example of rotational dynamics.
The hinges form the rotation axis.
If you push close to the hinges:
- r is small
- torque is small
- angular acceleration is small
If you push at the handle:
- r is larger
- torque is larger
- angular acceleration is larger
This is why door handles are placed far from the hinges.


Rotating Disk
For a solid disk rotating around its central axis:
I = 1/2 MR²
Suppose:
M = 6.0 kg
R = 0.40 m
First calculate I:
I = 1/2(6.0)(0.40²)
I = 3.0(0.16)
I = 0.48 kg·m²
If a net torque of:
2.4 N·m
acts on the disk:
α = 2.4/0.48
α = 5.0 rad/s²
From Angular Acceleration to Angular Velocity
Once angular acceleration is known, rotational kinematics can be used.
For constant α:
ω_f = ω_i + αt
Suppose the disk in the previous example starts from rest and the torque acts for:
4.0 s
Then:
ω_f = 0 + (5.0)(4.0)
ω_f = 20 rad/s
Rotational dynamics determines α.
Rotational kinematics then describes the resulting motion.
Finding Angular Displacement
For constant angular acceleration:
Δθ = ω_i t + 1/2 αt²
For the same disk:
ω_i = 0
α = 5.0 rad/s²
t = 4.0 s
Then:
Δθ = 1/2(5.0)(4.0²)
Δθ = 2.5(16)
Δθ = 40 rad
Number of revolutions:
N = 40/(2π)
N ≈ 6.37 revolutions
Dynamics and Kinematics Work Together
A common rotational problem may require several stages.
Dynamics
Use the forces to calculate torque:
τ = rF sin θ
Newton's Second Law
Use torque to calculate angular acceleration:
Στ = Iα
Kinematics
Use angular acceleration to calculate motion:
ω_f = ω_i + αt
or:
Δθ = ω_i t + 1/2 αt²
This chain is extremely important:
force → torque → angular acceleration → rotational motion
Comparing Translational and Rotational Problem Solving
The same pattern appears in linear mechanics.
Linear
force → linear acceleration → linear motion
ΣF = ma
then use equations such as:
v_f = v_i + at
Rotational
torque → angular acceleration → rotational motion
Στ = Iα
then use:
ω_f = ω_i + αt
The mathematics and reasoning are closely related.
Complete Linear-Rotational Comparison
| Translational | Rotational |
|---|---|
| Position x | Angular position θ |
| Displacement Δx | Angular displacement Δθ |
| Velocity v | Angular velocity ω |
| Acceleration a | Angular acceleration α |
| Mass m | Moment of inertia I |
| Force F | Torque τ |
| ΣF = ma | Στ = Iα |
| p = mv | L = Iω |
| E_k = 1/2 mv² | E_rot = 1/2 Iω² |
These parallels help organize rotational mechanics.
A Wheel Driven by a Force
Consider a solid wheel with:
M = 8.0 kg
R = 0.50 m
A tangential force of:
F = 12 N
acts at its edge.
Assume no other torque.
Torque
τ = rF
τ = (0.50)(12)
τ = 6.0 N·m
Moment of Inertia
For a solid disk:
I = 1/2 MR²
I = 1/2(8.0)(0.50²)
I = 4(0.25)
I = 1.0 kg·m²
Angular Acceleration
α = τ/I
α = 6.0/1.0
α = 6.0 rad/s²
If it begins from rest, after 3 s:
ω = αt
ω = (6.0)(3)
ω = 18 rad/s
A Ring Under the Same Conditions
Now replace the solid disk with a thin ring having the same:
- mass
- radius
- applied force
For a ring:
I = MR²
I = (8.0)(0.50²)
I = 2.0 kg·m²
The torque remains:
6.0 N·m
Therefore:
α = 6.0/2.0
α = 3.0 rad/s²
The ring has twice the moment of inertia, so it has half the angular acceleration.


Why Shape Matters
The disk and ring have:
- the same mass
- the same radius
- the same applied force
- the same torque
Yet they have different angular accelerations.
The reason is their different mass distributions.
For the ring, more mass lies far from the axis.
Therefore:
I_ring > I_disk
and consequently:
α_ring < α_disk
for the same torque.
Rod Rotating About Its Centre
For a uniform rod rotating about its centre:
I = 1/12 ML²
Suppose:
M = 3.0 kg
L = 2.0 m
Then:
I = 1/12(3.0)(2.0²)
I = 1.0 kg·m²
If:
τ = 4.0 N·m
then:
α = 4.0/1.0
α = 4.0 rad/s²
Rod Rotating About One End
For the same rod rotating about one end:
I = 1/3 ML²
I = 1/3(3.0)(2.0²)
I = 4.0 kg·m²
With the same torque:
α = 4.0/4.0
α = 1.0 rad/s²
Changing the axis changed the moment of inertia and therefore changed the angular acceleration.
Pulley Systems
Newton's Second Law for rotation is particularly useful for pulleys.
A tension force acting on the edge of a pulley produces torque:
τ = rT
If two different tensions act on opposite sides:
τ_net = (T₁ − T₂)r
depending on the chosen direction.
Then:
(T₁ − T₂)r = Iα


Linear and Angular Acceleration in a Pulley
If a rope does not slip on the pulley:
a = rα
Therefore:
α = a/r
This connects the rotational motion of the pulley to the linear motion of the rope and attached masses.
Worked Pulley Example
A pulley has:
I = 0.50 kg·m²
r = 0.20 m
Two tensions act:
T₁ = 30 N
T₂ = 20 N
Net torque:
τ_net = (T₁ − T₂)r
τ_net = (30 − 20)(0.20)
τ_net = 2.0 N·m
Angular acceleration:
α = τ/I
α = 2.0/0.50
α = 4.0 rad/s²
The linear acceleration of the rope is:
a = rα
a = (0.20)(4.0)
a = 0.80 m/s²
Why Real Pulleys Matter
In introductory problems, pulleys are sometimes treated as massless.
A massless pulley is assumed to have negligible moment of inertia.
A real pulley has:
I > 0
so some of the system's torque is required to angularly accelerate it.
This can make the acceleration of a real system smaller than the acceleration predicted using an ideal massless pulley.
Rotational Dynamics of Gears
For meshing gears, forces at the contact points produce torques.
Because:
τ = rF
a larger gear can experience a larger torque from the same tangential force.
However, its moment of inertia may also be larger.
The resulting angular acceleration depends on:
α = τ/I
Therefore, gear behaviour depends on both torque and rotational inertia.


Motors and Rotational Dynamics
Electric motors generate torque.
If a motor produces approximately constant net torque:
α = τ/I
A motor can accelerate a low-inertia system quickly.
A high-inertia system accelerates more slowly unless the motor provides greater torque.
This is important when selecting motors for:
- robots
- conveyor systems
- elevators
- manufacturing equipment
- electric vehicles
Frictional Torque
Friction can oppose rotation and produce a torque opposite the motion.
Suppose a motor produces:
τ_motor = +30 N·m
while friction produces:
τ_friction = −6 N·m
Then:
Στ = 30 − 6
Στ = 24 N·m
If:
I = 8 kg·m²
then:
α = 24/8
α = 3 rad/s²
The motor's torque is not necessarily the same as the net torque.
Braking Torque
Brakes deliberately produce torque opposite the angular velocity.
Suppose a wheel rotates counterclockwise, so:
ω > 0
A braking torque acts clockwise:
τ < 0
Therefore:
α < 0
and the wheel slows down.
Worked Braking Example
A wheel has:
I = 2.0 kg·m²
ω_i = 24 rad/s
A constant braking torque of:
−8.0 N·m
is applied.
Angular acceleration:
α = τ/I
α = −8.0/2.0
α = −4.0 rad/s²
Stopping time:
ω_f = ω_i + αt
0 = 24 − 4t
t = 6.0 s
Angular Displacement While Braking
For the same wheel:
Δθ = [(ω_i + ω_f)/2]t
Δθ = (24 + 0)/2
Δθ = 12(6)
Δθ = 72 rad
Number of revolutions:
N = 72/(2π)
N ≈ 11.5 revolutions
The wheel completes more than 11 rotations while stopping.
Rotational Direction and Signs
Choosing a sign convention is essential.
For example:
counterclockwise = positive
Then:
- counterclockwise torque → positive τ
- clockwise torque → negative τ
- positive α → angular velocity changes counterclockwise
- negative α → angular velocity changes clockwise
The sign of α does not by itself tell you whether the object is speeding up.
Compare α with ω.
Speeding Up and Slowing Down
If ω and α have the same sign:
rotational speed increases
If ω and α have opposite signs:
rotational speed decreases
For example:
ω = +10 rad/s
α = −2 rad/s²
The object is rotating counterclockwise but slowing down.
If:
ω = −10 rad/s
α = −2 rad/s²
the object is rotating clockwise and speeding up.
Newton's Second Law and Rotational Equilibrium
Newton's Second Law also explains rotational equilibrium.
If:
Στ = 0
then:
Iα = 0
and:
α = 0
If the object is initially stationary, it remains rotationally stationary unless a net torque acts.
This is the rotational counterpart of Newton's First Law.
Rotational Dynamics and Energy
Torque can also transfer energy to a rotating object.
For constant torque acting through angular displacement:
W = τΔθ
The rotational kinetic energy is:
E_rot = 1/2 Iω²
The work-energy relationship becomes:
W_net = ΔE_rot
This provides another way to analyze some rotational systems.
Worked Energy Example
A constant torque of:
10 N·m
rotates a wheel through:
20 rad
Work done:
W = τΔθ
W = (10)(20)
W = 200 J
If the wheel begins from rest and losses are negligible:
E_rot = 200 J
If:
I = 4.0 kg·m²
then:
200 = 1/2(4.0)ω²
200 = 2ω²
ω² = 100
ω = 10 rad/s
A Complete Rotational Dynamics Problem
A solid disk has:
M = 12 kg
R = 0.50 m
A tangential force of:
F = 18 N
acts at its edge.
A frictional torque of:
1.5 N·m
opposes the motion.
The disk begins from rest.
Find its angular acceleration and angular velocity after 5.0 s.
Applied Torque
τ_applied = rF
τ_applied = (0.50)(18)
τ_applied = 9.0 N·m
Net Torque
τ_net = 9.0 − 1.5
τ_net = 7.5 N·m
Moment of Inertia
For a solid disk:
I = 1/2 MR²
I = 1/2(12)(0.50²)
I = 6(0.25)
I = 1.5 kg·m²
Angular Acceleration
α = τ_net/I
α = 7.5/1.5
α = 5.0 rad/s²
Angular Velocity
ω_f = ω_i + αt
ω_f = 0 + (5.0)(5.0)
ω_f = 25 rad/s
This problem combines force, torque, moment of inertia and rotational kinematics.
Analyzing Rotational Systems
A useful approach is to work through the system in a logical sequence.
Identify the rotation axis.
All torques and moments of inertia must refer to the same axis.
Draw the forces.
Identify which forces produce torque.
Choose a positive rotational direction.
Usually counterclockwise is positive.
Calculate each torque.
Use:
τ = rF sin θ
or the perpendicular moment arm.
Calculate net torque.
Add the torques with their signs.
Determine the moment of inertia.
Use the appropriate expression for the object's mass distribution.
Apply Newton's Second Law.
Στ = Iα
Use rotational kinematics if necessary.
Once α is known, determine ω, θ, or t.
Common Mistakes
Using an individual torque instead of net torque
Newton's Second Law uses:
Στ
not simply the largest torque.
Forgetting torque direction
Clockwise and counterclockwise torques should have opposite signs.
Confusing torque with force
Force and torque are related but different quantities.
Ignoring the lever arm
A force through the axis produces no torque.
Using mass instead of moment of inertia
The rotational equation is:
Στ = Iα
not τ = mα.
Ignoring mass distribution
Moment of inertia depends on where the mass lies relative to the axis.
Assuming larger torque always means larger α
Moment of inertia must also be considered.
Assuming larger I means faster rotation
A larger I means greater resistance to changes in angular velocity.
Forgetting frictional torque
Applied torque and net torque may not be the same.
Confusing angular velocity with angular acceleration
Torque produces angular acceleration, not directly angular velocity.
Using linear acceleration where angular acceleration is required
Use α in rad/s².
Using rotational kinematics before finding α
In many dynamics problems, first calculate net torque and I, then determine α.
Key Terms
Newton's Second Law for rotation — relationship between net torque, moment of inertia and angular acceleration.
Net torque (Στ) — sum of all torques acting about an axis, including their directions.
Torque (τ) — turning effect of a force about an axis.
Moment of inertia (I) — measure of an object's resistance to angular acceleration.
Angular acceleration (α) — rate of change of angular velocity.
Lever arm — distance associated with the turning effect of a force.
Axis of rotation — line around which an object rotates.
Rotational dynamics — study of the torques and rotational inertia responsible for rotational motion.
Rotational equilibrium — condition in which net torque is zero.
Frictional torque — torque that opposes rotational motion.
Braking torque — torque deliberately applied opposite the rotation to reduce angular velocity.
Tangential force — force acting tangent to a circular path and therefore perpendicular to the radius.
Angular velocity (ω) — rate of change of angular position.
Rotational kinetic energy — kinetic energy associated with rotation, E_rot = 1/2 Iω².
Rotational work — energy transferred by torque acting through an angular displacement.
Key Takeaways
- Newton's Second Law for rotation is Στ = Iα.
- Net torque plays the rotational role that net force plays in linear motion.
- Moment of inertia plays the rotational role that mass plays in linear motion.
- Angular acceleration plays the rotational role that linear acceleration plays in linear motion.
- For constant I, greater net torque produces greater angular acceleration.
- For constant net torque, greater moment of inertia produces smaller angular acceleration.
- Torque depends on the applied force, its distance from the axis, and its direction.
- For a perpendicular force, τ = rF.
- Multiple torques must be combined to determine net torque.
- Clockwise and counterclockwise torques have opposite signs.
- If Στ = 0, then α = 0.
- Zero angular acceleration does not necessarily mean zero angular velocity.
- Mass distribution affects rotational dynamics through moment of inertia.
- A ring and a disk can respond differently to the same torque even if they have the same mass and radius.
- Frictional torque reduces the net torque available for angular acceleration.
- Braking torque can produce angular acceleration opposite to the angular velocity.
- Dynamics determines angular acceleration; kinematics can then determine angular velocity and displacement.
- Pulley systems connect rotational and linear motion through a = rα.
- Work done by a constant torque can be calculated using W = τΔθ.
- Rotational kinetic energy is E_rot = 1/2 Iω².
- Newton's laws provide a unified framework for both translational and rotational dynamics.
Check Your Understanding
- State Newton's Second Law for rotation and define each quantity.
- An object has moment of inertia 4.0 kg·m² and experiences a net torque of 20 N·m. Calculate its angular acceleration.
- The same torque acts on an object with twice the moment of inertia. Calculate its angular acceleration and explain the change.
- A 30 N force acts perpendicular to a lever 0.40 m from its axis. Calculate the torque.
- If the system in Question 4 has I = 3.0 kg·m², calculate its angular acceleration.
- A disk experiences +25 N·m, −10 N·m, and −5 N·m of torque. If I = 2.0 kg·m², calculate the net torque and angular acceleration.
- Explain why a force directed through the rotation axis produces no angular acceleration even if the force is large.
- A solid disk has mass 8.0 kg and radius 0.50 m. Calculate its moment of inertia. If a net torque of 6.0 N·m acts on it, calculate its angular acceleration.
- A thin ring has the same mass and radius as the disk in Question 8. Calculate its angular acceleration under the same torque and explain why the result differs.
- A wheel has I = 3.0 kg·m² and initially rotates at 20 rad/s. A constant braking torque of −6.0 N·m is applied. Calculate its angular acceleration and the time required to stop.
- For Question 10, calculate the angular displacement while the wheel is stopping.
- A pulley has I = 0.80 kg·m² and radius 0.25 m. Tensions of 40 N and 24 N act on opposite sides. Calculate the net torque, angular acceleration, and linear acceleration of the rope.
- A motor provides 30 N·m of torque while friction provides an opposing torque of 6 N·m. The rotating machinery has I = 8.0 kg·m². If it starts from rest, calculate its angular acceleration and angular velocity after 10 s.
- Explain how moving mass farther from an axis affects moment of inertia and the angular acceleration produced by a fixed torque.
- A solid disk of mass 10 kg and radius 0.40 m starts from rest. A 25 N tangential force acts at its rim while friction produces an opposing torque of 2.0 N·m. Calculate the applied torque, net torque, moment of inertia, angular acceleration, angular velocity after 5.0 s, and angular displacement during those 5.0 s.