Applications of Advanced Trigonometry
1. Wave Motion
Learning outcomes
- I can model wave behaviour using trigonometric functions.
- I can interpret phase relationships.
- I can analyse interference patterns.
- I can solve problems involving oscillations.
- I can connect mathematical models to physical systems.
Wave Motion
Introduction to Wave Motion
Waves are disturbances that transfer energy from one location to another. They occur throughout nature and technology, including sound, light, water waves, earthquakes, radio signals, and vibrations in mechanical systems.
Many waves exhibit repeating patterns that can be described mathematically using sine and cosine functions.
Trigonometric models allow us to calculate wave displacement, amplitude, frequency, wavelength, phase, and interference.
For example, mathematics can help us determine:
-
How far a vibrating object moves from its equilibrium position.
-
How frequently a wave oscillates.
-
Whether two waves reinforce or cancel each other.
-
How the position of a wave changes with time.
-
How wave speed depends on frequency and wavelength.
-
How mathematical wave models relate to real physical systems.
Wave motion provides one of the most important applications of trigonometry in physics and engineering.


Understanding Wave Motion
A wave is a disturbance that travels through a medium or through space, transferring energy.
Two major types of waves are transverse and longitudinal waves.
Transverse Waves
In a transverse wave, the oscillations are perpendicular to the direction of wave propagation.
Examples include:
-
Waves on a stretched string.
-
Electromagnetic waves.
-
Certain seismic waves.
Longitudinal Waves
In a longitudinal wave, the oscillations are parallel to the direction of propagation.
Examples include:
-
Sound waves in air.
-
Compression waves in springs.
-
Certain seismic waves.
Both types of waves can exhibit sinusoidal behaviour, although the physical meaning of displacement differs.


Describing Waves Using Trigonometric Functions
A sinusoidal oscillation can be modelled using:
y = A sin(ωt + φ)
or:
y = A cos(ωt + φ)
where:
-
y = displacement from equilibrium.
-
A = amplitude.
-
ω = angular frequency.
-
t = time.
-
φ = initial phase angle.
The sine and cosine functions are useful because they repeat regularly and smoothly.
Example
Consider:
y = 4 sin(2πt)
This describes an oscillation with:
-
Amplitude = 4 units.
-
Angular frequency = 2π rad/s.
-
Frequency = 1 Hz.
-
Period = 1 s.
-
Initial phase = 0 radians.
The displacement changes continuously between −4 and +4.
Visualizing a Sinusoidal Wave
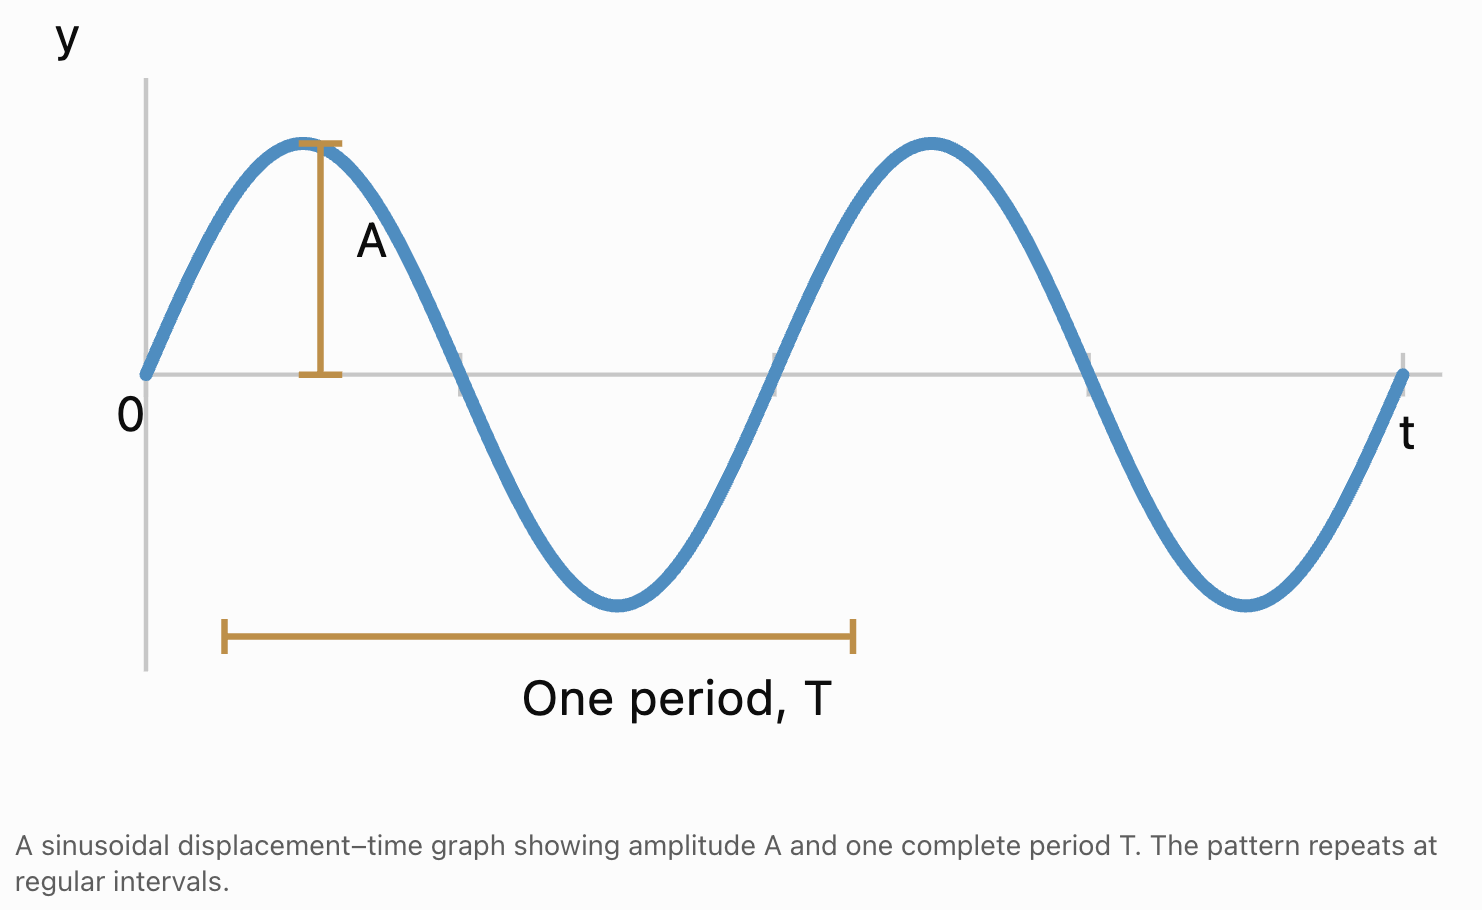
Important Features
Equilibrium position: The central position about which the oscillation occurs.
Amplitude: The maximum displacement from equilibrium.
Crest: The highest point of a transverse wave.
Trough: The lowest point of a transverse wave.
Period: The time required for one complete oscillation.
Frequency: The number of complete oscillations per second.
Amplitude
The amplitude of a wave is its maximum displacement from equilibrium.
For:
y = A sin(ωt + φ)
the amplitude is:
|A|
Example
Consider:
y = 7 sin(3t)
The amplitude is:
7 units
The displacement varies between:
−7 and +7
Negative Coefficients
For:
y = −5 cos(2t)
the amplitude is still:
5 units
The negative sign reflects the graph vertically; it does not produce a negative amplitude.
Physical Meaning
Amplitude may represent:
-
Displacement of a vibrating string.
-
Pressure variation in a sound wave.
-
Electric-field strength in an electromagnetic wave.
-
Height variation of a water surface.
The precise physical meaning depends on the system being modelled.
Period and Frequency
The period, T, is the time required for one complete oscillation.
The frequency, f, is the number of oscillations per second.
Their relationship is:
f = 1/T
and:
T = 1/f
Frequency is measured in hertz (Hz).
One hertz means one complete oscillation per second.
Worked Example
A wave completes 25 oscillations in five seconds.
Frequency:
f = 25/5
f = 5 Hz
Period:
T = 1/5
T = 0.2 s
The wave completes five oscillations each second.
Angular Frequency
Angular frequency describes how quickly the phase of an oscillation changes.
It is represented by ω.
ω = 2πf
Since f = 1/T:
ω = 2π/T
Angular frequency is measured in radians per second.
Worked Example
A vibrating object has a frequency of 8 Hz.
Calculate its angular frequency.
ω = 2π × 8
ω = 16π rad/s
Approximately:
ω ≈ 50.27 rad/s
Relationship to the Graph
For:
y = A sin(ωt)
the period is:
T = 2π/|ω|
A larger angular frequency produces more oscillations in the same time interval.
Worked Example: Analysing a Trigonometric Model
Consider:
y = 6 sin(4πt)
where y is measured in centimetres and t in seconds.
Find the amplitude, period, frequency, and angular frequency.
Amplitude
A = 6 cm
Angular Frequency
ω = 4π rad/s
Period
T = 2π/(4π)
T = 0.5 s
Frequency
f = 1/0.5
f = 2 Hz
Interpretation
The object moves between −6 cm and +6 cm and completes two oscillations every second.
Phase and Phase Angle
The phase of an oscillation describes its position within the repeating cycle.
For:
y = A sin(ωt + φ)
the quantity:
ωt + φ
is the instantaneous phase.
The constant φ is the initial phase angle.
Phase is measured in radians or degrees.
Common Phase Angles
|
Phase angle |
Radians |
Fraction of cycle |
|---|---|---|
|
0° |
0 |
0 |
|
90° |
π/2 |
1/4 |
|
180° |
π |
1/2 |
|
270° |
3π/2 |
3/4 |
|
360° |
2π |
1 |
A phase change of 2π radians represents one complete cycle.
Phase Shifts
Consider:
y₁ = sin(ωt)
and:
y₂ = sin(ωt + π/2)
The second oscillation has a phase lead of π/2 radians.
This corresponds to one-quarter of a cycle.
For a positive angular frequency, the graph of y₂ is shifted to the left by:
Δt = (π/2)/ω
General Formula
For two oscillations of the same angular frequency:
Phase difference = Δφ
The corresponding time difference is:
Δt = |Δφ|/ω
This uses a chosen phase difference, typically reduced to the interval from 0 to π when comparing the smallest separation between corresponding features.
Example
Two oscillations have frequency 10 Hz and a phase difference of π/2 radians.
Angular frequency:
ω = 2π × 10 = 20π rad/s
Time difference:
Δt = (π/2)/(20π)
Δt = 0.025 s
The oscillations differ by 0.025 seconds, or one-quarter of their 0.1-second period.
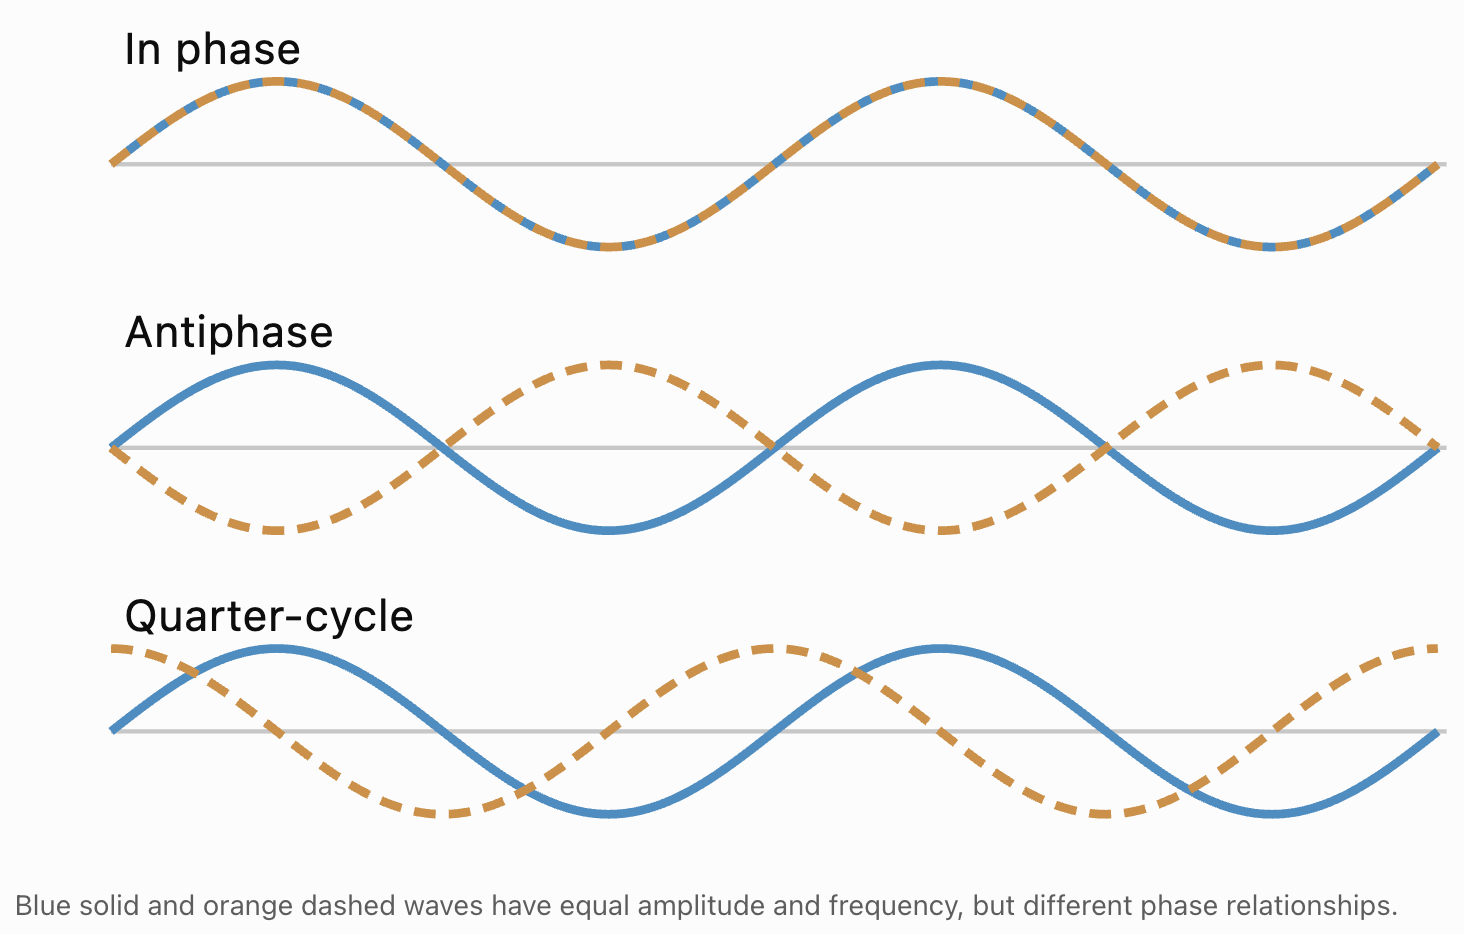
Comparing Phase Relationships
Two waves may be in phase, out of phase, or have an intermediate phase difference.
In Phase
Two waves are in phase when corresponding crests, troughs, and zero crossings occur together.
Their phase difference is:
Δφ = 0, or any whole multiple of 2π
In Antiphase
Two waves are in antiphase when one wave reaches a crest as the other reaches a trough.
Their phase difference is:
Δφ = π, or an odd multiple of π
Intermediate Phase Differences
A phase difference of π/2 corresponds to a quarter-cycle separation.
Wavelength and Wave Speed
The wavelength, λ, is the distance between two consecutive points in the same phase, such as two neighbouring crests.
The wave speed, v, is the speed at which the wave pattern propagates.
The relationship is:
v = fλ
where:
-
v = wave speed in m/s.
-
f = frequency in Hz.
-
λ = wavelength in metres.
Rearranging
f = v/λ
λ = v/f
Worked Example
A wave travels at 24 m/s and has a frequency of 6 Hz.
Find its wavelength.
λ = v/f
= 24/6
λ = 4 m
The distance between consecutive crests is four metres.
The Travelling Wave Equation
A wave travelling through space can be represented using both position and time.
For a sinusoidal wave travelling in the positive x-direction:
y(x,t) = A sin(kx − ωt + φ)
where:
-
A = amplitude.
-
k = wave number.
-
x = position.
-
ω = angular frequency.
-
t = time.
-
φ = phase constant.
The wave number is:
k = 2π/λ
Wave Speed
The speed of the wave is:
v = ω/k
Since:
ω = 2πf
and:
k = 2π/λ
then:
v = (2πf)/(2π/λ)
Therefore:
v = fλ
Direction of Propagation
For positive k and ω:
kx − ωt describes motion in the positive x-direction.
kx + ωt describes motion in the negative x-direction.
This distinction is important when interpreting travelling-wave equations.
Worked Example: Analysing a Travelling Wave
Consider the wave equation:
y(x,t) = 0.04 sin(2πx − 8πt)
where x and y are measured in metres and t in seconds.
Determine the amplitude, wavelength, frequency, period, and wave speed.
Step 1: Identify the Amplitude
A = 0.04 m
Amplitude = 4 cm
Step 2: Identify the Wave Number
k = 2π rad/m
Since:
k = 2π/λ
λ = 2π/(2π)
λ = 1 m
Step 3: Identify the Angular Frequency
ω = 8π rad/s
Since:
ω = 2πf
f = 8π/(2π)
f = 4 Hz
Step 4: Calculate the Period
T = 1/f
T = 0.25 s
Step 5: Calculate the Wave Speed
v = fλ
= 4 × 1
v = 4 m/s
Interpretation
The wave has an amplitude of 4 cm, completes four oscillations each second, and travels in the positive x-direction at 4 m/s.
The Principle of Superposition
When two or more waves overlap, their individual displacements add together.
This is called the principle of superposition.
For two waves:
y_resultant = y₁ + y₂
The waves may reinforce each other or partially or completely cancel.
Superposition applies to linear wave systems, where the disturbances do not permanently alter each other's propagation.
Constructive Interference
Constructive interference occurs when overlapping waves reinforce each other.
For two identical sinusoidal waves that are in phase:
y₁ = A sin(ωt)
y₂ = A sin(ωt)
Their resultant displacement is:
y_resultant = 2A sin(ωt)
The resultant amplitude is:
A_resultant = 2A
Example
Two waves each have an amplitude of 3 cm and are perfectly in phase.
Resultant amplitude:
3 + 3
= 6 cm
The maximum displacement is doubled.

Destructive Interference
Destructive interference occurs when overlapping waves oppose each other.
For two identical sinusoidal waves in antiphase:
y₁ = A sin(ωt)
y₂ = A sin(ωt + π)
Since:
sin(θ + π) = −sin(θ)
then:
y₂ = −A sin(ωt)
Therefore:
y_resultant = 0
The two waves cancel completely.
Important Condition
Complete cancellation requires waves with equal amplitudes and a phase difference of an odd multiple of π.
If the amplitudes differ, the waves may only partially cancel.
For example, two waves with amplitudes of 5 cm and 3 cm in antiphase produce a resultant amplitude of:
|5 − 3| = 2 cm
Interference and Phase Difference
When two waves have the same frequency and equal amplitude A, but a phase difference Δφ, their resultant amplitude is:
A_resultant = 2A|cos(Δφ/2)|
This follows from the trigonometric identity:
sin α + sin β = 2 sin[(α + β)/2] cos[(α − β)/2]
Worked Example
Two waves each have an amplitude of 4 cm and a phase difference of 120°.
Calculate the resultant amplitude.
A_resultant = 2 × 4 × |cos(120°/2)|
= 8 × |cos 60°|
= 8 × 0.5
A_resultant = 4 cm
Interpretation
The resultant amplitude is smaller than the maximum possible amplitude of 8 cm because the waves are not in phase.
Comparing Phase Differences
|
Phase difference |
Resultant amplitude for equal waves |
|---|---|
|
0° |
2A |
|
60° |
√3 A |
|
90° |
√2 A |
|
120° |
A |
|
180° |
0 |
This relationship is useful when analysing interference patterns.
Path Difference and Interference
When waves travel different distances before meeting, they may arrive with different phases.
The path difference, Δd, is the difference between the distances travelled.
For coherent waves with the same wavelength:
Δφ = 2πΔd/λ
This assumes the sources begin in phase. Otherwise, the initial phase difference must also be included.
Constructive Interference
For in-phase sources, constructive interference occurs when:
Δd = mλ
where m is an integer.
Examples include:
0, λ, 2λ, 3λ ...
Destructive Interference
For in-phase sources, destructive interference occurs when:
Δd = (m + 1/2)λ
Examples include:
λ/2, 3λ/2, 5λ/2 ...
Worked Example
Two coherent water waves have a wavelength of 0.8 m.
At a particular point, the path difference is 1.2 m.
Calculate:
Δd/λ = 1.2/0.8
= 1.5
The path difference is 1.5 wavelengths.
Therefore, the waves arrive in antiphase and produce destructive interference if their amplitudes are equal.

Standing Waves
A standing wave is formed when two waves of equal frequency and amplitude travel in opposite directions and interfere.
For example:
y₁ = A sin(kx − ωt)
y₂ = A sin(kx + ωt)
Adding the waves gives:
y = 2A sin(kx) cos(ωt)
This describes a standing wave.
Unlike a travelling wave, the pattern does not move along the medium.
Instead, different positions oscillate with different amplitudes.
Nodes
A node is a point where the displacement is always zero.
For the standing-wave equation:
sin(kx) = 0
Therefore:
kx = nπ
Since k = 2π/λ:
x = nλ/2
Adjacent nodes are separated by:
λ/2
Antinodes
An antinode is a point where the oscillation amplitude is greatest.
Antinodes occur halfway between adjacent nodes.
Examples of Standing Waves
-
Vibrating guitar strings.
-
Organ pipes.
-
Resonating air columns.
-
Certain microwave cavities.
-
Vibrations in mechanical structures.

Standing Waves on a String
Consider a string fixed at both ends.
Both ends must be nodes.
For a string of length L, the allowed wavelengths are:
λₙ = 2L/n
where:
n = 1, 2, 3, ...
The corresponding frequencies are:
fₙ = nv/(2L)
where v is the wave speed.
Fundamental Frequency
For n = 1:
f₁ = v/(2L)
This is the lowest resonant frequency.
Harmonics
Higher frequencies are integer multiples of the fundamental frequency:
f₂ = 2f₁
f₃ = 3f₁
f₄ = 4f₁
Worked Example
A guitar string has a length of 0.75 m.
The wave speed along the string is 120 m/s.
Calculate the fundamental frequency.
f₁ = v/(2L)
= 120/(2 × 0.75)
= 120/1.5
f₁ = 80 Hz
The second harmonic is:
f₂ = 160 Hz
The third harmonic is:
f₃ = 240 Hz
These frequencies help determine the sound produced by the vibrating string.
Simple Harmonic Motion
Simple harmonic motion (SHM) is a type of oscillation in which acceleration is proportional to displacement and directed toward equilibrium.
Mathematically:
a = −ω²x
The negative sign indicates that acceleration acts toward the equilibrium position.
SHM can be represented using:
x(t) = A cos(ωt + φ)
Examples include:
-
An ideal mass–spring system.
-
A simple pendulum at small angles.
-
Certain vibrating mechanical components.
-
Oscillating electrical systems.
Displacement, Velocity, and Acceleration in SHM
For an object undergoing simple harmonic motion:
x(t) = A cos(ωt + φ)
Velocity is the rate of change of displacement:
v(t) = −Aω sin(ωt + φ)
Acceleration is the rate of change of velocity:
a(t) = −Aω² cos(ωt + φ)
Therefore:
a(t) = −ω²x(t)
Maximum Values
Maximum displacement:
x_max = A
Maximum speed:
v_max = Aω
Maximum acceleration magnitude:
a_max = Aω²
Phase Relationships
-
Velocity differs in phase from displacement by one-quarter of a cycle.
-
Acceleration is in antiphase with displacement.
-
Speed is greatest at equilibrium.
-
Acceleration magnitude is greatest at maximum displacement.
Worked Example: Oscillating Mass
A mass moves according to:
x(t) = 0.08 cos(5t)
where displacement is measured in metres and time in seconds.
Amplitude
A = 0.08 m
= 8 cm
Angular Frequency
ω = 5 rad/s
Period
T = 2π/5
T ≈ 1.26 s
Maximum Speed
v_max = Aω
= 0.08 × 5
v_max = 0.40 m/s
Maximum Acceleration
a_max = Aω²
= 0.08 × 25
a_max = 2.0 m/s²
Interpretation
The mass oscillates 8 cm on either side of equilibrium, reaches a maximum speed of 0.40 m/s, and experiences a maximum acceleration magnitude of 2.0 m/s².
Mass–Spring Systems
An ideal mass attached to a spring can undergo simple harmonic motion.
Hooke's Law states:
F = −kx
where:
-
F = restoring force.
-
k = spring constant.
-
x = displacement from equilibrium.
Using Newton's Second Law:
ma = −kx
Therefore:
a = −(k/m)x
Comparing this with:
a = −ω²x
gives:
ω = √(k/m)
The period is:
T = 2π√(m/k)
Worked Example
A mass of 0.50 kg is attached to a spring with spring constant 200 N/m.
Calculate the period.
T = 2π√(0.50/200)
= 2π√0.0025
= 2π × 0.05
T ≈ 0.314 s
Interpretation
Increasing the mass increases the period.
Increasing the spring constant decreases the period.

Pendulum Motion
A simple pendulum consists of a mass suspended from a fixed point by a string or rod.
For small angular displacements, the pendulum approximately undergoes simple harmonic motion.
Its period is:
T = 2π√(L/g)
where:
-
L = pendulum length.
-
g = gravitational field strength.
Worked Example
A pendulum has a length of 1.0 m.
Take:
g = 9.81 m/s²
Calculate its period.
T = 2π√(1.0/9.81)
T ≈ 2.01 s
Interpretation
A longer pendulum has a longer period.
For small oscillations, the period is approximately independent of the mass of the pendulum bob.
The small-angle assumption becomes less accurate for large oscillations.

Energy in Oscillatory Systems
In an ideal undamped mass–spring system, mechanical energy is conserved.
Energy continuously transfers between:
-
Elastic potential energy.
-
Kinetic energy.
Elastic Potential Energy
Eₚ = 1/2 kx²
Kinetic Energy
Eₖ = 1/2 mv²
Total Mechanical Energy
E_total = 1/2 kA²
where A is the amplitude.
At Maximum Displacement
-
Speed is zero.
-
Kinetic energy is zero.
-
Elastic potential energy is maximum.
At Equilibrium
-
Speed is maximum.
-
Kinetic energy is maximum.
-
Elastic potential energy is minimum.
Real Systems
Real oscillations lose energy through friction, air resistance, and other dissipative processes.
As a result, their amplitudes may decrease over time.
Damped Oscillations
A damped oscillation gradually decreases in amplitude because energy is transferred away from the oscillating system.
A common model for underdamped motion is:
x(t) = A₀e^(−bt) cos(ω_dt + φ)
where:
-
A₀ = initial amplitude.
-
b = positive decay constant.
-
ω_d = damped angular frequency.
-
φ = phase constant.
The exponential factor:
e^(−bt)
causes the amplitude to decrease over time.
Applications
Damping is important in:
-
Vehicle suspension systems.
-
Building vibration control.
-
Mechanical shock absorbers.
-
Seismic protection.
-
Precision instruments.

Resonance
Resonance occurs when a system responds strongly to a periodic driving force whose frequency is near the system's natural frequency.
Examples include:
-
Musical instruments.
-
Mechanical structures.
-
Electrical circuits.
-
Acoustic systems.
Natural Frequency
The natural frequency is the frequency at which a system tends to oscillate when disturbed.
For an ideal mass–spring system:
f₀ = (1/2π)√(k/m)
Resonance and Amplitude
When a driving frequency approaches the resonant frequency, the oscillation amplitude may increase substantially.
Damping limits the maximum response.
Engineering Importance
Engineers must consider resonance when designing:
-
Bridges.
-
Buildings.
-
Rotating machinery.
-
Aircraft components.
-
Vehicle suspension systems.
Excessive resonance can produce damaging vibrations.
Beats and Interference Between Different Frequencies
When two waves have slightly different frequencies, their superposition can produce beats.
Beats are periodic changes in the amplitude of the combined wave.
For two frequencies f₁ and f₂:
f_beat = |f₁ − f₂|
Worked Example
Two tuning forks produce frequencies of:
440 Hz and 444 Hz.
Calculate the beat frequency.
f_beat = |444 − 440|
f_beat = 4 Hz
The combined sound becomes louder and softer four times per second.
Applications
Beat frequencies are used in:
-
Tuning musical instruments.
-
Acoustic measurements.
-
Signal processing.
-
Frequency comparison.


Connecting Wave Models to Physical Systems
Trigonometric wave models appear throughout science and engineering.
|
Physical system |
Mathematical application |
|---|---|
|
Sound waves |
Frequency, amplitude, interference, beats |
|
Water waves |
Wavelength, speed, phase, superposition |
|
Light waves |
Interference, diffraction, phase difference |
|
Guitar strings |
Standing waves and harmonics |
|
Pendulums |
Periodic motion and small-angle SHM |
|
Springs |
Displacement, velocity, acceleration |
|
Electrical circuits |
Alternating voltage and current |
|
Buildings |
Resonance and damping |
|
Communication systems |
Signal phase, frequency, modulation |
Alternating Current
An alternating voltage can be modelled as:
V(t) = V₀ sin(ωt + φ)
where V₀ is the peak voltage.
This illustrates how the same trigonometric functions used for mechanical waves also describe electrical oscillations.
Communication Systems
Radio communication uses oscillating electromagnetic fields.
Information can be represented by changes in amplitude, frequency, or phase.
This connects wave mathematics to digital technology.
Selecting the Correct Wave Equation
Different problems require different mathematical models.
| Situation | Useful equation | |---|---| | Oscillation at one location | y = A sin(ωt + φ) | | Wave travelling in +x direction | y = A sin(kx − ωt + φ) | | Wave speed | v = fλ | | Angular frequency | ω = 2πf | | Wave number | k = 2π/λ | | Time difference from phase difference | Δt = |Δφ|/ω | | Phase difference from path difference | Δφ = 2πΔd/λ | | Equal-amplitude wave interference | A_resultant = 2A|cos(Δφ/2)| | | Standing wave | y = 2A sin(kx) cos(ωt) | | Simple harmonic acceleration | a = −ω²x | | Spring period | T = 2π√(m/k) | | Small-angle pendulum period | T = 2π√(L/g) | | Beat frequency | f_beat = |f₁ − f₂| |
Selecting the appropriate model requires understanding what each variable represents and which physical assumptions apply.
Common Mistakes
Confusing amplitude and wavelength
Amplitude measures maximum displacement, while wavelength measures spatial repetition.
Confusing frequency and angular frequency
Frequency is measured in hertz, while angular frequency is measured in radians per second.
Using degrees instead of radians without checking
Many wave equations assume angles are measured in radians.
Confusing period and frequency
Period is the time for one cycle, while frequency is the number of cycles per second.
Ignoring the phase constant
The phase constant determines the initial position within the oscillation.
Assuming waves always reinforce each other
Interference depends on relative phase and amplitude.
Assuming destructive interference always produces complete cancellation
Complete cancellation requires appropriate phase and equal amplitudes.
Confusing travelling waves with standing waves
Travelling waves propagate through space, while standing waves have fixed nodes and antinodes.
Using wave speed and particle speed interchangeably
The propagation speed of a wave is not generally the same as the speed of an oscillating particle.
Applying simple harmonic motion formulas to every oscillation
SHM requires acceleration proportional to displacement and directed toward equilibrium.
Ignoring damping in real systems
Real oscillations often lose energy and decrease in amplitude.
Assuming resonance always occurs at exactly the undamped natural frequency
Damping can shift the frequency of maximum displacement response.
Key Terms
-
Wave: A disturbance that transfers energy through a medium or through space.
-
Wave Motion: The propagation of a disturbance through space or a medium.
-
Oscillation: Repeated movement or variation around an equilibrium state.
-
Periodic Motion: Motion that repeats after a fixed interval.
-
Transverse Wave: A wave whose oscillations are perpendicular to the direction of propagation.
-
Longitudinal Wave: A wave whose oscillations are parallel to the direction of propagation.
-
Sinusoidal Wave: A wave described by a sine or cosine function.
-
Equilibrium Position: The central position around which oscillation occurs.
-
Amplitude: The maximum displacement from equilibrium.
-
Crest: The highest point of a transverse wave.
-
Trough: The lowest point of a transverse wave.
-
Wavelength: The distance between consecutive points in the same phase.
-
Frequency: The number of complete oscillations per second.
-
Period: The time required for one complete oscillation.
-
Angular Frequency: The rate of change of oscillation phase, measured in radians per second.
-
Wave Number: The spatial rate of change of phase, equal to 2π/λ.
-
Wave Speed: The speed at which a wave pattern propagates.
-
Phase: The position of an oscillation within its repeating cycle.
-
Phase Angle: An angular measure describing the stage of an oscillation.
-
Phase Difference: The difference between the phases of two oscillations.
-
Phase Shift: A horizontal displacement of a sinusoidal graph.
-
In Phase: Having matching phases, differing by a whole number of cycles.
-
Antiphase: Having a phase difference of an odd multiple of π radians.
-
Superposition: The addition of overlapping wave displacements.
-
Interference: The reinforcement or cancellation produced by overlapping waves.
-
Constructive Interference: Interference that increases resultant amplitude.
-
Destructive Interference: Interference that reduces resultant amplitude.
-
Path Difference: The difference between distances travelled by two waves.
-
Coherent Waves: Waves with the same frequency and a constant phase relationship.
-
Standing Wave: A stationary wave pattern formed by interference between oppositely travelling waves.
-
Node: A position of zero displacement in a standing wave.
-
Antinode: A position of maximum oscillation amplitude in a standing wave.
-
Harmonic: A resonant frequency that is an integer multiple of the fundamental frequency in a harmonic series.
-
Fundamental Frequency: The lowest resonant frequency of a system.
-
Simple Harmonic Motion: Oscillation with acceleration proportional to displacement and directed toward equilibrium.
-
Restoring Force: A force acting toward an equilibrium position.
-
Damping: The reduction of oscillation amplitude through energy dissipation.
-
Resonance: A strong response to periodic driving near a system's natural frequency.
-
Natural Frequency: A frequency at which a system tends to oscillate when disturbed.
-
Beat Frequency: The frequency of amplitude variation produced by superposing two nearby frequencies.
Key Takeaways
-
Trigonometric functions provide mathematical models for periodic wave motion and oscillations.
-
Sine and cosine functions describe smooth, repeating variations.
-
Amplitude represents the maximum displacement from equilibrium.
-
Frequency and period are related by f = 1/T.
-
Angular frequency is related to frequency by ω = 2πf.
-
Phase describes the position of an oscillation within its cycle.
-
Phase differences determine how oscillations align.
-
Wave speed, frequency, and wavelength are related by v = fλ.
-
A travelling wave can be represented using both position and time.
-
The signs of the spatial and time terms indicate propagation direction.
-
The principle of superposition describes the addition of overlapping waves.
-
Constructive interference occurs when waves reinforce one another.
-
Destructive interference occurs when waves oppose one another.
-
Path difference produces phase difference between coherent waves.
-
Standing waves contain fixed nodes and antinodes.
-
Standing-wave frequencies depend on the physical dimensions and boundary conditions of the system.
-
Simple harmonic motion involves acceleration directed toward equilibrium and proportional to displacement.
-
Displacement, velocity, and acceleration have different phase relationships during SHM.
-
Ideal mass–spring systems exchange kinetic and elastic potential energy.
-
Damping reduces oscillation amplitude through energy dissipation.
-
Resonance occurs when periodic driving produces a strong response near a natural frequency.
-
Beat frequencies arise from the interference of waves with slightly different frequencies.
-
Wave models are important in acoustics, optics, electronics, communications, and engineering.
Check Your Understanding
Recall and Understanding
-
Explain why sine and cosine functions are suitable for modelling wave motion.
-
Distinguish between amplitude, wavelength, frequency, and period.
-
Explain what it means for two waves to be in phase.
-
Describe the difference between constructive and destructive interference.
-
Explain how a standing wave differs from a travelling wave.
Application
-
A wave is represented by y = 5 sin(6πt). Determine its amplitude, angular frequency, frequency, and period.
-
A sound wave travels at 340 m/s and has a frequency of 680 Hz. Calculate its wavelength.
-
Two oscillations have a frequency of 20 Hz and a phase difference of π/2 radians. Calculate the corresponding time difference.
-
Two coherent waves each have an amplitude of 6 cm and a phase difference of 120°. Calculate their resultant amplitude.
-
A spring–mass system contains a 0.40 kg mass attached to a spring with spring constant 100 N/m. Calculate the period.
Analysis and Challenge
-
A travelling wave is described by y(x,t) = 0.03 sin(4πx − 20πt). Determine its amplitude, wavelength, frequency, period, speed, and direction of propagation.
-
Two coherent waves have a wavelength of 0.60 m. At a particular point, their path difference is 0.90 m. Determine whether the interference is constructive or destructive, assuming the sources are initially in phase.
-
A string fixed at both ends is 1.2 m long, and waves travel along it at 96 m/s. Calculate the fundamental frequency and the frequencies of the second and third harmonics.
-
A vibrating object follows x(t) = 0.12 cos(8t). Determine its maximum speed and acceleration magnitude. Explain where each maximum occurs during the oscillation.
-
A mechanical system is driven by a periodic force. Explain how natural frequency, resonance, damping, and amplitude influence its behaviour. Suggest one engineering application in which these effects must be considered.
Final Summary
Wave motion provides an important connection between trigonometry and the physical world.
Sine and cosine functions can describe the displacement of oscillating objects and the propagation of waves through space.
Amplitude, frequency, period, wavelength, and phase allow us to analyse the characteristics of waves mathematically.
The principle of superposition explains how overlapping waves combine to produce constructive and destructive interference.
Standing waves demonstrate how interference creates fixed nodes and antinodes, while simple harmonic motion provides a mathematical model for springs, pendulums, and other oscillating systems.
Damping, resonance, and beat frequencies extend these models to more complex physical situations.
These mathematical ideas are essential in understanding sound, light, mechanical vibrations, electrical oscillations, and communication technologies.
The central principle is that trigonometric functions do more than describe repeating graphs: they provide mathematical models that allow us to predict, analyse, and explain wave behaviour in real physical systems.