4. Work and Power in Rotational Systems

Learning outcomes
  • I can define rotational work.
  • I can calculate work done by torque.
  • I can define rotational power.
  • I can solve problems involving rotational energy transfer.
  • I can analyze rotating machines using power concepts.

Key Topics:
  • Rotational kinetic energy: KErot=12Iω2.
  • Comparison of translational and rotational kinetic energy.

Work and Power in Rotational Systems

Rotating systems can transfer energy in much the same way as objects moving in a straight line. When a torque causes an object to rotate through an angular displacement, work is done on the object.

For a constant torque acting in the direction of rotation:

W = τΔθ

where:

  • W = rotational work, measured in joules (J)
  • τ = torque, measured in newton-metres (N·m)
  • Δθ = angular displacement, measured in radians (rad)

Rotational power describes how quickly this work is done or how quickly energy is transferred.

For a rotating system:

P = τω

where:

  • P = power, measured in watts (W)
  • τ = torque
  • ω = angular velocity in rad/s

These relationships are essential for understanding motors, engines, turbines, generators, gears, vehicle drivetrains, and other rotating machines.

https://images.openai.com/static-rsc-4/eTtRCqpWor540-PmlS35ej_0SRI_V0HxCzTL9PsuksAHC0yVTDa-nJaPOdXjAHWWlgr-CTrQMW5Evlis-vSqhkAC8hvG1pfNwgKXTqxV7KOQKXK20xeTsLTxy4KFMJNaF1gSPzLS9j0bVkZhfBxv_GcHZYdswLuQSvjdUdeUXANQPS7JcdR0hNzrbbnZ-dJB?purpose=fullsize
 
https://images.openai.com/static-rsc-4/OhZINLG0sPXhLubuRPKpl6tumO_gLc1Wy-f35aDLojUia1aRqQIEeZdpmXtzKwOxYVgZHMRqGk-6IcWS2sBxPl16AidzT2Y3C-c8QwFK5xfLK8bCewJvvhQdEBjmNqtLOPaeSoXjp0cZB6-iokLlBP0bQ1Q1ig-0gel5D5D5IDqez8yokpotYIhgScyzZ40Z?purpose=fullsize
 
https://images.openai.com/static-rsc-4/5LSphJUTDhs6FJdY2sABbZAWwnrKWqrVO3wvI_P_ST99nMflEsiz2UjmF7HTFg9MZC_nhu-VVfeDI2oM6JhZus0tg8cL-kCS4YUj-o0JN4icr1KIZ8YlaCzAkFoyj6r_Yq7WKXOYW3xJXzyxAJ20Z9yk1A74qXk-ZNKXdSSxvDjP63G6ykz6LtO7TSejuEN3?purpose=fullsize
 
7

Rotational Work

In linear motion, work is done when a force acts through a displacement.

For a constant force acting in the direction of motion:

W = Fd

The rotational equivalent is:

W = τΔθ

Instead of:

  • force F, we use torque τ
  • linear displacement d, we use angular displacement Δθ

This creates another important parallel between translational and rotational mechanics.

Translational Motion Rotational Motion
Force F Torque τ
Displacement d Angular displacement Δθ
W = Fd W = τΔθ
Velocity v Angular velocity ω
P = Fv P = τω

How Torque Does Work

Torque produces a turning effect.

If a torque causes an object to rotate, energy is transferred to or from the rotating system.

For example, a motor applies torque to a wheel.

As the wheel turns:

  • the motor does work
  • energy is transferred to the wheel
  • the wheel's rotational kinetic energy may increase

If friction or brakes apply an opposing torque, energy can be transferred out of the wheel's rotational motion.


Torque from a Force

Before calculating rotational work, we may first need to calculate torque.

For a force acting at distance r:

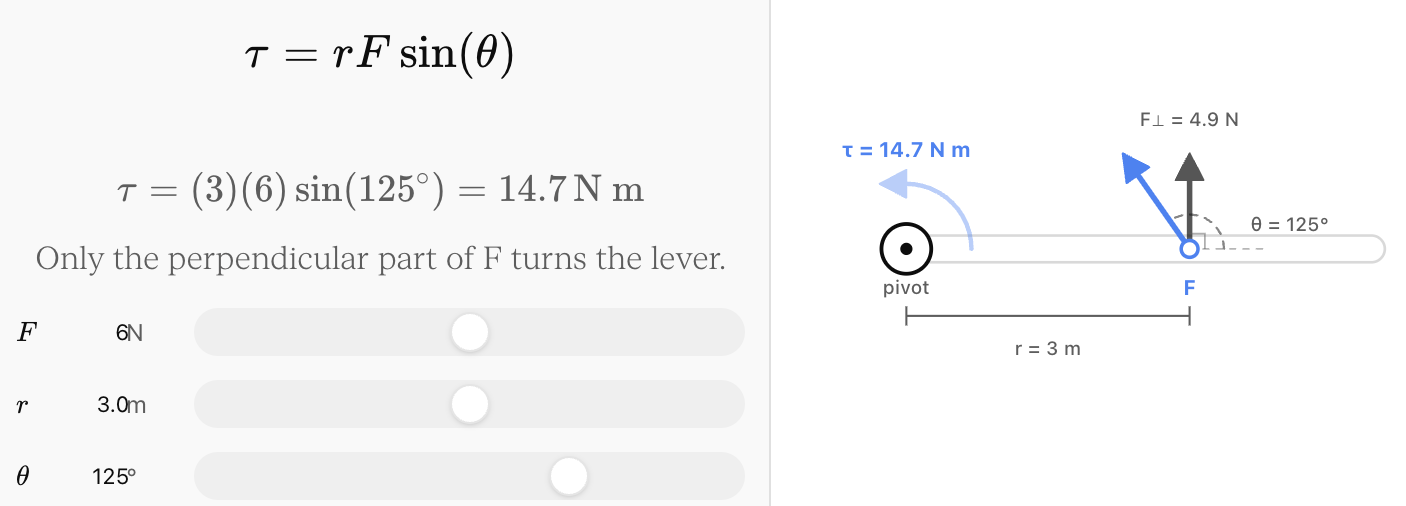
τ = rF sin θ

For a force perpendicular to the lever arm:

τ = rF

The amount of torque therefore depends on:

  • force magnitude
  • distance from the axis
  • angle of the applied force

Worked Example: Rotational Work

A constant torque of:

τ = 15 N·m

rotates a wheel through:

Δθ = 20 rad

Work done:

W = τΔθ

W = (15)(20)

W = 300 J

Therefore, 300 J of energy is transferred to the wheel.


Angular Displacement Must Be in Radians

When using:

W = τΔθ

angular displacement should be measured in radians.

One complete revolution is:

2π rad

Therefore:

1 revolution = 2π rad

If an object completes N revolutions:

Δθ = 2πN


Worked Example: Several Revolutions

A motor applies a constant torque of:

8.0 N·m

while a shaft rotates through:

10 revolutions

First convert revolutions to radians:

Δθ = 10(2π)

Δθ = 20π rad

Δθ ≈ 62.8 rad

Then:

W = τΔθ

W = (8.0)(62.8)

W ≈ 503 J


Work from an Applied Force

Sometimes a problem gives a force rather than torque.

Suppose a tangential force of:

50 N

acts at the edge of a wheel with radius:

0.30 m

Torque:

τ = rF

τ = (0.30)(50)

τ = 15 N·m

If the wheel rotates through:

12 rad

then:

W = τΔθ

W = (15)(12)

W = 180 J

The problem requires two steps:

force → torque → work


Force Applied at an Angle

Suppose:

F = 80 N

r = 0.40 m

θ = 30°

First calculate torque:

τ = rF sin θ

τ = (0.40)(80)(sin 30°)

τ = (0.40)(80)(0.50)

τ = 16 N·m

If the object rotates through:

Δθ = 15 rad

then:

W = τΔθ

W = (16)(15)

W = 240 J

Only the component of the force that produces torque contributes to rotational work.


Positive and Negative Work

Rotational work can be positive or negative.

Positive Work

Torque acts in the same direction as angular displacement.

Energy is transferred into the rotational motion.

Negative Work

Torque acts opposite to angular displacement.

Energy is transferred out of the rotational motion.

Braking and friction commonly perform negative rotational work.


Work-Energy Theorem for Rotation

Net rotational work changes rotational kinetic energy:

W_net = ΔE_rot

Therefore:

W_net = E_rot,f − E_rot,i

Since:

E_rot = 1/2 Iω²

we can write:

W_net = 1/2 Iω_f² − 1/2 Iω_i²

This allows us to connect torque directly to changes in rotational speed.

https://images.openai.com/static-rsc-4/d2z-m1V1gKmjc8UPrR7xe8BRxQY3xoZxCioDtXSa-RcoRxlrFvjpYSIm8LtC1MYLRi4ryoKhBm1XcMl5tEe0jREGgLwb6piI8_V_Ddq79_31-Mr0lDCGk6wG2B3QLeDdAMVgNeHAZtJXjqGzbInm5juRB1_eugYF-ufVLRplJ5iImPWULoKCsW15Do1zdmIK?purpose=fullsize
 
https://images.openai.com/static-rsc-4/xh84a-iFywZCCElPuAprFKW8iet4_IhAok2vg85Tu6um6j9FQ-nH4hLmJwlyV603A1jDOlCx2NbvmlupAlueF8Vm0kdjIkShHb_LbSknQURWEpLtkjTk9Mu-hqOAZ99yK7u3pHoDBvPmsJ6u4Ly_VMS6MbytoDNMZM7dJq9MC6tsx5b_sJU8SRh3q43oI4gY?purpose=fullsize
 
https://images.openai.com/static-rsc-4/5LSphJUTDhs6FJdY2sABbZAWwnrKWqrVO3wvI_P_ST99nMflEsiz2UjmF7HTFg9MZC_nhu-VVfeDI2oM6JhZus0tg8cL-kCS4YUj-o0JN4icr1KIZ8YlaCzAkFoyj6r_Yq7WKXOYW3xJXzyxAJ20Z9yk1A74qXk-ZNKXdSSxvDjP63G6ykz6LtO7TSejuEN3?purpose=fullsize
 
8

Worked Example: Wheel Accelerating

A wheel has:

I = 4.0 kg·m²

ω_i = 5.0 rad/s

A motor does:

300 J

of net work on the wheel.

Initial rotational energy:

E_i = 1/2 Iω_i²

E_i = 1/2(4)(5²)

E_i = 50 J

Since:

W_net = E_f − E_i

300 = E_f − 50

E_f = 350 J

Now:

350 = 1/2(4)ω_f²

350 = 2ω_f²

ω_f² = 175

ω_f ≈ 13.2 rad/s


Work Done by Friction

Friction often produces torque opposite the direction of rotation.

Suppose:

τ_friction = −4.0 N·m

and the wheel rotates through:

Δθ = +25 rad

Then:

W_friction = τΔθ

W_friction = (−4.0)(25)

W_friction = −100 J

The negative sign indicates that friction removes 100 J of rotational mechanical energy.

That energy is typically transferred into:

  • thermal energy
  • sound
  • deformation

Multiple Torques

If several torques act on a system, calculate the net torque.

Suppose:

τ_motor = +20 N·m

τ_friction = −5 N·m

Then:

τ_net = 20 − 5

τ_net = 15 N·m

If the system rotates through:

Δθ = 30 rad

then:

W_net = τ_net Δθ

W_net = (15)(30)

W_net = 450 J

The rotational kinetic energy increases by 450 J.


Work and Newton's Second Law for Rotation

Newton's Second Law for rotation is:

Στ = Iα

The work-energy relationship is:

W_net = ΔE_rot

These provide two different approaches to rotational problems.

Use dynamics when you need:

  • angular acceleration
  • time
  • angular velocity as a function of time

Use energy when you know:

  • angular displacement
  • work
  • initial and final energy

Often either method can solve the same problem.


Deriving the Rotational Work-Energy Relationship

For constant torque:

W = τΔθ

Using:

τ = Iα

gives:

W = IαΔθ

Rotational kinematics gives:

ω_f² = ω_i² + 2αΔθ

Therefore:

αΔθ = (ω_f² − ω_i²)/2

Substituting:

W = I(ω_f² − ω_i²)/2

Therefore:

W = 1/2 Iω_f² − 1/2 Iω_i²

So:

W_net = ΔE_rot

This is the rotational work-energy theorem.


Rotational Power

Power measures how quickly work is done.

Average power is:

P_avg = W/Δt

where:

  • P = power in watts
  • W = work in joules
  • Δt = time in seconds

One watt is:

1 W = 1 J/s

For rotational motion, instantaneous power can also be calculated using:

P = τω


Why P = τω

In linear motion:

P = Fv

For rotation:

v = rω

and for a perpendicular force:

τ = rF

Therefore:

P = F(rω)

P = (rF)ω

so:

P = τω

This is the rotational equivalent of P = Fv.


Worked Example: Rotating Motor

A motor produces:

τ = 30 N·m

while rotating at:

ω = 40 rad/s

Power:

P = τω

P = (30)(40)

P = 1200 W

or:

P = 1.2 kW


Same Torque at Different Speeds

Suppose a motor produces a constant torque of:

20 N·m

At:

ω = 10 rad/s

P = (20)(10)

P = 200 W

At:

ω = 30 rad/s

P = (20)(30)

P = 600 W

At:

ω = 50 rad/s

P = (20)(50)

P = 1000 W

At constant torque, power increases directly with angular velocity.


Same Power at Different Speeds

Now suppose a motor delivers constant power:

P = 2000 W

Since:

τ = P/ω

at:

ω = 20 rad/s

τ = 2000/20

τ = 100 N·m

At:

ω = 100 rad/s

τ = 2000/100

τ = 20 N·m

For constant power:

higher angular speed → lower torque

This relationship is extremely important in motors, engines, and gear systems.


Torque-Speed Trade-Off

Many rotating machines face a trade-off between:

  • torque
  • angular speed

Because:

P = τω

a machine operating at a given power cannot independently increase both torque and angular velocity.

This is one reason gearboxes are useful.

A gearbox can trade:

speed for torque

or:

torque for speed

https://images.openai.com/static-rsc-4/OhZINLG0sPXhLubuRPKpl6tumO_gLc1Wy-f35aDLojUia1aRqQIEeZdpmXtzKwOxYVgZHMRqGk-6IcWS2sBxPl16AidzT2Y3C-c8QwFK5xfLK8bCewJvvhQdEBjmNqtLOPaeSoXjp0cZB6-iokLlBP0bQ1Q1ig-0gel5D5D5IDqez8yokpotYIhgScyzZ40Z?purpose=fullsize
 
https://images.openai.com/static-rsc-4/E3aFDHpySf2APzKYmZxn5cmywvC2YZ8I8NRmm4Hx21cpA8g1SpjFapwBAgMo2ODyMf8HtrN87_OB0Vw9HeWQcxBxpE5C846VyhqHKcjzf4k0YUZ7AwO3BvfLa_4MM9Z8N6uLmW4z7CG5K0YI7JlOc08BMkwGgoCcxlagRbXfOI03U08SXQ4OJU8JPxn_koVf?purpose=fullsize
 
https://images.openai.com/static-rsc-4/0za2Z_UXAjHirre2fXB1HMIscxxrt4xdwiteY4cKcIt6YsCLZiBgNv3746hdBQ_LhgRnlVLj3GHMP22VnUVOS4e2oqoAOjVGyYj8M2vyJGbc29NC8YikMBoJzonCBDK4kwG8xiAaadOtiAwFYFDA-k8_HEvSeYeFIg7YRD0OrY5srzx8cam12Yh2KeiONb0M?purpose=fullsize
 
10

Gears and Power

For an ideal gearbox:

P_in = P_out

Therefore:

τ_inω_in = τ_outω_out

If output angular velocity decreases, output torque increases.


Worked Gear Example

A motor provides:

τ_in = 10 N·m

ω_in = 120 rad/s

Input power:

P_in = τ_inω_in

P_in = (10)(120)

P_in = 1200 W

A gearbox reduces the output speed to:

ω_out = 30 rad/s

Assuming an ideal gearbox:

P_out = 1200 W

Therefore:

τ_out = P_out/ω_out

τ_out = 1200/30

τ_out = 40 N·m

The speed decreased by a factor of four while torque increased by a factor of four.


Efficiency in Rotating Machines

Real machines are not perfectly efficient.

Some energy is transferred into:

  • thermal energy
  • sound
  • vibration
  • deformation

Efficiency is:

efficiency = useful output power / input power × 100%

or:

efficiency = useful output energy / input energy × 100%


Worked Efficiency Example

A motor receives:

3000 W

of electrical power and delivers:

2400 W

of useful rotational mechanical power.

Efficiency:

efficiency = 2400/3000 × 100%

efficiency = 80%

The remaining:

3000 − 2400 = 600 W

is transferred to other forms, mainly thermal energy.


Gearbox Efficiency

A gearbox receives:

1500 W

and operates at:

90% efficiency

Useful output power:

P_out = 0.90(1500)

P_out = 1350 W

If the output shaft rotates at:

45 rad/s

then:

τ_out = P_out/ω_out

τ_out = 1350/45

τ_out = 30 N·m


Motors

Electric motors convert electrical energy into rotational mechanical energy.

Important motor quantities include:

  • torque
  • angular velocity
  • power
  • efficiency
https://images.openai.com/static-rsc-4/OhZINLG0sPXhLubuRPKpl6tumO_gLc1Wy-f35aDLojUia1aRqQIEeZdpmXtzKwOxYVgZHMRqGk-6IcWS2sBxPl16AidzT2Y3C-c8QwFK5xfLK8bCewJvvhQdEBjmNqtLOPaeSoXjp0cZB6-iokLlBP0bQ1Q1ig-0gel5D5D5IDqez8yokpotYIhgScyzZ40Z?purpose=fullsize
 
https://images.openai.com/static-rsc-4/d2z-m1V1gKmjc8UPrR7xe8BRxQY3xoZxCioDtXSa-RcoRxlrFvjpYSIm8LtC1MYLRi4ryoKhBm1XcMl5tEe0jREGgLwb6piI8_V_Ddq79_31-Mr0lDCGk6wG2B3QLeDdAMVgNeHAZtJXjqGzbInm5juRB1_eugYF-ufVLRplJ5iImPWULoKCsW15Do1zdmIK?purpose=fullsize
 
https://images.openai.com/static-rsc-4/OM0ORP5c7ousBgHXHl2Wv8gB9rLeQUjHvNIPtGGyit94zPnNB7brPdX5APTmB49Q9qQdJ-3zgZqOHmbDMX6N02oPmOVonZisi7jHBFauAiTOJHgd9QgbcP5IO9d8acONua1fciG-Z-Bwad7WYiHjmSd2_D0hq8t6Ut3q_txZmu11MTmhcy6FwHboFsDIplzv?purpose=fullsize
 
8

A motor used to lift a heavy load may need high torque.

A motor used to spin a fan may operate at higher angular speed but require much less torque.

Motor selection therefore depends on the task.


Engines

Vehicle engines and other combustion engines produce torque over a range of rotational speeds.

Rotational power is:

P = τω

This explains why an engine's maximum torque and maximum power usually do not occur at exactly the same rotational speed.

Power depends on both:

  • torque
  • angular velocity

Converting rpm to rad/s

Rotating machines often specify speed in revolutions per minute (rpm).

Physics equations generally require:

rad/s

Since:

1 revolution = 2π rad

1 minute = 60 s

then:

ω = rpm × 2π/60


Worked rpm Example

A motor rotates at:

1800 rpm

Convert to rad/s:

ω = 1800 × 2π/60

ω = 60π

ω ≈ 188.5 rad/s

If the motor produces:

τ = 12 N·m

then:

P = τω

P = (12)(188.5)

P ≈ 2262 W

or approximately:

2.26 kW


Finding Torque from Power

Rearrange:

P = τω

to give:

τ = P/ω

Suppose a motor delivers:

P = 5000 W

at:

ω = 100 rad/s

Then:

τ = 5000/100

τ = 50 N·m


Finding Angular Velocity from Power

Rearrange:

ω = P/τ

Suppose:

P = 2400 W

τ = 30 N·m

Then:

ω = 2400/30

ω = 80 rad/s


Power and Energy Transfer

Power tells us the rate at which energy is transferred.

Since:

P = E/t

energy transferred is:

E = Pt

Suppose a motor delivers:

P = 1500 W

for:

t = 20 s

Then:

E = Pt

E = (1500)(20)

E = 30,000 J

or:

30 kJ


Connecting Power, Torque, and Work

Several important relationships can be connected:

W = τΔθ

P = W/Δt

and:

ω = Δθ/Δt

Therefore:

P = τΔθ/Δt

so:

P = τω

This shows that rotational work and rotational power are closely connected.


Power During Angular Acceleration

Suppose a constant torque acts while an object speeds up.

Since:

P = τω

the power changes as ω changes.

If torque remains constant:

  • low ω → lower power
  • high ω → higher power

Therefore, constant torque does not mean constant power.


Worked Example: Accelerating Flywheel

A flywheel has:

I = 5.0 kg·m²

A constant net torque:

τ = 10 N·m

acts from rest for:

8.0 s.

First find angular acceleration:

α = τ/I

α = 10/5

α = 2.0 rad/s²

Final angular velocity:

ω_f = ω_i + αt

ω_f = 0 + (2)(8)

ω_f = 16 rad/s

Instantaneous power at the end:

P = τω

P = (10)(16)

P = 160 W

The power started at zero because ω = 0 and increased as the flywheel sped up.


Average Power During Acceleration

The final power in the previous example is 160 W, but that is not the average power.

Final rotational energy:

E_rot = 1/2 Iω²

E_rot = 1/2(5)(16²)

E_rot = 2.5(256)

E_rot = 640 J

Average power:

P_avg = W/t

P_avg = 640/8

P_avg = 80 W

For this constant-torque acceleration from rest, the final instantaneous power is twice the average power.


Braking Power

Brakes apply torque opposite the direction of rotation.

Suppose:

τ_brake = −50 N·m

and:

ω = +20 rad/s

Then:

P = τω

P = (−50)(20)

P = −1000 W

The negative sign means rotational mechanical energy is being removed from the wheel at a rate of:

1000 J/s

https://images.openai.com/static-rsc-4/t83JsZAUAEham0F-1slvixaVJnzEqL5LX9GmKXwKWTtkAWBNpdUY8MeYbGjbC6Zm39_GB3ZsaGNKxLt5yoNFe9wKQ7VcY5trP-aMzhFEq7JFSKJC4-NihsFUG3LccGFLq8QhUPPQXnfO5OjdL-dMfQmkvwFIbkMJru4sawGfDlzsDqsH8E6GDSpunXYQqu9K?purpose=fullsize
 
https://images.openai.com/static-rsc-4/7OohjXuSbudXrhsQfTnqEby6lY21UEmOx52oLCBjsG3zf65vS3p7rJ8Hrkzss0xym8VwmuZY1982n_jAZhFVjHhd9WJhVTjtQoMunLh6b3778jPdotasAGFd0CkiyWPbM1-siQzmzNiQFuD2kSIcz6dxnb2fPuHtWBfOqwMGD_qJzHim0xOOzC91PzOPIcN8?purpose=fullsize
 
https://images.openai.com/static-rsc-4/yNqZZgw_kQeZtfeDQ2mAJYykWZaVUGLPIQdtBXwDkBhZSqxr3BTDy0K_P4GHpFEZi6AbImJgquaGU3X-FLv-Hy0Jp4oqVaAWrzRtNZ9YW-n8cTdybIqruJqeBsp9YFfXLJGCoB7g491j06Kund6q6mJb3ayYrGOhiHNEpTLJBfv5scHxyXpof3dkNNlDl1vc?purpose=fullsize
 
6

Where Does Braking Energy Go?

In conventional friction brakes, much of the vehicle's mechanical energy becomes:

thermal energy

This heats:

  • brake discs
  • brake pads
  • surrounding air

In some electric and hybrid vehicles, regenerative braking can transfer some of the vehicle's mechanical energy back into electrical energy.


Turbines

Turbines extract energy from moving fluids such as:

  • steam
  • water
  • air
  • combustion gases

The fluid applies forces to the turbine blades.

These forces create torque.

The rotating turbine shaft then transfers mechanical power.

https://images.openai.com/static-rsc-4/OhZINLG0sPXhLubuRPKpl6tumO_gLc1Wy-f35aDLojUia1aRqQIEeZdpmXtzKwOxYVgZHMRqGk-6IcWS2sBxPl16AidzT2Y3C-c8QwFK5xfLK8bCewJvvhQdEBjmNqtLOPaeSoXjp0cZB6-iokLlBP0bQ1Q1ig-0gel5D5D5IDqez8yokpotYIhgScyzZ40Z?purpose=fullsize
 
https://images.openai.com/static-rsc-4/1f_GVBxbBzFvuXHOx8LMu8vVXy7Vgm4zVYe_hMaBIevBoE1FukghP5c0xinJjaUEvqIEBJh55MX6Y9E40AoTeOJ-1N0fUdVLkJlebkUElPhom2Rw7jixTmelZHsNA0bnypvOnlmdMdv07XLm1Ww7WzRzeKde5NozEkyX_hZrPoygRXc8BCJIJ5y4VQ6XrAz5?purpose=fullsize
 
https://images.openai.com/static-rsc-4/PuG3orz-gbgdVmGkkENjMR3OpZzB1xS1dJBfS0PBRyoJk4A2AM3jDJKz_y6AlJ9P4pyX42x6HMw_raf5Ykl9U7zXG0FoRyKgDTPCJCf4hxN1JKtC_yxOAZVEQYveDNBHSPj5mdkrHJrtvSpkujaFeTKEx6Y2dENLIS7GBjeCTAPC6ux-ULxaPVXDEhwyBYH9?purpose=fullsize
 
8

For the shaft:

P = τω

A turbine can therefore produce high power through:

  • large torque
  • high angular velocity
  • or a combination of both

Wind Turbine Example

Suppose a wind turbine shaft produces:

τ = 25,000 N·m

at:

ω = 2.0 rad/s

Power:

P = τω

P = (25,000)(2.0)

P = 50,000 W

or:

50 kW

Even though the angular velocity is relatively low, the very large torque allows substantial power transfer.


Drills and Power Tools

A drill needs both rotational speed and torque.

High speed is useful for rapid drilling.

High torque is useful when greater turning force is required.

The mechanical power delivered by the drill is:

P = τω

Gear settings can change the balance between:

  • high speed / low torque
  • low speed / high torque

without creating additional energy.


Vehicle Drivetrains

A vehicle drivetrain transfers rotational power from the motor or engine to the wheels.

https://images.openai.com/static-rsc-4/iXtalSDjvT7LhJ6M2LkcyBqaiyqFGKrvtL0svOcCbmoNciOR6aQPkEbonpTt3Ihs_qoq6itOrscWCKxTeF-rZpFu_XCPllvH9I1q2Np9jilVjVADEmV5fCRBswjfeDvbneBExbRkswnblhUz7OqecHlfkIKLJiBnHa1peCpDve-bYWLkiTw7Qigu8XrHs0I7?purpose=fullsize
 
https://images.openai.com/static-rsc-4/zDP139CXk0WxzJerWK_4ZM2L_yihBwZO1skcOxQV1xoX4yeCpOn4IAdBS9UUYFh1_RxmwklLGEymAU741K-oP6wqxejss--jJyzMi5R1idu2hoy35E6yKBBc09NvNP2IqG3-SB0pLmcODh2F8guQ9PD6WDDjNUf4NFQRk1T8ky6Zdvy7P72D7mJa3VDR5euj?purpose=fullsize
 
https://images.openai.com/static-rsc-4/_3xYpht6RRperxrivwtpH-jm-XwMSxEVogTjS6wSKtIC1cxWah0aBkYrXbMDgrS2hKLlOIbXUqFRZa7e83pQbGwSw5zzEibboCZuXTU0g6yUzIDKC62qfe5ysSOyRD4wipLzdYS286Uk4-fsn1xjFQdH2gsTpGR2sugWBjVB2RdAC2PLJLx-n4BDwq2fzi4z?purpose=fullsize
 
8

Lower gears generally provide:

  • greater wheel torque
  • lower wheel angular speed for a given engine speed

Higher gears generally provide:

  • lower torque multiplication
  • greater wheel angular speed

This allows the drivetrain to adapt the engine or motor's output to different driving conditions.


Why High Torque Is Useful at Low Speed

When starting from rest or climbing a steep hill, a vehicle needs substantial force at the road.

Greater wheel torque can produce a larger tangential force because:

τ = rF

Therefore:

F = τ/r

A gearbox can increase wheel torque even though it reduces angular speed.


Flywheel Energy Transfer

Flywheels can store rotational kinetic energy:

E_rot = 1/2 Iω²

A motor can do positive work to accelerate the flywheel.

Later, the flywheel can do work on another part of the system as it slows.

This allows rotational energy to be:

  • stored
  • released
  • transferred

Worked Flywheel Problem

A flywheel has:

I = 10 kg·m²

It speeds up from:

ω_i = 10 rad/s

to:

ω_f = 30 rad/s

Initial energy:

E_i = 1/2(10)(10²)

E_i = 500 J

Final energy:

E_f = 1/2(10)(30²)

E_f = 4500 J

Work required:

W = E_f − E_i

W = 4500 − 500

W = 4000 J

If this energy is supplied in:

5.0 s

average power is:

P_avg = 4000/5

P_avg = 800 W


A Complete Rotational Machine Problem

A motor drives a solid disk.

The disk has:

M = 20 kg

R = 0.40 m

The motor applies:

τ_motor = 18 N·m

Friction produces:

τ_friction = 3.0 N·m

The disk starts from rest and rotates through:

Δθ = 40 rad

Net Torque

τ_net = 18 − 3

τ_net = 15 N·m

Net Work

W_net = τ_netΔθ

W_net = (15)(40)

W_net = 600 J

Moment of Inertia

For a solid disk:

I = 1/2 MR²

I = 1/2(20)(0.40²)

I = 1.6 kg·m²

Final Rotational Energy

Since it starts from rest:

E_rot,f = 600 J

Final Angular Velocity

600 = 1/2(1.6)ω²

600 = 0.8ω²

ω² = 750

ω ≈ 27.4 rad/s

Motor Work

The motor itself does:

W_motor = τ_motorΔθ

W_motor = (18)(40)

W_motor = 720 J

Energy Lost to Friction

Friction does:

W_friction = (−3)(40)

W_friction = −120 J

Therefore:

720 J − 120 J = 600 J

becomes rotational kinetic energy.

This demonstrates the complete energy transfer within the system.


Analyzing Rotating Machines

When analyzing a rotating machine, it is useful to identify:

Input

What provides energy?

Examples:

  • electricity
  • fuel
  • moving water
  • wind

Torque

What produces the turning effect?

Angular velocity

How rapidly does the shaft rotate?

Power

How quickly is useful energy transferred?

Output

What useful task does the machine perform?

Losses

Where does unwanted energy go?

Common losses include:

  • friction
  • heating
  • sound
  • vibration

Efficiency

How much of the input becomes useful output?


Choosing the Right Equation

Use:

W = τΔθ

when torque and angular displacement are known.

Use:

P_avg = W/Δt

when total work and time are known.

Use:

P = τω

when torque and angular velocity are known.

Use:

W_net = ΔE_rot

when connecting work with changes in rotational kinetic energy.

Use:

E_rot = 1/2 Iω²

when the object's rotational energy is required.

Use:

efficiency = useful output/input × 100%

when analyzing real machines.


Common Mistakes

Using degrees in W = τΔθ

Angular displacement must be in radians.

Confusing torque and work

Torque is measured in N·m, while work is measured in joules. Although the units are dimensionally equivalent, they describe different physical quantities.

Using P = τω with rpm

Convert rpm to rad/s first.

Using applied torque instead of net torque

If friction acts, the net work depends on the net torque.

Assuming constant torque means constant power

Since P = τω, power changes if angular velocity changes.

Assuming gears create power

Gears trade torque for angular speed. Real gearboxes actually lose some power.

Ignoring negative work

Braking and frictional torques can remove rotational mechanical energy.

Confusing energy and power

Energy measures the amount transferred. Power measures how quickly it is transferred.

Ignoring efficiency

Real motors, turbines, gearboxes, and engines lose some useful mechanical energy.

Using final power as average power

When angular velocity changes, instantaneous power may also change.


Key Terms

Rotational work — energy transferred when a torque acts through an angular displacement.

Torque (τ) — turning effect of a force about an axis.

Angular displacement (Δθ) — change in angular position, measured in radians.

Rotational power — rate at which rotational work is done or rotational energy is transferred.

Average power — total work divided by the time interval over which the work occurs.

Instantaneous power — rate of energy transfer at a particular instant, calculated in rotational motion using P = τω.

Rotational kinetic energy — energy associated with rotation, E_rot = 1/2 Iω².

Work-energy theorem — principle stating that net work equals the change in kinetic energy.

Efficiency — fraction of input energy or power converted into useful output.

Gearbox — mechanical system that changes the relationship between torque and angular speed.

Flywheel — rotating device used to store rotational kinetic energy.

Regenerative braking — system that recovers some mechanical energy during braking and converts it into another useful form.

Input power — rate at which energy enters a machine.

Output power — rate at which useful energy leaves a machine.

Energy loss — transfer of energy into less useful forms such as thermal energy and sound.


Key Takeaways

  • Rotational work occurs when torque acts through an angular displacement.
  • For constant torque, W = τΔθ.
  • Angular displacement must be expressed in radians.
  • Positive rotational work adds mechanical energy to rotational motion.
  • Negative rotational work removes mechanical energy from rotational motion.
  • Net rotational work equals the change in rotational kinetic energy.
  • W_net = ΔE_rot.
  • Rotational kinetic energy is E_rot = 1/2 Iω².
  • Power measures the rate of energy transfer.
  • Average power is P_avg = W/Δt.
  • Instantaneous rotational power is P = τω.
  • High torque and high angular velocity both contribute to high power.
  • At constant power, increasing angular velocity requires decreasing torque.
  • Gears trade torque for angular speed rather than creating energy or power.
  • Real rotating machines lose energy through friction, heat, sound, and vibration.
  • Efficiency compares useful output with total input.
  • Motors convert electrical energy into rotational mechanical energy.
  • Turbines convert energy from moving fluids into rotational mechanical energy.
  • Brakes perform negative work and remove rotational kinetic energy.
  • Work and power concepts allow engineers to analyze how quickly rotating machines transfer and transform energy.

Check Your Understanding

  1. Define rotational work and state its equation.
  2. A constant torque of 12 N·m rotates an object through 15 rad. Calculate the work done.
  3. A motor applies 20 N·m of torque while a shaft completes 8 revolutions. Calculate the angular displacement in radians and the work done.
  4. A 60 N tangential force acts at the edge of a wheel with radius 0.25 m. Calculate the torque. If the wheel rotates through 20 rad, calculate the work done.
  5. A wheel experiences a driving torque of 25 N·m and an opposing frictional torque of 7 N·m. It rotates through 30 rad. Calculate the net torque and net work.
  6. Explain the difference between rotational work and rotational power.
  7. A motor does 18,000 J of work in 12 s. Calculate its average power.
  8. A shaft rotates at 50 rad/s while transmitting a torque of 40 N·m. Calculate the rotational power.
  9. A motor operates at 2400 rpm while producing 15 N·m of torque. Convert its angular speed to rad/s and calculate its mechanical power.
  10. A gearbox receives 2000 W of mechanical power and operates at 85% efficiency. Calculate its useful output power. If the output shaft rotates at 40 rad/s, calculate the output torque.
  11. A flywheel has I = 8.0 kg·m² and speeds up from 5.0 rad/s to 20 rad/s. Calculate the increase in rotational kinetic energy. If this occurs in 6.0 s, calculate the average power transferred to the flywheel.
  12. A brake applies a constant torque of −30 N·m to a wheel rotating through 25 rad before stopping. Calculate the work done by the brakes and explain the meaning of the sign.
  13. A motor supplies 24 N·m of torque while friction provides 4.0 N·m in the opposite direction. The system rotates through 50 rad. Calculate the motor's work, the work done by friction, and the net increase in rotational kinetic energy.
  14. Explain why a gearbox can increase torque without increasing power. Include the relationship P = τω in your explanation.
  15. A solid disk has mass 16 kg and radius 0.50 m. It starts from rest. A motor provides 20 N·m of torque while friction provides an opposing 4.0 N·m torque. The disk rotates through 40 rad. Calculate its moment of inertia, net torque, work done by the motor, work done by friction, net work, final rotational kinetic energy, and final angular velocity.