Rotational Kinematics
| サイト: | Young Education |
| コース: | Rigid Body Mechanics |
| ブック: | Rotational Kinematics |
| 印刷者: | Guest user |
| 日付: | 2026年 11月 9日(月曜日) 16:39 |
1. What Is a Rigid Body?
Learning outcomes
- I can define a rigid body and explain the assumptions of rigid body mechanics.
- I can distinguish between particle models and rigid body models.
- I can identify examples of rigid bodies in everyday life.
- I can explain why rigid body approximations are useful in physics.
- I can recognize situations where objects cannot be treated as rigid bodies.


2. Translational vs Rotational Motion
Learning outcomes
- I can distinguish between translational and rotational motion.
- I can identify examples of pure translation and pure rotation.
- I can describe systems that exhibit both types of motion.
- I can compare linear and rotational quantities.
- I can explain the importance of rotational motion in engineering and nature.


3. Reference Frames and Coordinate Systems
Learning outcomes
- I can describe the role of reference frames in mechanics.
- I can define position relative to an axis of rotation.
- I can identify rotational axes in physical systems.
- I can choose appropriate coordinate systems for analyzing motion.
- I can interpret rotational motion from different perspectives.


4. Review of Newtonian Mechanics
Learning outcomes
- I can apply Newton's Laws to translational motion.
- I can calculate forces and accelerations in simple systems.
- I can explain the relationship between force and motion.
- I can identify how Newtonian mechanics extends to rotational systems.
- I can solve basic mechanics problems involving forces and motion.
Review of Newtonian Mechanics
Newtonian mechanics provides the foundation for understanding how forces affect the motion of objects. Newton's three laws allow us to explain why objects remain at rest, why they accelerate, and how interacting objects exert forces on one another.
So far, these ideas have mainly been applied to translational motion. They also provide the foundation for rotational mechanics. Many familiar linear quantities have rotational equivalents, allowing Newton's ideas to be extended to objects that turn, spin, and roll.


Learning Targets
- I can apply Newton's Laws to translational motion.
- I can calculate forces and accelerations in simple systems.
- I can explain the relationship between force and motion.
- I can identify how Newtonian mechanics extends to rotational systems.
- I can solve basic mechanics problems involving forces and motion.
Newtonian Mechanics
Newtonian mechanics describes the motion of objects and the forces that cause changes in their motion.
It is based largely on Newton's three laws of motion.
These laws connect:
- Force
- Mass
- Acceleration
- Inertia
- Interactions between objects
Newtonian mechanics works extremely well for most everyday situations, including:
- Cars
- Bicycles
- Falling objects
- Sports
- Machines
- Buildings
- Aircraft
- Many planetary and satellite systems
For objects moving at speeds much lower than the speed of light and in situations where quantum effects are unimportant, Newtonian mechanics provides an excellent model.
Newton's First Law
Newton's First Law is sometimes called the Law of Inertia.
It states that an object remains at rest or continues moving at constant velocity unless acted upon by a resultant external force.
This means:
Resultant force = 0 → acceleration = 0
An object with zero acceleration may be:
- Stationary
- Moving at constant speed in a straight line


Inertia
Inertia is the tendency of an object to resist changes in its motion.
An object at rest tends to remain at rest.
A moving object tends to continue moving with the same velocity.
Mass is a measure of inertia.
Therefore:
Greater mass → greater resistance to acceleration
A loaded shopping cart is harder to accelerate than an empty shopping cart because it has greater mass and therefore greater inertia.
Balanced Forces
Consider a book resting on a table.
Two important forces act on it:
Weight downward
and
Normal force upward
If these forces are equal:
Resultant force = 0 N
Therefore:
Acceleration = 0 m/s²
The book remains stationary.


Balanced forces do not mean that no forces are acting.
They mean that the forces combine to produce a resultant force of zero.
Constant Velocity and Newton's First Law
Suppose a car travels along a straight road at a constant velocity of:
20 m/s
If its velocity is constant:
Acceleration = 0 m/s²
Newton's Second Law tells us:
F = ma
Therefore:
F = m × 0
So:
Resultant force = 0 N
This does not mean the engine produces no force.
The driving force may be balanced by friction and air resistance.
For example:
Driving force = 800 N forward
Resistive forces = 800 N backward
Therefore:
Resultant force = 800 − 800
Resultant force = 0 N
The car continues at constant velocity.
Newton's Second Law
Newton's Second Law connects resultant force, mass, and acceleration.
For constant mass:
F = ma
where:
- F = resultant force in newtons (N)
- m = mass in kilograms (kg)
- a = acceleration in metres per second squared (m/s²)
The equation tells us that acceleration depends on both the resultant force and the mass of the object.


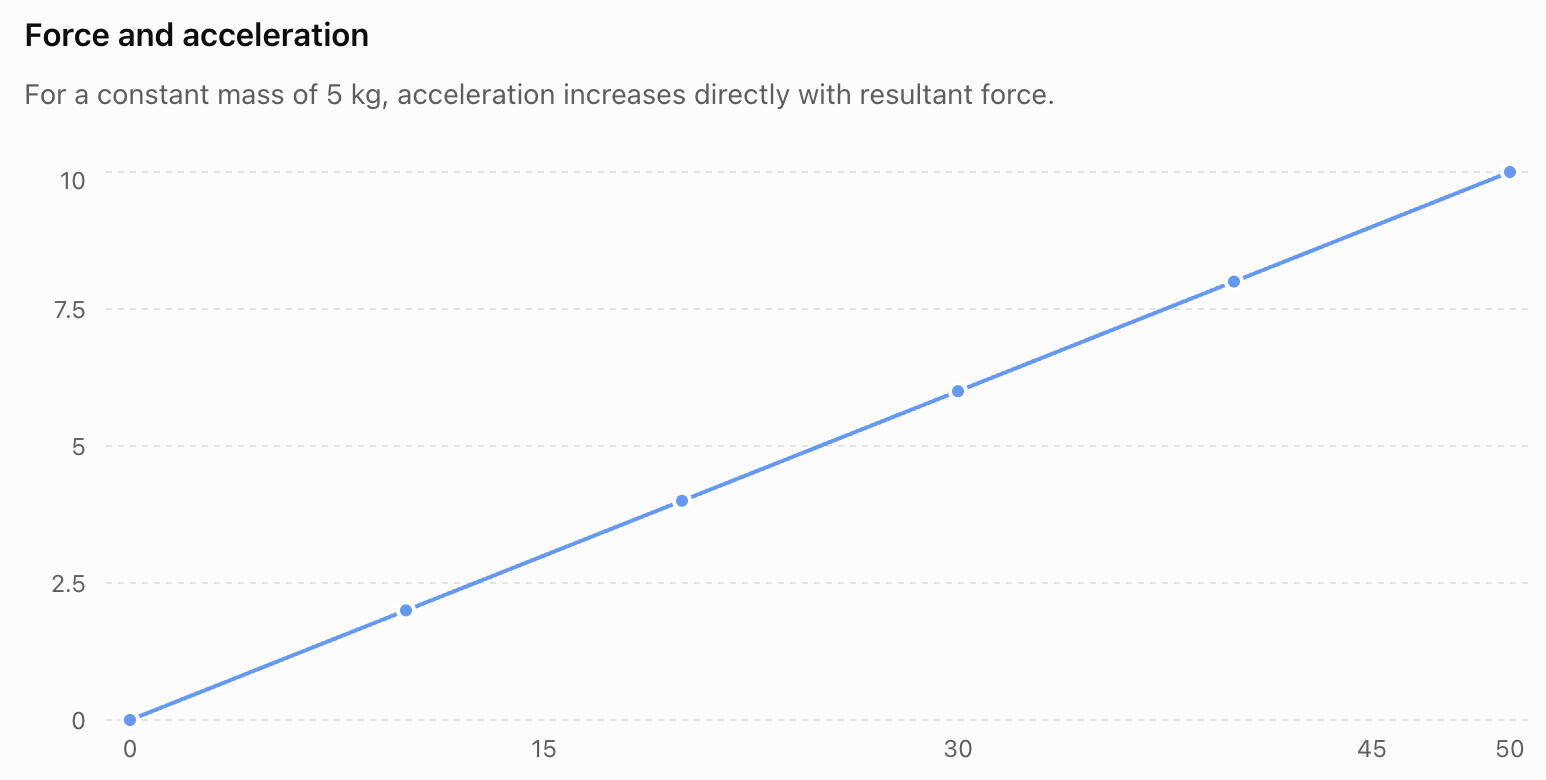
Force and Acceleration
For a constant mass:
Greater resultant force → greater acceleration
If the force doubles:
Acceleration doubles
If the force triples:
Acceleration triples
For example, consider a 5 kg object.
If:
F = 10 N
then:
a = F/m
a = 10/5
a = 2 m/s²
If the force increases to 20 N:
a = 20/5
a = 4 m/s²
Doubling the force has doubled the acceleration.
Mass and Acceleration
For a constant resultant force:
Greater mass → smaller acceleration
Suppose the same 20 N force acts on different objects.
For a 2 kg object:
a = 20/2
a = 10 m/s²
For a 4 kg object:
a = 20/4
a = 5 m/s²
For a 10 kg object:
a = 20/10
a = 2 m/s²
A more massive object requires a greater force to produce the same acceleration.
Rearranging Newton's Second Law
The equation:
F = ma
can be rearranged depending on what we need to calculate.
To calculate acceleration:
a = F/m
To calculate mass:
m = F/a
Always identify the known quantities before choosing the appropriate form of the equation.
Worked Example — Calculating Force
A 12 kg box accelerates at:
3 m/s²
Calculate the resultant force.
Use:
F = ma
Substitute:
F = 12 × 3
F = 36 N
Therefore:
Resultant force = 36 N
Worked Example — Calculating Acceleration
A resultant force of 60 N acts on a 15 kg object.
Calculate its acceleration.
Use:
a = F/m
Substitute:
a = 60/15
a = 4 m/s²
Therefore:
Acceleration = 4 m/s²
Worked Example — Calculating Mass
A force of 48 N produces an acceleration of 6 m/s².
Calculate the mass.
Use:
m = F/a
Substitute:
m = 48/6
m = 8 kg
Therefore:
Mass = 8 kg
Resultant Force
Newton's Second Law uses the resultant force, not necessarily one individual force.
The resultant force is the overall force after all forces have been combined.
Suppose:
Applied force = 50 N right
Friction = 20 N left
The resultant force is:
50 − 20 = 30 N right
If the object's mass is 10 kg:
a = F/m
a = 30/10
a = 3 m/s² right


Free-Body Diagrams
A free-body diagram shows the external forces acting on an object.
The object is usually represented by a simple box or point, with arrows representing forces.
Arrow direction shows the direction of the force.
Arrow length can be used to indicate relative force magnitude.
Common forces include:
- Weight
- Normal force
- Friction
- Tension
- Drag
- Applied force
- Thrust
- Elastic force


A good free-body diagram is often the first step toward solving a mechanics problem.
A Method for Solving Force Problems
For many Newtonian mechanics problems, use the following approach:
Identify the object being analyzed.
Then:
- Identify all external forces.
- Draw a free-body diagram.
- Choose positive and negative directions.
- Resolve forces if necessary.
- Calculate the resultant force.
- Apply F = ma.
- Check that the answer has the correct units and direction.
This method becomes especially useful when several forces act simultaneously.
Worked Example — Box with Friction
A 20 kg box is pushed horizontally with a force of:
100 N
Friction acts in the opposite direction with a force of:
40 N
First calculate the resultant force:
Fresultant = 100 − 40
Fresultant = 60 N
Now use:
a = F/m
a = 60/20
a = 3 m/s²
Therefore:
Acceleration = 3 m/s² in the direction of the push
Forces in Two Dimensions
Forces do not always act along the same line.
In two-dimensional problems, forces can be separated into components.
For example, a force may have:
- Horizontal component
- Vertical component
We can analyze the motion independently along each axis.


Newton's Second Law can then be applied separately:
ΣFx = max
and:
ΣFy = may
This allows us to analyze more complicated systems.
Weight and Gravity
Near Earth's surface, an object's weight is:
W = mg
where:
- W = weight in newtons
- m = mass in kilograms
- g = gravitational field strength
Near Earth's surface:
g ≈ 9.8 N/kg
For many introductory problems, this may be approximated as:
g ≈ 10 N/kg
For example, a 6 kg object has a weight of approximately:
W = 6 × 9.8
W = 58.8 N
directed downward.
Worked Example — Falling Object
A 4 kg object falls freely near Earth's surface.
Ignore air resistance.
Its weight is:
W = mg
W = 4 × 9.8
W = 39.2 N
The resultant force is therefore:
39.2 N downward
Now:
a = F/m
a = 39.2/4
a = 9.8 m/s² downward
This shows why freely falling objects accelerate at approximately g, regardless of their mass when air resistance is negligible.
Newton's Third Law
Newton's Third Law describes forces between interacting objects.
When object A exerts a force on object B:
Object B exerts an equal-magnitude force in the opposite direction on object A.
These forces form a Newton's Third Law pair.


The two forces:
- Are equal in magnitude.
- Act in opposite directions.
- Are the same type of interaction.
- Act on different objects.
Example — Walking
When you walk, your foot pushes backward on the ground.
The ground pushes forward on your foot.
The two forces form a Newton's Third Law pair.
The forward force from the ground helps accelerate you forward.
This is why friction is essential for ordinary walking.
Example — Rocket
A rocket pushes exhaust gases backward.
The gases exert a force on the rocket in the opposite direction.
The rocket therefore accelerates forward.


A rocket does not need to push against the air.
It works because of the interaction between the rocket and the expelled gases.
Third-Law Pairs Are Not Balanced Forces
This distinction is extremely important.
Consider a book resting on a table.
The book's weight acts downward.
The table's normal force acts upward.
These forces may balance, but they are not a Newton's Third Law pair, because they both act on the same object: the book.
A Third Law pair acts on different objects.
For example:
Earth pulls book downward.
Book pulls Earth upward.
These two gravitational forces form a Third Law pair.
Force and Motion
A common misunderstanding is that a force is needed to keep an object moving.
Newton's First Law tells us otherwise.
A resultant force is needed to change velocity, not simply to maintain velocity.
Therefore:
Resultant force = 0 → constant velocity
Resultant force ≠ 0 → acceleration
Remember that acceleration can mean:
- Speeding up
- Slowing down
- Changing direction
A force can therefore change an object's motion even when its speed remains constant.
Circular Motion and Force
An object moving in a circle may travel at constant speed, but its velocity is continually changing because its direction changes.
Therefore, it is accelerating.
This acceleration requires a resultant force directed toward the centre of the circular path.
This is called centripetal force.


This provides an important connection between Newtonian mechanics and rotational motion.
From Translational to Rotational Mechanics
Newton's laws were initially introduced using translational motion, but similar principles can be applied to rotation.
There is a useful correspondence:
| Translational Mechanics | Rotational Mechanics |
|---|---|
| Position, x | Angular position, θ |
| Displacement, s | Angular displacement, Δθ |
| Velocity, v | Angular velocity, ω |
| Acceleration, a | Angular acceleration, α |
| Mass, m | Moment of inertia, I |
| Force, F | Torque, τ |
| Momentum, p | Angular momentum, L |
This connection allows many familiar Newtonian ideas to be extended to rotating systems.
Force and Torque
In translational motion:
A resultant force produces linear acceleration.
This is represented by:
F = ma
In rotational motion:
A resultant torque produces angular acceleration.
For rotation about a fixed axis, this is commonly written:
τ = Iα
where:
- τ = resultant torque
- I = moment of inertia
- α = angular acceleration
This is one of the most important connections between translational and rotational mechanics.
Mass and Moment of Inertia
Mass measures an object's resistance to linear acceleration.
Moment of inertia measures an object's resistance to angular acceleration about a particular axis.
For translation:
More mass → harder to accelerate
For rotation:
Greater moment of inertia → harder to produce angular acceleration


Moment of inertia depends not only on how much mass an object has, but also on how that mass is distributed relative to the rotational axis.
Newton's First Law and Rotation
Newton's First Law also has a rotational counterpart.
For translation:
No resultant force → no linear acceleration
For rotation:
No resultant torque → no angular acceleration
Therefore, an object with no resultant torque will:
- Remain non-rotating if initially non-rotating, or
- Continue rotating at constant angular velocity if already rotating.
This idea is sometimes called rotational inertia.
Newton's Second Law and Rotation
The linear relationship:
F = ma
has the rotational counterpart:
τ = Iα
Compare them:
Force → causes linear acceleration
Torque → causes angular acceleration
Mass → resists linear acceleration
Moment of inertia → resists angular acceleration
This parallel makes rotational mechanics easier to understand because it builds directly on familiar Newtonian concepts.
Newton's Third Law and Rotating Systems
Newton's Third Law also applies when forces produce rotation.
Imagine using a wrench to turn a bolt.
You exert a force on the wrench.
The wrench and bolt exert forces back through your hand.
Or consider bicycle gears.
One gear pushes against another.
The second gear pushes back with an equal and opposite contact force.


Newton's Third Law therefore remains important in rotational systems.
Worked Example — From Force to Torque
Imagine pushing on a door.
If you push directly toward the hinges, the door may barely rotate.
If you apply the same force perpendicular to the door near the handle, the door rotates easily.
The force has not necessarily changed.
What changed is where and how the force was applied.
For a force acting perpendicular to the lever arm:
τ = rF
where:
- τ = torque
- r = perpendicular distance from the axis
- F = force
Suppose:
r = 0.80 m
and:
F = 25 N
Then:
τ = 0.80 × 25
τ = 20 N m
This torque can produce angular acceleration of the door.
Translational and Rotational Motion Together
Many systems involve both translation and rotation.
Consider a rolling bicycle wheel.
The centre of mass moves forward.
This is translation.
The wheel turns around its axle.
This is rotation.


A complete analysis may therefore require both:
F = ma
and rotational relationships involving torque.
This is why Newtonian mechanics provides the foundation for the study of rigid body mechanics.
Worked Example — Multiple Forces
A 10 kg crate is pushed to the right with a force of:
70 N
Friction acts to the left with:
30 N
Calculate the acceleration.
First find the resultant force:
Fresultant = 70 − 30
Fresultant = 40 N right
Then:
a = F/m
a = 40/10
a = 4 m/s² right
The crate accelerates because the forces are unbalanced.
Worked Example — Balanced Forces
A 15 kg object is pulled right with:
45 N
and left with:
45 N
Resultant force:
Fresultant = 45 − 45
Fresultant = 0 N
Therefore:
a = 0 m/s²
This does not tell us that the object must be stationary.
It could be:
- At rest, or
- Moving at constant velocity
Newton's First Law applies in both situations.
Worked Example — Finding an Unknown Force
A 6 kg object accelerates to the right at:
5 m/s²
A 50 N force acts to the right.
A resistive force acts to the left.
First calculate the required resultant force:
Fresultant = ma
Fresultant = 6 × 5
Fresultant = 30 N right
Therefore:
50 − Fresistance = 30
So:
Fresistance = 20 N
The resistive force is:
20 N left
Common Mistakes
Mistake: Thinking force causes velocity
A resultant force causes acceleration, which means a change in velocity.
Mistake: Thinking an object with no resultant force must be stationary
It may also move at constant velocity.
Mistake: Using one force instead of the resultant force in F = ma
Newton's Second Law uses the overall resultant force.
Mistake: Confusing mass and weight
Mass is measured in:
kg
Weight is a force measured in:
N
Mistake: Assuming Third Law force pairs cancel
Third Law pairs act on different objects, so they do not cancel when analyzing one object.
Mistake: Thinking constant speed always means zero acceleration
An object moving in a circle at constant speed is accelerating because its direction changes.
Mistake: Treating torque and force as identical
Force changes translational motion.
Torque describes the turning effect of a force and can change rotational motion.
Mistake: Assuming mass and moment of inertia are the same
Mass describes resistance to linear acceleration.
Moment of inertia describes resistance to angular acceleration and also depends on the distribution of mass.
Key Terms
Newtonian mechanics – the study of motion using Newton's laws and related principles.
Inertia – resistance to a change in motion.
Resultant force – the overall force after all forces have been combined.
Mass – a measure of inertia.
Acceleration – rate of change of velocity.
Free-body diagram – a diagram showing the external forces acting on an object.
Normal force – a contact force acting perpendicular to a surface.
Friction – a force that opposes relative motion or attempted motion between surfaces.
Weight – the gravitational force acting on an object.
Newton's Third Law pair – equal-magnitude, opposite-direction forces acting on different interacting objects.
Torque – the turning effect of a force.
Moment of inertia – a measure of resistance to angular acceleration about an axis.
Angular acceleration – rate of change of angular velocity.
Check Your Understanding
1. State Newton's First Law.
2. What is meant by inertia?
3. A 12 kg object experiences a resultant force of 36 N. Calculate its acceleration.
4. A 5 kg object accelerates at 8 m/s². Calculate the resultant force.
5. A 60 N force acts right while a 25 N friction force acts left. Calculate the resultant force.
6. If the object in Question 5 has a mass of 7 kg, calculate its acceleration.
7. A car moves at constant velocity along a straight road. What can you say about the resultant force acting on it?
8. Explain why Newton's Third Law forces do not cancel each other.
9. A 4 kg object falls freely near Earth. Ignoring air resistance, calculate its weight and acceleration using g = 9.8 N/kg.
10. What is the rotational equivalent of force?
11. What is the rotational equivalent of mass in the relationship between torque and angular acceleration?
12. Explain how Newton's Second Law can be extended from translational motion to rotational motion.
13. A 20 N force is applied perpendicular to a door 0.75 m from its hinges. Calculate the torque.
14. Explain why a rolling wheel may require both translational and rotational mechanics to describe its motion fully.
Key Takeaways
- Newtonian mechanics connects forces with changes in motion.
- Newton's First Law explains inertia and motion when the resultant force is zero.
- Resultant force = 0 means acceleration = 0, not necessarily velocity = 0.
- Newton's Second Law for constant mass is F = ma.
- Greater resultant force produces greater acceleration for the same mass.
- Greater mass produces smaller acceleration for the same force.
- Free-body diagrams help identify and combine the forces acting on an object.
- Newton's Third Law describes equal-magnitude, opposite-direction forces acting on different objects.
- A resultant force causes acceleration, not simply motion.
- Circular motion involves acceleration because the direction of velocity changes.
- Newtonian mechanics extends naturally into rotational mechanics.
- Force corresponds to torque.
- Mass corresponds to moment of inertia when comparing linear and rotational dynamics.
- Linear acceleration corresponds to angular acceleration.
- The linear relationship F = ma has the rotational counterpart τ = Iα for rotation about a fixed axis.
- These connections provide the foundation for studying torque, rotational dynamics, equilibrium, rolling motion, and rigid body mechanics.
5. Applications of Rigid Body Mechanics
Learning outcomes
- I can identify real-world applications of rigid body mechanics.
- I can explain how rotational mechanics is used in engineering.
- I can describe examples involving vehicles, machinery, and sports.
- I can recognize the importance of rotational analysis in technology.
- I can connect course concepts to practical systems.
Applications of Rigid Body Mechanics
Rigid body mechanics is used whenever the size, shape, balance, rotation, or distribution of mass of an object matters. It allows engineers and scientists to analyze objects such as cars, bicycles, gears, bridges, turbines, aircraft, robots, and sports equipment without having to model every tiny deformation in the material.
The ideas developed in rigid body mechanics — translation, rotation, torque, centre of mass, moment of inertia, equilibrium, and angular motion — have applications throughout engineering, technology, transportation, sports, and everyday life.


Learning Targets
- I can identify real-world applications of rigid body mechanics.
- I can explain how rotational mechanics is used in engineering.
- I can describe examples involving vehicles, machinery, and sports.
- I can recognize the importance of rotational analysis in technology.
- I can connect course concepts to practical systems.
From Physics Models to Real Systems
A rigid body is an idealized object whose shape and dimensions are assumed to remain constant.
This approximation is extremely useful because many real objects deform so little during normal operation that the deformation can be ignored.
Engineers can then focus on:
- Forces
- Acceleration
- Torque
- Angular acceleration
- Centre of mass
- Moment of inertia
- Equilibrium
- Stability
For example, when analyzing a bicycle wheel, engineers usually do not need to calculate how every spoke stretches by a tiny amount. They can initially treat the wheel as a rigid body and concentrate on its overall motion and rotation.
Rotational Mechanics in Engineering
Much of modern engineering involves objects that rotate.
Examples include:
- Motors
- Generators
- Gears
- Wheels
- Turbines
- Pumps
- Fans
- Propellers
- Drills
- Robotic joints


Engineers need to understand how forces produce torque and how torque produces changes in rotational motion.
For rotation about a fixed axis:
τ = Iα
where:
- τ = resultant torque
- I = moment of inertia
- α = angular acceleration
This relationship is the rotational counterpart of:
F = ma
Motors
An electric motor converts electrical energy into mechanical motion.
Inside the motor, electromagnetic forces produce torque on the rotor.
The rotor then turns.


Rotational mechanics helps engineers determine:
- Required torque
- Angular acceleration
- Rotational speed
- Power output
- Forces on bearings and shafts
Electric motors are found in:
- Electric vehicles
- Fans
- Washing machines
- Elevators
- Robots
- Power tools
- Pumps
- Computer equipment
Understanding rotational mechanics is therefore essential to electrical and mechanical engineering.
Generators
A generator performs a process related to a motor, but in the opposite energy-transfer direction.
Mechanical rotation is used to generate electrical energy.
Generators are commonly driven by turbines.
For example:
Moving water → turbine rotation → generator rotation → electrical energy
or:
Steam → turbine rotation → generator rotation → electrical energy


Rotational mechanics is needed to determine whether the rotating components can safely handle the required speeds, torques, and forces.
Wind Turbines
Wind turbines provide an excellent example of rigid body mechanics.
Moving air produces forces on the blades.
Because these forces act at distances from the rotational axis, they create torque.
The torque causes the rotor to turn.
The rotating system then drives a generator.


Engineers must consider:
- Blade length
- Rotational speed
- Torque
- Moment of inertia
- Wind forces
- Centre of mass
- Structural loads
Long turbine blades can produce large torques because forces act far from the rotational axis.
Gears
Gears are rotating components with teeth that transfer rotational motion from one shaft to another.
They can change:
- Rotational speed
- Torque
- Direction of rotation


Consider a small gear driving a larger gear.
The larger gear usually rotates more slowly but can provide greater torque.
This principle is used in:
- Cars
- Bicycles
- Clocks
- Industrial machines
- Robotics
- Power tools
Gear systems allow engineers to trade rotational speed for torque depending on what a machine needs to do.
Vehicles
Vehicles contain many systems involving rigid body mechanics.
A moving car involves both:
Translational motion
and
Rotational motion
The car itself moves along the road while its wheels rotate.
Inside the vehicle, additional components rotate:
- Engine components
- Electric motors
- Transmission gears
- Driveshafts
- Axles
- Wheels


Understanding how these motions interact is essential to vehicle design.
Rolling Wheels
A rolling wheel experiences both translation and rotation.
The centre of the wheel moves forward with linear velocity:
v
At the same time, the wheel rotates with angular velocity:
ω
For rolling without slipping:
v = rω
where:
- v = linear speed
- r = wheel radius
- ω = angular velocity
This relationship connects the translational and rotational motion of the vehicle.
Worked Example — Car Wheel
A car wheel has a radius of:
0.30 m
and rotates with an angular velocity of:
40 rad/s
Assuming the wheel rolls without slipping:
v = rω
Substitute:
v = 0.30 × 40
v = 12 m/s
Therefore, the car travels at approximately:
12 m/s
This is about:
43 km/h
The rotational speed of the wheel is therefore directly connected to the vehicle's linear speed.
Braking
Braking is another important application of rotational mechanics.
When brakes are applied, friction produces a torque that opposes the rotation of the wheels.
This produces an angular deceleration.


The braking system must convert the vehicle's kinetic energy into other forms, mainly thermal energy.
Engineers must consider:
- Braking torque
- Wheel radius
- Vehicle mass
- Friction
- Heat production
- Stopping distance
Rotational mechanics is therefore directly connected to vehicle safety.
Vehicle Stability
Rigid body mechanics is also used to determine whether a vehicle is likely to tip or remain stable.
Important factors include:
- Centre of mass height
- Width of the vehicle
- Vehicle speed
- Turning radius
- Forces acting on the tyres


A vehicle with a high centre of mass is generally more susceptible to tipping than a similar vehicle with a lower centre of mass.
This is one reason centre-of-mass position is important in vehicle design.
Bicycles
A bicycle is an excellent example of several rigid body concepts working together.
The wheels rotate.
The bicycle translates.
The pedals rotate.
The crank rotates.
The gears rotate.
The rider and bicycle together have a centre of mass.


Changing gears changes the relationship between pedal rotation and wheel rotation.
This allows the rider to choose between:
- Greater wheel rotation for each pedal revolution
- Greater torque at the wheel
depending on riding conditions.
Machinery
Industrial machines contain many rotating rigid-body components.
Examples include:
- Shafts
- Flywheels
- Pulleys
- Gears
- Rollers
- Turbines
- Cutting tools
These components can rotate thousands of times per minute.
Engineers must calculate the forces and torques involved to prevent excessive vibration, wear, or mechanical failure.
Flywheels
A flywheel is a rotating object designed to store rotational kinetic energy.
Flywheels often have significant mass distributed away from their rotational axis.
This gives them a relatively large moment of inertia.


Once rotating, a flywheel resists rapid changes in angular velocity.
Flywheels can therefore help:
- Smooth engine operation
- Store energy
- Stabilize rotating machinery
- Maintain rotational motion between power strokes
Moment of Inertia in Design
Moment of inertia is extremely important in engineering because it determines how difficult it is to change an object's rotational motion.
It depends on:
- Total mass
- Distribution of mass
- Rotational axis
Mass located farther from the axis generally contributes more strongly to moment of inertia.


Engineers can therefore change rotational behaviour by changing where the mass is located, even if the total mass remains unchanged.
Robotics
Robots often contain several rigid components connected by rotating joints.
A robotic arm might contain:
- Shoulder joint
- Elbow joint
- Wrist joint
- Gripper
Each section can be modeled as a rigid body.


Engineers must calculate the torque required at each joint.
If the robot picks up a heavy object, the motors may need to produce greater torque.
The distance between the load and the joint also matters.
A load held farther away usually produces a greater turning effect.
Worked Example — Robotic Arm
A robot holds a 50 N object at the end of a horizontal arm.
The object is:
0.80 m
from the rotational joint.
The force acts perpendicular to the arm.
Calculate the torque produced by the load.
Use:
τ = rF
Substitute:
τ = 0.80 × 50
τ = 40 N m
The motor must provide sufficient opposing torque to support the load.
If the object were held only 0.40 m from the joint:
τ = 0.40 × 50
τ = 20 N m
Moving the object closer to the axis halves the torque produced by its weight.
Construction and Structures
Rigid body mechanics is also used to analyze structures such as:
- Beams
- Cranes
- Ladders
- Bridges
- Signs
- Platforms
When these objects are stationary, engineers often analyze their equilibrium.


For equilibrium:
Resultant force = 0
and:
Resultant torque = 0
Both conditions are necessary.
An object could have zero resultant force but still rotate if the forces produce a resultant torque.
Cranes
A crane must remain stable while lifting heavy loads.
The load produces a turning effect about the base of the crane.
The magnitude of this torque depends on:
- Weight of the load
- Horizontal distance from the pivot
A heavy counterweight is often placed on the opposite side.
The counterweight produces an opposing torque.
This helps prevent the crane from tipping.
Worked Example — Crane
A crane lifts a load with a weight of:
10,000 N
The load is:
5 m
from the pivot.
The torque produced by the load is:
τ = rF
τ = 5 × 10,000
τ = 50,000 N m
To remain in rotational equilibrium, the crane requires sufficient opposing torque from its structure and counterweight.
This demonstrates why the position of a load can be just as important as its weight.
Aircraft
Aircraft involve many applications of rotational mechanics.
An aircraft can rotate around three principal axes:
- Roll
- Pitch
- Yaw


Control surfaces create forces that produce torques around these axes.
Pilots and flight-control computers use these rotational effects to control the orientation of the aircraft.
Understanding rigid body rotation is therefore fundamental to aerospace engineering.
Ships and Boats
Ships can also rotate around different axes.
They can:
- Roll from side to side.
- Pitch forward and backward.
- Yaw left and right.
Their centre of mass and buoyancy strongly influence their stability.
Rigid body mechanics helps naval engineers design ships that remain stable while carrying cargo and travelling through waves.
Sports
Rotational mechanics is extremely important in sports.
Athletes frequently use rotation to increase speed, control movement, or transfer energy.
Examples include:
- Gymnastics
- Diving
- Figure skating
- Cycling
- Golf
- Tennis
- Baseball
- Football
- Discus
- Hammer throw


Understanding rotation helps explain why athletes change their body position during different movements.
Figure Skating
A spinning figure skater provides a classic example of rotational mechanics.
When the skater pulls their arms inward, their mass moves closer to the rotational axis.
This reduces their moment of inertia.
If external torque is small, angular momentum is approximately conserved.
As a result:
Moment of inertia decreases → angular velocity increases
The skater spins faster.


When the skater extends their arms again, moment of inertia increases and angular velocity decreases.
Diving and Gymnastics
Divers and gymnasts use similar principles.
A diver who curls into a compact position reduces their moment of inertia and can rotate more quickly.
Extending the body increases moment of inertia and slows the rotation.


Athletes therefore control rotational motion partly by changing the distribution of their body mass.
Bats, Rackets, and Clubs
Many sports involve rotating an object about the athlete's body.
Examples include:
- Baseball bat
- Tennis racket
- Golf club
- Hockey stick
A force applied by the athlete produces torque and angular acceleration.
The equipment's:
- Length
- Mass
- Mass distribution
- Moment of inertia
all influence how easily it can be swung.


Designers can therefore adjust sports equipment to change its rotational characteristics.
Worked Example — Sports Equipment
Imagine two bats with the same total mass.
Bat A has more of its mass concentrated near the handle.
Bat B has more mass concentrated near the far end.
Bat B generally has a greater moment of inertia about the athlete's hands.
Therefore, Bat B is generally harder to produce the same angular acceleration in.
This demonstrates an important principle:
Moment of inertia depends on mass distribution, not just total mass.
Rotational Mechanics in Technology
Many technologies rely on extremely precise control of rotation.
Examples include:
- Hard drives
- Drones
- Cameras
- Gyroscopes
- Robotics
- Satellites
- Electric vehicles
- Manufacturing equipment


In these systems, small changes in rotational motion can strongly affect performance.
Drones
A multirotor drone uses several rapidly rotating propellers.
Electric motors control the angular velocity of each propeller.
Changing the rotational speeds changes the forces and torques acting on the drone.
This allows the drone to:
- Rise
- Descend
- Roll
- Pitch
- Yaw
Rigid body mechanics is therefore central to drone stability and control.
Satellites
Satellites must control their orientation, not simply their position.
A satellite may need to point:
- Solar panels toward the Sun.
- Antennas toward Earth.
- Cameras toward a target.
- Scientific instruments toward space.
Some satellites use devices called reaction wheels to control orientation.


By changing the rotation of an internal wheel, the spacecraft can change its own rotational motion while conserving angular momentum.
This is a direct application of rotational mechanics.
Balancing Objects
Centre of mass and torque also explain why some objects are more stable than others.
An object is generally more stable when it has:
- A low centre of mass.
- A wide base of support.


If the line of action of the object's weight moves outside its base of support, gravity can produce a torque that causes the object to tip.
This principle matters in:
- Vehicle design
- Furniture design
- Construction equipment
- Sports
- Robotics
Connecting Course Concepts
The concepts from this course work together in practical systems.
Rigid bodies
Allow us to model objects without considering small deformations.
Translational motion
Describes movement of the object's centre of mass.
Rotational motion
Describes changes in orientation.
Reference frames
Allow motion to be described relative to chosen coordinates and axes.
Newton's Laws
Connect forces with translational acceleration.
Torque
Connects forces with rotational effects.
Moment of inertia
Describes resistance to changes in rotational motion.
Centre of mass
Helps determine balance, stability, and translational behaviour.
Equilibrium
Occurs when resultant forces and resultant torques are zero.
Together, these ideas allow us to analyze real machines and structures.
Worked Example — Putting It Together
Consider a bicycle travelling along a road.
The bicycle frame undergoes mainly translation.
The wheels experience translation and rotation.
The tyres interact with the road through friction.
The rider produces torque on the pedals.
The gears transfer torque.
The wheels have moment of inertia.
The rider and bicycle together have a centre of mass.
Newton's Laws describe the forces and acceleration.
The relationship:
v = rω
connects wheel rotation to the bicycle's linear motion.
A seemingly simple bicycle therefore demonstrates many of the central ideas of rigid body mechanics.
Common Mistakes
Mistake: Thinking rigid body mechanics only applies to stationary structures
Rigid bodies can translate, rotate, accelerate, or remain in equilibrium.
Mistake: Thinking rotational mechanics is only about wheels
Rotational mechanics applies to gears, motors, turbines, robots, athletes, aircraft, satellites, tools, and many other systems.
Mistake: Assuming only force magnitude matters
The position and direction of a force determine its turning effect.
Mistake: Thinking heavier objects always have greater moment of inertia
Moment of inertia depends on both mass and its distribution relative to the axis.
Mistake: Treating translation and rotation as completely separate
Many real systems involve both simultaneously.
Mistake: Thinking zero resultant force guarantees equilibrium
For a rigid body to be in complete equilibrium, both:
Resultant force = 0
and:
Resultant torque = 0
are required.
Key Terms
Rigid body mechanics – the study of the motion and equilibrium of objects whose deformation is assumed negligible.
Translation – motion from one position to another.
Rotation – motion around an axis.
Torque – the turning effect of a force.
Angular velocity – rate of change of angular position.
Angular acceleration – rate of change of angular velocity.
Moment of inertia – resistance to angular acceleration about an axis.
Centre of mass – the average position of an object's mass.
Equilibrium – a condition with no resultant linear or angular acceleration.
Flywheel – a rotating component designed to store rotational kinetic energy.
Gear – a toothed rotating component used to transfer rotational motion and torque.
Stability – the tendency of a system to maintain or return toward a particular orientation or condition.
Check Your Understanding
1. Give three examples of machines that use rotational motion.
2. Explain how torque is involved in the operation of an electric motor.
3. Why are gears useful in machines?
4. Explain why a moving car involves both translational and rotational motion.
5. A wheel has a radius of 0.25 m and rotates at 20 rad/s. Calculate the linear speed of the vehicle if the wheel rolls without slipping.
6. Explain how brakes use torque to slow a vehicle.
7. Why does the height of a vehicle's centre of mass affect its stability?
8. Explain why a robotic arm requires greater torque when it holds the same load farther from a joint.
9. A 100 N load is held 2 m from a crane's pivot. Calculate the torque produced by the load.
10. Why does a figure skater rotate faster after pulling their arms inward?
11. Explain how rigid body mechanics is used to control the orientation of a satellite.
12. Choose one real system — such as a bicycle, car, turbine, robot, aircraft, or sports movement — and identify at least three rigid body mechanics concepts involved.
Key Takeaways
- Rigid body mechanics has applications throughout engineering, transportation, machinery, technology, sports, and space exploration.
- Rotational systems are analyzed using quantities such as torque, angular velocity, angular acceleration, and moment of inertia.
- Electric motors use torque to produce rotation.
- Gears transfer rotational motion and can change torque and angular speed.
- Vehicle wheels combine translation and rotation.
- The relationship v = rω connects linear and rotational motion for rolling without slipping.
- Brakes produce torque that opposes wheel rotation.
- Centre of mass is important when analyzing vehicle and structural stability.
- Robots use rotational mechanics to control joints and move loads.
- Cranes and structures require analysis of both forces and torques.
- Aircraft rotate about roll, pitch, and yaw axes.
- Athletes manipulate torque, angular velocity, and moment of inertia during many sporting movements.
- Technologies such as drones and satellites depend on precise rotational control.
- Real systems often combine Newton's Laws, translation, rotation, torque, equilibrium, centre of mass, and moment of inertia.
Did You Know?
The same basic rotational principles can describe objects with enormously different sizes. Engineers can use rigid body mechanics to study a tiny gear inside a watch, a spinning car wheel, a wind turbine more than 100 metres across, or the orientation of a spacecraft travelling through the Solar System.