Rotational Kinematics

Hệ thống: Young Education
Khoá học: Rigid Body Mechanics
Book: Rotational Kinematics
Được in bởi: Guest user
Ngày: Thứ Hai, 9 tháng 11 2026, 4:39 PM

1. Angular Displacement

Learning outcomes
  • I can define angular displacement.
  • I can measure angular displacement in degrees and radians.
  • I can distinguish between angular and linear displacement.
  • I can interpret rotational motion using angular position.
  • I can solve problems involving angular displacement.

Key Topics:
  • Definition of a rigid body.
  • Real-world examples of rigid bodies.
  • Assumptions in rigid body mechanics.

Angular Displacement

Angular displacement describes how far an object has rotated and in which direction it has rotated.

Instead of measuring motion along a straight line in metres, rotational motion can be described using an angle.

Angular displacement is commonly represented by the Greek letter:

θ (theta)

It can be measured in:

  • degrees (°)
  • radians (rad)
  • revolutions

For example, if a wheel turns through one-quarter of a complete rotation, its angular displacement is:

90° = π/2 rad

https://images.openai.com/static-rsc-4/Dr3qkAyQdGe1z80cjszUcbPmOqcj42BWfOV5cwhT-6jaA92Jq12BSt4EX8qrZrSgz-6dMG4q9T3NO44Zpnf0P1hrbXSR3tttyWYFUmVsWaRJOAdESHHkdAutU5PaM9hHZuuLd8XCIdVnsJ7xRtec-hjDGCAp_h073XvsxHsOW694DaQuMiMPmGIgZ3RxDPTE?purpose=fullsize
 
https://images.openai.com/static-rsc-4/4b_7ZerpZk0xRZpbvaBGHlBxabs13801szt9VJAnJJ5J96D6zq7VaOIVxksMIMeTM_e7KByCSdwCOyBs5kVt2fDkrGyQSVWVfGgvNR34tAsh0a-ijyAvDCNOqk_7GN7UPGJFiYE8iOEdT9RF820Ppc4cK11mLjzZS5Eeak6jW-KtWwklsUFCJ3NWuK5U-t56?purpose=fullsize
 
https://images.openai.com/static-rsc-4/Rjl8xDZal1KXrFzqngF1BLHHvl6xJg6ZSUWfnrIgFtNcQu23SZwZ8dq_dGayyT_VETVUFh82poSoJnyb7yDXbhgfgPQ0cVy6A53J4GqiSqmddmG99sufIx5q29lfioD8721wEPbc0sgopsL8GbfzQy2HQhQ5X_161dIGheEOa6n62LJwL7tzw-v3Tz_zCQjp?purpose=fullsize
 
8

Angular Position

Before angular displacement can be understood, it is useful to define angular position.

Angular position describes the orientation of an object relative to a chosen reference line.

For example, imagine a rotating wheel with a mark on its edge.

If the mark begins on the positive horizontal axis, we could define:

θ = 0°

After one-quarter turn counterclockwise:

θ = 90°

After half a turn:

θ = 180°

After three-quarters of a turn:

θ = 270°

Angular position tells us where the rotating object is relative to the chosen reference direction.


Angular Displacement

Angular displacement is the change in angular position.

Therefore:

Δθ = θ_f − θ_i

where:

  • Δθ = angular displacement
  • θ_i = initial angular position
  • θ_f = final angular position

This is similar to linear displacement:

Δx = x_f − x_i

Angular displacement describes a change in orientation rather than a change in linear position.


Worked Example: Change in Angular Position

An object begins at:

θ_i = 30°

and rotates to:

θ_f = 110°

Then:

Δθ = θ_f − θ_i

Δθ = 110° − 30°

Δθ = 80°

The angular displacement is 80° in the positive rotational direction.


Direction of Angular Displacement

Angular displacement includes direction.

A common sign convention is:

counterclockwise = positive

clockwise = negative

https://images.openai.com/static-rsc-4/xD4HMbk3qAEgBxKUQBSjdCZHBLDWAc6mgqYnGXtOKSM0xaamjuWMhPfuoWgzcCpgQNtPXT0uMBCXkBxLxinlhx7Eh9hBf9xyX85jzMbpyYR7Kk-6tGRLnMeMCS-yNzEyrnAl2hfZXvsqug8CLrfRSP0VjnYK8uCjM78FUojpWDLtSR7fB-clfrneGXDlg4w9?purpose=fullsize
 
https://images.openai.com/static-rsc-4/sFXFT_ez_DGWQTbGoMgx1CUJbjqnX7m_DwUUpiFmvSHTNuSuhIn5j9FDokl54wgcubEu8icD1H4mo8Z4iUSszzKIGi7NK4U1PIuIkDk1gDrhAB8WWYg1E-sDkQQqizPHJ5XXe1D6A3I9YGwgzw-rAu7qNHgVHAXHfqdJftDjWQomXMA_8eoGCj7OwHSQZ821?purpose=fullsize
 
https://images.openai.com/static-rsc-4/plhCBmEOLCUbpczkSfqHFMqdgvFCeCv8yKNwJcaxWsUrEfe0_CEPML0C-cPWTe9DyvU6OYbprTU4KiIgwsbh7j_n5L27g6atQhes_TpCC_Qm5gq2KHzjOuHcZX_cPccym1TlZEtrUSYlDd6WeauEjkPdbMRfdc4ta-_cI0zZw5gG2fLX7-9O-PzYQYYbCAKb?purpose=fullsize
 
7

Therefore:

a 60° counterclockwise rotation can be written as:

Δθ = +60°

A 60° clockwise rotation can be written as:

Δθ = −60°

The sign convention should always be stated or understood before solving a problem.


Worked Example: Clockwise Rotation

A wheel rotates clockwise through 135°.

Using the usual convention:

clockwise = negative

Therefore:

Δθ = −135°

The negative sign describes direction.

It does not mean the wheel rotated through a "negative amount" of angle.


Degrees

A complete revolution is divided into:

360°

Therefore:

Rotation Angle
1/4 revolution 90°
1/2 revolution 180°
3/4 revolution 270°
1 revolution 360°
2 revolutions 720°

Degrees are familiar and convenient for describing angles, but physics often uses another unit:

radians.


Radians

A radian is the SI unit used for angular displacement.

One complete revolution is:

2π rad

Since one complete revolution is also 360°:

360° = 2π rad

Therefore:

180° = π rad

and:

90° = π/2 rad

https://images.openai.com/static-rsc-4/iaV9X979vKxMZN28D-GrDsp80huYjim7-V0U6PQLsxeDmp1oVdx6wyZ1UFPq-KSt_ZyhUQ-Faz_7QjUVNEYdgosvzKxB3A_FvDPMjB8FF77stzgENayZrHff2vpzuKHkf4Jm1cbDMvlk3kuTVaDWhBDtXyjFstN2Vl5AUn4zYuUN7kNyKhpJk16m3NZU8FDm?purpose=fullsize
 
https://images.openai.com/static-rsc-4/FVHJp7P2FoqpvaedE4LVbBUYOTgM4SFXHdjw4Ham5Irpjhkd-oesc7hM40FWQyv6dszKR6WWc8GfU8GokkE03WvDcHhsyQ60F11oUXN8cLcVuiGGoAyt7Uwj6dFEjZOcHXR1zsG4r_EG1CfodgyXgRQELl8WAEs5n7aoLP_52_XOZMLF5jp5IfjsHMRKFPpr?purpose=fullsize
 
https://images.openai.com/static-rsc-4/LXh_a-ZZr1LOLLH53Ycyx4wUYRu4rPoDxmUszwykb5fov1uXtQodpc1IywVp8oy4JSXpmPfJmLcyXJRJUi5a6QoLSBsvVZznGLCj3fWm3Vh671RItWEgqp4HbmTHZRGhJPxkYEz7dmiA2H3644kDo-F-iMTktVh1N5AlZSdkZGTVvuYJQuXGn8fsw6LcnN-d?purpose=fullsize
 
5

What Is One Radian?

Consider a circle with radius r.

Imagine an arc along the circumference whose length s is exactly equal to the radius.

When:

s = r

the angle at the centre is:

1 rad

This gives the important relationship:

θ = s/r

when θ is measured in radians.


Angular Displacement and Arc Length

For circular motion:

s = rθ

where:

  • s = arc length or linear distance travelled along the circular path
  • r = radius
  • θ = angular displacement in radians

This equation creates a direct connection between angular and linear motion.


Why Radians Are Useful

Radians make relationships such as:

s = rθ

very simple.

If degrees were used directly, an additional conversion factor would be required.

For this reason, rotational physics calculations generally use radians.


Converting Degrees to Radians

Since:

180° = π rad

we can convert degrees to radians using:

radians = degrees × π/180


Example: 60° to Radians

θ = 60° × π/180

θ = π/3

Therefore:

60° = π/3 rad

or approximately:

1.05 rad


Example: 225° to Radians

θ = 225° × π/180

Simplify:

θ = 5π/4

Therefore:

225° = 5π/4 rad

≈ 3.93 rad


Converting Radians to Degrees

Use:

degrees = radians × 180/π


Example: π/6 rad

θ = π/6 × 180/π

θ = 30°

Therefore:

π/6 rad = 30°


Example: 2.5 rad

θ = 2.5 × 180/π

θ ≈ 143.2°

Therefore:

2.5 rad ≈ 143°


Common Degree-Radian Values

Degrees Radians
0° 0
30° π/6
45° π/4
60° π/3
90° π/2
120° 2π/3
180° π
270° 3π/2
360° 2π

These common values are useful in rotational motion.


Revolutions and Angular Displacement

Angular displacement can also be described using revolutions.

One revolution is:

1 rev = 360° = 2π rad

Therefore:

number of revolutions = θ/(2π)

when θ is measured in radians.


Worked Example: Revolutions to Radians

A wheel completes:

3 revolutions

Then:

θ = 3(2π)

θ = 6π rad

In degrees:

θ = 3(360°)

θ = 1080°

Angular displacement can therefore be greater than 360°.


Angular Displacement Greater Than One Revolution

An angular position is often represented between 0° and 360°.

Angular displacement, however, can include multiple rotations.

Suppose a wheel begins at 0° and makes:

2.5 counterclockwise revolutions

Its final orientation corresponds to 180°.

But its total angular displacement is:

2.5 × 360°

= 900°

or:

2.5 × 2π

= 5π rad

This distinction is important.


Final Orientation Is Not Always Angular Displacement

Suppose a wheel begins with a mark pointing upward.

It completes one full revolution and returns to exactly the same orientation.

Its initial and final orientations are identical.

However, if we track the rotation continuously, the wheel has rotated through:

360° = 2π rad

This illustrates an important distinction between:

  • orientation
  • angular displacement accumulated during a specified rotation

The path and sign convention must be clear when interpreting rotational motion.


Angular Displacement Versus Linear Displacement

Linear displacement describes the change in an object's position:

Δx = x_f − x_i

Angular displacement describes the change in rotational position:

Δθ = θ_f − θ_i

Linear Motion Rotational Motion
Position x Angular position θ
Displacement Δx Angular displacement Δθ
metres radians
Straight-line or spatial change Rotational change

Different Points on a Rotating Object

Consider a rigid rotating wheel.

Every point on the wheel rotates through the same angular displacement.

However, different points may travel different linear distances.

https://images.openai.com/static-rsc-4/CwOUVCnbb2WhPGqjuoyPPWbM4aMwpyRNLAeKIvN2cKNy8T9txQWIlAwESUIxd6LJvGJMyMPV6FE6AcnmbBkWLxRvUg5G_uhfnXB6e6CatF0TnVyoDRNnyjxn8rArTtAJ-qcvwnTPBR3XAnA1BrRUKb5Wlmqu9Hn3pja3k2YCu6MqWUcUni0iCxjF7mrnZLs0?purpose=fullsize
 
https://images.openai.com/static-rsc-4/QmbqgFDR9KvyE5472nsQNWznyZrTgyu-FuNki364bOXuVk8c0LJsE5iTniBNPrsp8xDShUKF1so-TzTT32I4dkyirW9_MVp4-9bAlSu66DgS2dumswrm46C1s0rWpgram-c7GKt_zDQK-pgmdm1TPNqs2hPTjAHgVGMpGwO059GWDIA2mxNHVQ_CmCXTx-dD?purpose=fullsize
 
https://images.openai.com/static-rsc-4/KgNHK_7-KxGKQ_2nRQv55fi7M8qu7cS9-HCge_CRfuYbxzaZdtZsgn37ld50a4lh0Wi7nyanEeOXcFmslqx5bgFAcsoXYeZ4Y1GSHQOX1Nve8yWRuIk9akN0_4gAUzBAe0sDT9eb-UgcycjnLmx2JQI_7zv4OvASHB2vk1KopKYab-qLYFbEPwaROdRNNBzn?purpose=fullsize
 
5

Suppose two points are located at:

Point A:

r = 0.10 m

Point B:

r = 0.30 m

Both rotate through:

θ = 2 rad

For Point A:

s = rθ

s = (0.10)(2)

s = 0.20 m

For Point B:

s = (0.30)(2)

s = 0.60 m

Both points have the same angular displacement but different linear displacements along their circular paths.


Why Outer Points Travel Farther

For the same angular displacement:

s = rθ

Therefore:

s ∝ r

A point twice as far from the axis travels twice the arc length.

A point three times as far from the axis travels three times the arc length.

This explains why the outer edge of a rotating wheel travels farther than a point near the centre during the same rotation.


Worked Example: Arc Length

A wheel has radius:

r = 0.40 m

It rotates through:

θ = 2.5 rad

Calculate the distance travelled by a point on its edge.

Use:

s = rθ

s = (0.40)(2.5)

s = 1.0 m

The point travels 1.0 m along the circular path.


Worked Example: Finding Angular Displacement

A point on the edge of a wheel travels:

s = 1.8 m

The wheel has radius:

r = 0.30 m

Use:

θ = s/r

θ = 1.8/0.30

θ = 6.0 rad

In revolutions:

number of revolutions = 6.0/(2π)

≈ 0.955 revolutions


Angular Position on a Circle

Angular position can be used like a coordinate for rotational motion.

Suppose counterclockwise is positive.

A rotating object might have:

at t = 0 s:

θ = 0 rad

at t = 1 s:

θ = 0.5 rad

at t = 2 s:

θ = 1.2 rad

at t = 3 s:

θ = 2.0 rad

The increasing angular position shows that the object is rotating counterclockwise.


Interpreting Angular Position Data

Consider:

Time (s) Angular Position (rad)
0 0
1 1
2 2
3 3
4 4

The angular position increases by:

1 rad each second

This indicates uniform rotational motion.

The object has accumulated:

4 rad

of angular displacement after 4 seconds.


Angular Position-Time Graphs

Rotational motion can be represented using a graph of:

angular position θ

against:

time t

This is similar to a linear position-time graph.

https://images.openai.com/static-rsc-4/sceV57Q965Q7MzPobu6EqcRwMPCL7UyTJQIprMrF4pB8Rx8lbyPnXXNMb0PeEvGntVxp3LRlEOFSE1YtOJZVlEHoD5kfdMbcdjrkLs8KhLLL3SSZRguExYUgjBV2LR20UCaa1-aVzIft_gCKvYoal3xm3jjZoSiABXOhcNiVbzEck0wg1nSnzJF4sFuwgNn-?purpose=fullsize
 
https://images.openai.com/static-rsc-4/iD1C2W74ToPvmVd5bTPay5CFQQ6sUddP9DnaCSDTLkSw2iPdJsLq55i7VHcxPJkNNMoPlAcKIjNEsE-WYJD8PxhdPmaWNcGNo8FpGBNY8sjj5SnTM6bxxw4_uRQWNy5lIRoL2HDcBs3lZZfW2EorSY02AhFTQBIhf39L34q3dOe1XhOjDK7C329rFlzURkI0?purpose=fullsize
 
https://images.openai.com/static-rsc-4/ds6WFatOqvLR7jNRJn9QriYQGq8gs96t2IyNnxXAz11Ahd5TJo4OzHSna91kJeRINGwo5ZKoCXFmK7uZPNKOBLAS3kE0h9vpL5GOiSdGsb7YEAsgE9h2KPDZdwAi1GZy8Bij4lorhnjTNIgY2wILgFmIjahLQ-KkLKlW4DRyLkZDgCgV6sMO-HvIBA0hQ0L8?purpose=fullsize
 
8

If θ increases steadily:

the object rotates in the positive direction.

If θ decreases:

the object rotates in the negative direction.

If θ remains constant:

the object is not rotating.

A steeper graph indicates a greater rate of change of angular position.

This leads naturally to the idea of angular velocity.


Calculating Angular Displacement from Angular Position

Suppose:

θ_i = 1.5 rad

θ_f = 5.0 rad

Then:

Δθ = θ_f − θ_i

Δθ = 5.0 − 1.5

Δθ = +3.5 rad

The positive sign indicates rotation in the positive direction.


Negative Angular Displacement

Suppose:

θ_i = 2.0 rad

θ_f = −1.0 rad

Then:

Δθ = −1.0 − 2.0

Δθ = −3.0 rad

The negative sign indicates rotation in the negative direction.


Worked Example: Degrees

A rotating platform begins at:

θ_i = 40°

and rotates counterclockwise to:

θ_f = 250°

Then:

Δθ = 250° − 40°

Δθ = +210°

Convert to radians:

Δθ = 210 × π/180

Δθ = 7π/6 rad

≈ 3.67 rad


Rotational Direction Matters

Suppose a wheel starts at 20° and finishes at 80°.

One possible angular displacement is:

+60°

if it rotates counterclockwise directly from 20° to 80°.

But the wheel could instead rotate clockwise through:

−300°

and arrive at the same orientation.

Therefore, initial and final orientations alone may not always tell us the actual angular displacement.

We may also need to know:

the direction and path of rotation.


Multiple Revolutions

Suppose a motor turns a shaft through:

12 complete revolutions counterclockwise

Then:

θ = 12(2π)

θ = 24π rad

≈ 75.4 rad

Angular displacement is not restricted to values between 0 and 2π.

This is important when studying:

  • motors
  • turbines
  • wheels
  • gears
  • engines

Angular Displacement of a Clock Hand

The hands of a clock provide a familiar example of rotational motion.

The minute hand completes:

360°

every:

60 minutes

Therefore, in 15 minutes it rotates:

15/60 × 360°

= 90°

Because a clock hand moves clockwise, using the standard sign convention:

Δθ = −90°

or:

Δθ = −π/2 rad

https://images.openai.com/static-rsc-4/Iuf6Tv4ino4OdR2tK2_ZpzlqH7FDHIPHLndLeb0TJQo8gNnnI6HyDhNSzOPUK3LMuaU3iV1BJ1313nqneB-kYAYa3RsT78PFJMmivoql7wv0qX9REjp3CzZT2IddXB1ndouuCKziHInwwShzB0xdYzSfOw0WJGap4vvh-8EAGW5sJzy5hM6eZBTlUg9-ucjo?purpose=fullsize
 
https://images.openai.com/static-rsc-4/JPBn78b1eKFUkU0c_xGzuzona_2bEk1wgevy-kV3I8xkprLT4R2EA6w33Xmqb1tT7pYDvSLtNo7KtqaJ1cLbtyM3N3IoIRE8DLVi1GF20zp0kS6O1Eb5xhe5ffZrDSFlTw4vC7WZ4pHWIq4cCoKgbKf-YDOsiZtt-cPQxsOTFeNzlsaHNb95FfJl1YHvNGiz?purpose=fullsize
 
https://images.openai.com/static-rsc-4/d3dWhB_GcbBEvvNyyQ5QYgDqSPCherMRFQd5j_VqyTshR8axlgnCjMO3SDBoJPGh0lxV0_86SJphDVZ_PA74MlIEwgmdduUnDUznua5izJodFQukfR_-QoA52kVKzbpL-Odq5zR_bAStnnMRs5sZG-8Ju7uSONdEZQn0QppGsCm1OsOsKXrJvGIGOhcgehqE?purpose=fullsize
 
7

Worked Example: Minute Hand

How far does the minute hand rotate in 20 minutes?

Fraction of revolution:

20/60 = 1/3

Therefore:

θ = 1/3(360°)

= 120°

In radians:

θ = 1/3(2π)

= 2π/3 rad

Since the rotation is clockwise:

Δθ = −2π/3 rad

if counterclockwise is defined as positive.


Wheels and Vehicles

Angular displacement can be connected to the distance travelled by a rolling wheel.

If a wheel rolls without slipping:

s = rθ

where s is the distance travelled by the vehicle.


Worked Example: Bicycle Wheel

A bicycle wheel has radius:

0.35 m

It rotates through:

20 rad

Then:

s = rθ

s = (0.35)(20)

s = 7.0 m

The bicycle travels 7.0 m if the wheel rolls without slipping.


Finding Wheel Rotation from Distance

A car wheel has radius:

0.30 m

The car travels:

60 m

Assuming no slipping:

θ = s/r

θ = 60/0.30

θ = 200 rad

Number of revolutions:

N = θ/(2π)

N = 200/(2π)

≈ 31.8 revolutions


Gears and Angular Displacement

Connected gears provide another useful application.

When two gears mesh, the edges move through the same linear distance at their point of contact.

Therefore:

r₁θ₁ = r₂θ₂

The larger gear rotates through a smaller angle while the smaller gear rotates through a larger angle.

https://images.openai.com/static-rsc-4/KjFVMH3dx-qRcdL5FofnUj897npUHlx5GcPAYddt8Mrt9vUIoXvAp2pv93dQ_UjS5HlgjcOlM8WG5COPWNVYJu36sMn2ZE_WnVbjf0RKosv4LhYES_Wdqg7FwAnuQWS885CIKy5vOzn8Ey3QpEAzQwXIDkSp9KzZLZpMc_LvzNJgLI67NTkunrvTkvMric7b?purpose=fullsize
 
https://images.openai.com/static-rsc-4/mGwWUrbEU1wlJ7HgqEtlT12QC9WT0-x3v287fgukpL3schwfrWtPwzqStgcGUN5f8i_u-C-wrzsRNu8Q7p5S48RUmuAFNui-XXdeRpd4pXsAzqzvNKfRQhzV0So7bJ8mpYFZcO7NoSVcH9f5x40jiUCfJ9FYTxpYcIAq4dZLDKXflKAib2Ls4r8di7q570fq?purpose=fullsize
 
https://images.openai.com/static-rsc-4/QmbqgFDR9KvyE5472nsQNWznyZrTgyu-FuNki364bOXuVk8c0LJsE5iTniBNPrsp8xDShUKF1so-TzTT32I4dkyirW9_MVp4-9bAlSu66DgS2dumswrm46C1s0rWpgram-c7GKt_zDQK-pgmdm1TPNqs2hPTjAHgVGMpGwO059GWDIA2mxNHVQ_CmCXTx-dD?purpose=fullsize
 
5

Worked Gear Example

Gear A has radius:

r_A = 5 cm

Gear B has radius:

r_B = 15 cm

Gear A rotates through:

θ_A = 6 rad

Using:

r_A θ_A = r_B θ_B

(5)(6) = (15)θ_B

θ_B = 2 rad

The gears rotate in opposite directions.

So if Gear A rotates:

+6 rad

then Gear B rotates:

−2 rad

using the usual sign convention.


Rotating Machinery

Angular displacement is important in:

  • electric motors
  • generators
  • turbines
  • fans
  • engines
  • robotics
  • manufacturing equipment

Sensors called rotary encoders can measure angular position.

A control system can then determine how far a shaft has rotated.


Robotics

Robotic joints often rotate rather than move in straight lines.

A robotic arm might be instructed to rotate a joint from:

θ_i = 25°

to:

θ_f = 70°

Then:

Δθ = 70° − 25°

Δθ = 45°

Precise angular positioning allows robots to control the location of their arms and tools.


Angular and Linear Motion Together

Rotational motion has quantities that correspond closely to linear motion.

Linear Motion Rotational Motion
Position x Angular position θ
Displacement Δx Angular displacement Δθ
Velocity v Angular velocity ω
Acceleration a Angular acceleration α

Understanding angular displacement is therefore the foundation for studying:

  • angular velocity
  • angular acceleration
  • rotational dynamics

Radians in Rotational Physics

Although angles can be measured in degrees, equations connecting angular and linear quantities normally require radians.

For example:

s = rθ

works directly when θ is measured in radians.

Later relationships such as:

v = rω

and:

a_t = rα

also use angular quantities measured in radians.

This is one reason radians are the standard unit in rotational physics.


A Problem-Solving Strategy

For angular displacement problems, first identify:

initial angular position θ_i

and:

final angular position θ_f

Then use:

Δθ = θ_f − θ_i

Check the sign:

  • positive → counterclockwise
  • negative → clockwise

If necessary, convert units:

180° = π rad

For circular distance problems, use:

s = rθ

with θ in radians.

For complete revolutions:

θ = 2πN

where N is the number of revolutions.


Common Mistakes

Confusing angular position with angular displacement

Angular position describes orientation. Angular displacement describes the change in angular position.

Ignoring direction

Angular displacement can be positive or negative.

Assuming clockwise is positive

The usual convention is counterclockwise positive, although a different convention can be chosen if clearly stated.

Using degrees in s = rθ

The equation requires θ in radians.

Thinking one revolution equals π radians

One complete revolution is:

2π rad

Thinking angular displacement must be less than 360°

Objects can rotate through many complete revolutions.

Confusing angular and linear displacement

Points on the same rigid rotating object have the same angular displacement but can travel different linear distances.

Forgetting the radius

Linear distance around a circle depends on both angular displacement and radius.

Assuming the final orientation tells the complete rotational history

The same final orientation can result from many different angular displacements.


Key Terms

Angular position (θ) — orientation of an object relative to a chosen angular reference.

Angular displacement (Δθ) — change in angular position.

Degree (°) — angular unit in which one complete revolution equals 360°.

Radian (rad) — SI unit of angular measurement defined using arc length and radius.

Revolution (rev) — one complete rotation, equal to 360° or 2π rad.

Reference line — chosen direction from which angular position is measured.

Positive rotation — usually counterclockwise rotation.

Negative rotation — usually clockwise rotation.

Arc length (s) — distance measured along a circular path.

Radius (r) — distance from the axis of rotation to a point on the rotating object.

Angular coordinate — angular value used to describe rotational position.

Rotational motion — motion of an object around an axis.

Rigid body — object whose points maintain fixed distances from one another during rotation.

Rotary encoder — sensor used to measure angular position or rotation.


Key Takeaways

  • Angular displacement describes the amount and direction of rotation.
  • Angular position is represented by θ.
  • Angular displacement is calculated using Δθ = θ_f − θ_i.
  • Counterclockwise rotation is usually positive.
  • Clockwise rotation is usually negative.
  • One complete revolution is 360° = 2π rad.
  • Half a revolution is 180° = π rad.
  • A quarter revolution is 90° = π/2 rad.
  • Radians are the standard angular unit used in rotational physics.
  • Degrees can be converted using radians = degrees × π/180.
  • Radians can be converted using degrees = radians × 180/π.
  • Angular displacement can be greater than 360° or 2π rad.
  • Points on the same rigid rotating object experience the same angular displacement.
  • Points farther from the axis travel greater linear distances.
  • Angular and linear displacement are connected by s = rθ.
  • The equation s = rθ requires θ in radians.
  • Rolling wheels connect rotational motion to linear travel.
  • Angular position-time data can be used to describe rotational motion.
  • The same final orientation can sometimes result from different angular displacements.
  • Angular displacement provides the foundation for understanding angular velocity and angular acceleration.

Check Your Understanding

  1. Define angular displacement and explain how it differs from angular position.
  2. State the usual sign convention for clockwise and counterclockwise rotation.
  3. Convert 120° to radians.
  4. Convert 5π/6 rad to degrees.
  5. A wheel rotates counterclockwise through 2.5 revolutions. Determine its angular displacement in degrees and radians.
  6. An object moves from angular position θ_i = 0.8 rad to θ_f = 4.2 rad. Calculate its angular displacement.
  7. A wheel begins at 150° and rotates clockwise through 220°. State its angular displacement using the usual sign convention.
  8. A point on a rotating disk is 0.25 m from the axis. The disk rotates through 4 rad. Calculate the distance travelled by the point along its circular path.
  9. Two points are located 0.10 m and 0.40 m from the centre of a rotating disk. The disk rotates through 3 rad. Compare their angular displacements and calculate the distance travelled by each point.
  10. A car wheel has radius 0.32 m and rotates through 150 rad without slipping. Calculate the distance travelled by the car.
  11. A wheel of radius 0.20 m rolls 25 m without slipping. Calculate its angular displacement in radians and the number of complete revolutions.
  12. The minute hand of a clock moves from 12:00 to 12:35. Calculate its angular displacement in degrees and radians using counterclockwise as positive.
  13. Gear A has radius 4 cm and rotates through 10 rad. It drives Gear B with radius 20 cm. Calculate the magnitude of Gear B's angular displacement and state its direction relative to Gear A.
  14. Explain why a point near the edge of a rotating wheel travels farther than a point near the centre even though both have the same angular displacement.
  15. A wheel begins with a mark at 30° and finishes with the mark at 90°. Explain why this information alone may not be enough to determine the wheel's actual angular displacement.


2. Angular Velocity

Learning outcomes
  • I can define angular velocity.
  • I can calculate average and instantaneous angular velocity.
  • I can relate angular velocity to rotational speed.
  • I can compare angular velocity and linear velocity.
  • I can solve rotational motion problems involving angular velocity.

Key Topics:
  • Motion of a point mass vs. a rigid body.
  • Examples of systems undergoing translational and rotational motion.

Angular Velocity

Angular velocity describes how quickly an object's angular position changes and the direction in which it rotates.

It is the rotational equivalent of linear velocity.

Angular velocity is represented by the Greek letter:

ω (omega)

and is commonly measured in:

radians per second (rad/s)

For example, if a wheel rotates through 6 radians in 2 seconds, its average angular velocity is:

ω_avg = 3 rad/s

https://images.openai.com/static-rsc-4/wesOS_8W_nCT0S9kOLJVHzj0Tlgjxp8nS85x9HWzsKdk7EuGsKucMLEiVdLRBaYRu1aDEKMUFkTtBwrH8a3JO-Dq8AtsoeYJv0QHaiU3nfDN65Ew26i4VW0_eS3-advLxSDd1jB78FrOH8Kz3rnk1dpUDoo0mXp2zM-_HYzpu-cUoXG73cFaW0sqC7W-OnKA?purpose=fullsize
 
https://images.openai.com/static-rsc-4/CxOQmBtBomYaQAbxR5yZ_qLTXMahxm7YStXnoXWrzv2YgK8bRd1mZB7QXgkJ5j-iNsjp7eAWEAESVniW_FQ-RQ9A6nE2VZWdffVXS2K06-zrrPeqM8w7n8vuz6M_QMSYxKEIl5lOEKwGjaTuKGZtr2vC__ai0KBPC5r88DP0mS9oXlRow8EpsG9-me5rP2kI?purpose=fullsize
 
https://images.openai.com/static-rsc-4/Sp8vC9qCRMsINZQQg0nP3t52XNefS_dthKF98nOh4UXTQ5rf_k6lOdL2rJ8S-yZgwCoFA0OeVGCdW-BTnvjqwOdrOZ9XvdXU6z8V9h4xPDl8cQ_gJZiLAJaENAf1baYR6qKNODxKc-GbZsY34EzsctPgzTNCRD-gM97VoZ0f5dziHy4MU4JE5mLOaXuNKmdo?purpose=fullsize
 
10

From Angular Displacement to Angular Velocity

Angular displacement describes a change in angular position:

Δθ = θ_f − θ_i

Angular velocity describes how rapidly that angular displacement occurs.

Average angular velocity is:

ω_avg = Δθ/Δt

where:

  • ω_avg = average angular velocity
  • Δθ = angular displacement
  • Δt = elapsed time

This closely parallels linear velocity:

v_avg = Δx/Δt


Units of Angular Velocity

The SI unit of angular velocity is:

rad/s

Other rotational speeds may be expressed using:

  • degrees per second (°/s)
  • revolutions per second (rev/s)
  • revolutions per minute (rpm)

For physics calculations, angular velocity is usually converted to:

rad/s


Direction of Angular Velocity

Angular velocity includes direction.

For simple rotation in a plane, the usual sign convention is:

counterclockwise → positive ω

clockwise → negative ω

https://images.openai.com/static-rsc-4/sw7nrXpBSIjVEZe8X9zhf_kQebcJLs_kA2wIo-y3eQmCz7x8E4vIWVuA_6t0mEjfzP0SqOjAimEJMTNx3AxJnWX5d5ejSU_ZWcgNdSP60rgy7uXh8ImUuVIEB-RQIf3kYoXMAk8dnrmGl9V6bBZLkbVoIDDUI2FGrxCtXU1D-YG9Un0JLwyx7qkEN17MxuPp?purpose=fullsize
 
https://images.openai.com/static-rsc-4/NgJdUhgmnSWZ7hY7ajI04pQ2sA57EBh9uuGo6VuC7CM1EZXsDhmF8_VqLR-CpWF9H6iqjZvC-cgG7nnh6q7XQkdJMrkTAh5Q5aownT4nsHaoKwTXb8bMrISlJoOc3wVRFJi-c9YMLKbmlJfzrblzJ43o1lvQSjMA4SDJ55CPjk8czi5o3Ukmyyhqdjo52SyT?purpose=fullsize
 
https://images.openai.com/static-rsc-4/u1IsXEUnDm1evaFjKH5-JjcK6Il5-pGO0HfeKfYob5tpq7ssMA1t-mnDM3EPkjG9p2XGc2pVkRr7QHsXTIC63y-dL1gHpk3y38jU7_erL8d0Y0xRkb1h33siWQyZEP4a4I1C84JsEkz9X6R87XatzE2e4dV5149zHrsCas_tLXFGrttcuMtFW1D0kdHtPgiT?purpose=fullsize
 
7

For example:

ω = +5 rad/s

means counterclockwise rotation at an angular speed of 5 rad/s.

ω = −5 rad/s

means clockwise rotation at the same angular speed.


Angular Velocity Versus Angular Speed

These terms are closely related but are not exactly the same.

Angular speed describes how rapidly an object rotates.

It is a magnitude and therefore has no direction.

Angular velocity includes both:

  • magnitude
  • direction

For simple one-dimensional rotation, direction is often represented by the sign.

So:

angular speed = |ω|

If:

ω = −12 rad/s

then the angular speed is:

12 rad/s

while the negative sign tells us the rotation is clockwise.


Average Angular Velocity

Average angular velocity is:

ω_avg = Δθ/Δt

Suppose a wheel rotates counterclockwise through:

Δθ = 12 rad

in:

Δt = 3 s

Then:

ω_avg = 12/3

ω_avg = +4 rad/s


Worked Example: Clockwise Rotation

A disk rotates clockwise through:

10 rad

in:

2.5 s

Using clockwise as negative:

Δθ = −10 rad

Therefore:

ω_avg = −10/2.5

ω_avg = −4.0 rad/s

The angular speed is:

4.0 rad/s

and the negative sign indicates clockwise rotation.


Average Angular Velocity from Angular Positions

Suppose:

θ_i = 2 rad

θ_f = 14 rad

Δt = 4 s

First calculate angular displacement:

Δθ = θ_f − θ_i

Δθ = 14 − 2

Δθ = 12 rad

Then:

ω_avg = 12/4

ω_avg = 3 rad/s


Instantaneous Angular Velocity

Average angular velocity describes rotation over a time interval.

But an object's rotational speed may change continuously.

Instantaneous angular velocity describes the rate of change of angular position at a particular instant.

Conceptually:

ω = dθ/dt

This is the rotational equivalent of:

v = dx/dt

for linear motion.


Average Versus Instantaneous Angular Velocity

Suppose a car wheel speeds up.

During the first 5 seconds, its average angular velocity might be:

20 rad/s

But at exactly t = 5 s, its instantaneous angular velocity might be:

35 rad/s

The average describes the entire interval.

The instantaneous value describes one particular moment.


Angular Position-Time Graphs

Angular velocity can be determined from a graph of:

angular position θ

against:

time t

The gradient of a θ-t graph represents angular velocity.

https://images.openai.com/static-rsc-4/qI0Tnwa_AKt2HiQPZQfuD_UtJ4VHKUj6pfqOTaQ1CYPCBAKHTrZ2jtF3L9UWeActpv_jScc9U21RH9yIuh01_XYNlyKgOHNsFbU63k6-SMPva1Y6LPSraRDdPKqyV3L46lmeEOogPAT4bNGDJmaBIt1qNMEEgjygAEjpBSoGO8QJLcuUsdpI_VKatoLMDwCJ?purpose=fullsize
 
https://images.openai.com/static-rsc-4/nY0yJlE5CKCC1RHWiBfCw67ryUz-n4gvEcaU_RZo8EUYBhZFuRQzAYoYUVhd_H8ppXILj8In8APCIsqg28auZhmiFsL1ilHLIy84iAtHBgMFVBxGdwIOuRYM3-TzebsFXS03tDl6a8Crt7AoGz2Rqs9BSQeKtxLnQwh8m85PQ7T9BcohDeoRmKr55dbysSoH?purpose=fullsize
 
https://images.openai.com/static-rsc-4/sceV57Q965Q7MzPobu6EqcRwMPCL7UyTJQIprMrF4pB8Rx8lbyPnXXNMb0PeEvGntVxp3LRlEOFSE1YtOJZVlEHoD5kfdMbcdjrkLs8KhLLL3SSZRguExYUgjBV2LR20UCaa1-aVzIft_gCKvYoal3xm3jjZoSiABXOhcNiVbzEck0wg1nSnzJF4sFuwgNn-?purpose=fullsize
 
7

For a straight line:

gradient = Δθ/Δt = ω

A steeper gradient means a larger angular velocity.


Positive Gradient

If θ increases with time:

ω > 0

The object rotates in the positive direction.


Negative Gradient

If θ decreases with time:

ω < 0

The object rotates in the negative direction.


Zero Gradient

If the graph is horizontal:

ω = 0

The object's angular position is not changing.

It is temporarily not rotating.


Curved Angular Position-Time Graph

If the θ-t graph is curved, the angular velocity is changing.

The instantaneous angular velocity is the:

gradient of the tangent

to the curve at the desired time.

A steeper tangent means a larger magnitude of angular velocity.


Constant Angular Velocity

If angular velocity is constant:

ω = Δθ/Δt

Rearranging:

Δθ = ωΔt

More generally:

θ_f = θ_i + ωt

This is similar to constant linear velocity:

x_f = x_i + vt


Worked Example: Constant Angular Velocity

A motor rotates at:

ω = 8 rad/s

for:

t = 6 s

Calculate its angular displacement.

Use:

Δθ = ωt

Δθ = (8)(6)

Δθ = 48 rad


Finding Final Angular Position

Suppose:

θ_i = 3 rad

ω = 5 rad/s

t = 4 s

Then:

θ_f = θ_i + ωt

θ_f = 3 + (5)(4)

θ_f = 23 rad


Revolutions and Angular Velocity

One complete revolution is:

2π rad

Therefore, if an object completes N revolutions:

Δθ = 2πN

This allows angular velocity to be calculated from the number of revolutions.


Worked Example: Revolutions

A wheel completes:

20 revolutions

in:

5 s

Angular displacement:

Δθ = 20(2π)

Δθ = 40π rad

Average angular velocity:

ω = 40π/5

ω = 8π rad/s

≈ 25.1 rad/s


Frequency

Frequency, f, describes the number of complete cycles or revolutions per second.

Its SI unit is:

hertz (Hz)

where:

1 Hz = 1 cycle/s

If a wheel rotates at 5 Hz, it completes:

5 revolutions every second

Since each revolution corresponds to 2π radians, angular velocity is related to frequency by:
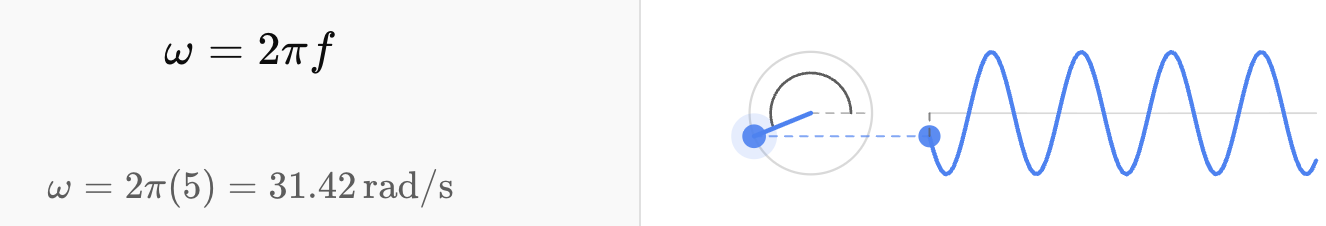
For example, at:

f = 5 Hz

the angular velocity is:

ω = 2π(5)

ω = 10π rad/s

≈ 31.4 rad/s


Period and Angular Velocity

The period, T, is the time required for one complete revolution.

Frequency and period are related by:

f = 1/T

Therefore:

ω = 2π/T

This relationship is extremely useful in circular and rotational motion.


Worked Example: Using Period

A rotating platform completes one revolution every:

T = 4 s

Then:

ω = 2π/4

ω = π/2 rad/s

≈ 1.57 rad/s


Comparing Frequency and Angular Velocity

Quantity Symbol Meaning Unit
Frequency f Revolutions per second Hz
Period T Time per revolution s
Angular velocity ω Angular change per second rad/s

They are connected by:

f = 1/T

and:

ω = 2πf = 2π/T


Revolutions Per Minute

Rotating machinery is often described using:

rpm = revolutions per minute

To convert rpm to rad/s:

  1. convert revolutions to radians
  2. convert minutes to seconds

Since:

1 rev = 2π rad

and:

1 min = 60 s

then:

ω = rpm × 2π/60


Worked Example: 120 rpm

A motor rotates at:

120 rpm

Convert to revolutions per second:

120/60 = 2 rev/s

Therefore:

f = 2 Hz

Then:

ω = 2π(2)

ω = 4π rad/s

≈ 12.6 rad/s


Worked Example: 3000 rpm

A motor rotates at:

3000 rpm

First:

f = 3000/60

f = 50 Hz

Then:

ω = 2π(50)

ω = 100π rad/s

≈ 314 rad/s

High-speed machinery can therefore have very large angular velocities.


Angular Velocity and Linear Velocity

Consider a point on the edge of a rotating wheel.

Its angular displacement is related to its arc length by:

s = rθ

Divide both sides by time:

s/t = r(θ/t)

Since:

v = s/t

and:

ω = θ/t

we obtain:

v = rω

This is one of the most important relationships in rotational motion.

https://images.openai.com/static-rsc-4/MkKMKrY6Ftk1CSV-PV43nd9rDLAUuZumCwMJ1RMP_GBj8fGuzObb_ooQMq4-3vnj1p4d0OkzTVGN7SLAH2xqLhj8TAl2Stc_a98onT7EgIntNzfQNNGVPeD7dRt8nMUFgcx6Zc3qcFtlmM7ZCcS2K1nxgC6JJh6FxkcGUFEo9RJjw0w-ESfiGSTLkDxzam9e?purpose=fullsize
 
https://images.openai.com/static-rsc-4/1pHYCciIA6OfjEJ2_hxJAChn5NJ3TXmR8Qg5J6OtmRd7Dupee6hsuR5h2V1N6N4LHhKArZ-dgMChmgjFKcZO-dBodO6v165fyd0j0PtUIFO3iDYwzGKiNoUPetr5-QSxQCEdgYC72huNP9lrtH0JeA1xGWwb45Es4RjKoDSs19Zj8k6cO_U2L0vvk_4rErDn?purpose=fullsize
 
https://images.openai.com/static-rsc-4/wesOS_8W_nCT0S9kOLJVHzj0Tlgjxp8nS85x9HWzsKdk7EuGsKucMLEiVdLRBaYRu1aDEKMUFkTtBwrH8a3JO-Dq8AtsoeYJv0QHaiU3nfDN65Ew26i4VW0_eS3-advLxSDd1jB78FrOH8Kz3rnk1dpUDoo0mXp2zM-_HYzpu-cUoXG73cFaW0sqC7W-OnKA?purpose=fullsize
 
7

Tangential Velocity

The linear velocity of a point moving around a circular path is often called its tangential velocity.

Its magnitude is:

v = rω

The direction of the velocity is:

tangent to the circular path

at that instant.

Angular velocity describes the rotation of the entire rigid object.

Tangential velocity describes the linear motion of a particular point on that object.


Same Angular Velocity, Different Linear Speeds

Every point on a rigid rotating disk has the same angular velocity.

However:

v = rω

so points farther from the axis have greater linear speeds.

Suppose a disk rotates at:

ω = 6 rad/s

Point A is:

r_A = 0.10 m

from the centre.

Point B is:

r_B = 0.40 m

Then:

v_A = (0.10)(6)

v_A = 0.60 m/s

and:

v_B = (0.40)(6)

v_B = 2.4 m/s

Both points rotate at 6 rad/s, but Point B moves four times faster linearly.


Why the Outer Edge Moves Faster

During the same time interval, all points rotate through the same angle.

However, an outer point travels along a larger circle.

Therefore, it must cover a greater distance in the same time.

This means:

greater radius → greater tangential speed

when angular velocity is the same.


Angular Velocity Versus Linear Velocity

Angular Velocity Linear Velocity
Symbol ω Symbol v
Describes rotational motion Describes linear motion
rad/s m/s
Same for all points on a rigid rotating body Depends on distance from axis
Direction associated with axis/sign of rotation Tangent to circular path
ω = Δθ/Δt v = Δs/Δt
— v = rω

Worked Example: Rotating Wheel

A wheel has radius:

0.50 m

and rotates at:

ω = 12 rad/s

Find the tangential speed at its edge.

Use:

v = rω

v = (0.50)(12)

v = 6.0 m/s


Worked Example: Finding Angular Velocity

A point on the edge of a rotating disk moves at:

v = 8.0 m/s

The disk has radius:

r = 0.40 m

Use:

ω = v/r

ω = 8.0/0.40

ω = 20 rad/s


Rolling Wheels

For a wheel rolling without slipping:

v = rω

where v is also the linear speed of the wheel's centre relative to the ground.

https://images.openai.com/static-rsc-4/wesOS_8W_nCT0S9kOLJVHzj0Tlgjxp8nS85x9HWzsKdk7EuGsKucMLEiVdLRBaYRu1aDEKMUFkTtBwrH8a3JO-Dq8AtsoeYJv0QHaiU3nfDN65Ew26i4VW0_eS3-advLxSDd1jB78FrOH8Kz3rnk1dpUDoo0mXp2zM-_HYzpu-cUoXG73cFaW0sqC7W-OnKA?purpose=fullsize
 
https://images.openai.com/static-rsc-4/cR_-cPQQks4rAGqbiyKT-p7LA4EpZigVQWmzAzqDeKchRWhpktznBOYEDkc2ckML6ToAOigec8_qLRLtaYv8FqYbErU6YzyRC938onvO7zAii-fAwoytlA6LgQyQDDf1CTwjIWIEJRSYy_cZzAcXt7p_yp7ZEf-KBoEqhs7gsrZjIJZoSE0it_BP1i7CHUiG?purpose=fullsize
 
https://images.openai.com/static-rsc-4/BD9nnSxZFoJn25L6eR44kwf1EN0gJWjQ-6qErnOGPGjogTppbDpCK2PVXnm246kPVaVW2S8JRBF9EId_2EYO4tkpSFdsy0hJ30uTs-weC_uFcrdO5Z_XyfQIOYM6AFsfIKxzEDapSe5WWsH1ooLRIm5SQa_MYlHTc8VNeW5S4MjHKYskCv54ubEnRAJztfM0?purpose=fullsize
 
8

This connects the rotation of a wheel with the forward motion of a vehicle.


Worked Example: Bicycle Wheel

A bicycle wheel has radius:

0.35 m

and angular velocity:

ω = 15 rad/s

Then:

v = rω

v = (0.35)(15)

v = 5.25 m/s

Convert to km/h:

5.25 × 3.6

= 18.9 km/h


Car Wheel Example

A car travels at:

27 m/s

Its wheel radius is:

0.30 m

Assuming no slipping:

ω = v/r

ω = 27/0.30

ω = 90 rad/s

Its frequency is:

f = ω/(2π)

f ≈ 14.3 Hz

Therefore, each wheel completes about:

14.3 revolutions per second

or:

14.3 × 60 ≈ 860 rpm


Angular Velocity of a Clock Hand

The minute hand completes one clockwise revolution every:

3600 s

Therefore:

ω = −2π/3600

ω ≈ −1.75 × 10⁻³ rad/s

The negative sign represents clockwise rotation.

https://images.openai.com/static-rsc-4/unqvgGxUoQeVPXX5tw9aKlYijNB-jOIrX_nwRMB6JSRGwDAUUSUIaoj3hXWtpilXtLHVOJ4jW1mtZ9i3UJ13Ogb_TPDldQ88g4fLo6n7p6WubQ8nz9RahILxX57nmRNc084KUxeXeN6cbaxfJxUBN8NRwWZ_SO8urROqJyW5NMOXYPyDd2bH_y3Kj_1EqvXi?purpose=fullsize
 
https://images.openai.com/static-rsc-4/ihGfuipuP7EzfT-PriQaS2V8XsP-PQuEGs3deT5GZ4e4otBiFgdlRgQvOFIM7KlGyXPl2nYvlQuU7wYExWYcDLADi4EzGtV6zCnuEZmOvLjnHFt2qMbx_VQMbYc5suXLt152tvbdBkdEY6dO0CEjF7LTEPbnRrT_ekWeQmSOO8pxgK6UtzNW2EiHiz_S8ubR?purpose=fullsize
 
https://images.openai.com/static-rsc-4/NSpcTNVdIzgWGuGsVQX9bfRK7g_g8GriQScsyutCzi9U1omDOPrmTNX4iL9RQmc3gTiya5Bau9Tl0BDjpg7BcUfPk6luq-GgOYVRFjdud3RFL_kYQTTdztupCICOCqDWx2KQkiw9goqh6FBTIyfMIvLxxHAFCUQNgQ9qeso2e6kbLL5B1F_W_kHLJWv3xrmn?purpose=fullsize
 
6

Hour Hand Angular Velocity

The hour hand completes one revolution every:

12 hours

Convert:

12 h = 43,200 s

Therefore:

ω = −2π/43,200

ω ≈ −1.45 × 10⁻⁴ rad/s

The minute hand therefore has a much greater angular speed than the hour hand.


Angular Velocity in Gears

When two gears mesh without slipping, their edges have the same tangential speed:

v₁ = v₂

Since:

v = rω

then:

r₁ω₁ = r₂ω₂

Therefore:

ω₂/ω₁ = r₁/r₂

A smaller gear rotates faster than a larger gear.

https://images.openai.com/static-rsc-4/Hx7cgpLwZ2c3p_A4R4eFcEkruv02o-GcUwa-eddJjHaAGR2oVcOrZdr1J7piHrGNTQNHAyCiKhXcnWy74YzY47qtdsYiE-o_GLcYOUfl5zqwfIxD10a9muqSuYrz_QsZdNvls1vHOSvUBPC5UiKh4OZH7jZeV6xltNUaX-jZIgEOIPJr2pjQJKgYMMe1dQ_n?purpose=fullsize
 
https://images.openai.com/static-rsc-4/EDSoKsHOXOV57cz9boI73WELGZoc5tp50EV5A_50aaOsnxihNzjQKD6FCsnM99AcBTYZtWbpilCG8X0GxUkbNiVgsltTjGhXZetwe3CkEm4Shf18spuwNOXLxaacI_WEX6ld9M9Cxj3EfbnB_v9UO855r0IYYvZZZl-HeLrFANSkv6E-x5H6QbYKHLQLuNM1?purpose=fullsize
 
https://images.openai.com/static-rsc-4/_CTVNmpKTBubRzVnMzabFaUSDlqpor8aRsQUk8FZIu3cRUikDBapmMp1vvHQMd9BzsVMFjlW90tdtUucJmnwgZed17sk59EhYJkO6UdTO7pivLoZEDCg4M-WLezj_C_fG_5G9VetAwm0kmR9hr3Xw69sunm63rSAExHzyd2d13gc-tHlBh_EE7nwoDdhtntx?purpose=fullsize
 
6

Worked Gear Example

Gear A has radius:

r_A = 4 cm

and rotates at:

ω_A = 30 rad/s

Gear B has radius:

r_B = 12 cm

Then:

r_A ω_A = r_B ω_B

(4)(30) = (12)ω_B

ω_B = 10 rad/s

Because meshing gears rotate in opposite directions, if:

ω_A = +30 rad/s

then:

ω_B = −10 rad/s


Angular Velocity in Rotating Machinery

Angular velocity is important in:

  • motors
  • turbines
  • generators
  • fans
  • drills
  • engines
  • washing machines
  • hard drives
  • industrial machinery

Machines often have specified rotational speeds in rpm.

Engineers convert these values into rad/s when performing calculations involving rotational motion.


Angular Velocity in Astronomy

Angular velocity also appears in astronomy.

Earth rotates once approximately every 24 hours.

Its average angular velocity is approximately:

ω = 2π/(24 × 3600)

ω ≈ 7.27 × 10⁻⁵ rad/s

This angular velocity affects:

  • day and night
  • apparent motion of stars
  • launch trajectories
  • motion of points on Earth's surface

Different Linear Speeds on Earth

All locations on Earth share approximately the same angular velocity due to Earth's rotation.

But their linear speeds are different.

A point near the equator travels around a much larger circular path than a point near the poles.

Therefore:

equatorial regions have greater linear rotational speed

while:

near the poles, linear rotational speed is much smaller.

This is another example of:

v = rω


Angular Velocity as a Vector

In more advanced physics, angular velocity is treated as a vector.

Its direction lies along the axis of rotation, rather than tangent to the circular path.

The direction is determined using the:

right-hand rule.

https://images.openai.com/static-rsc-4/kkjB0gn7LYfECDvHVk2Vbl_8wudtBJ3YRxwafR7EQDjmoIC3ThNG2VrD7JOrgbuD9RGxh3nqdIXF0HcLWY_wA3xt7aObR2OHbOYjNagSqgyPp8eLwQIhpXidwiPySsMFoz4cEoEodaA0ast_ChkMNsc2VTjjgg08sTy9ILI8Lx0UUWWv4f5GSrTP0HU1b8Ns?purpose=fullsize
 
https://images.openai.com/static-rsc-4/xVjgXdQs2c_qkfd0WCQXfNIXdRwVP69DPNBkP_6wZ6gu9YdIp0b8uHoSS4pV36fFo6Rk6jMZlBhgvlq136sX7LUry-dS5_2V0ElGEs6pXJ3KXmQ7zcU2LBzHwKzf2t5ceG8XKiqEcvRiCNEMJ8ojig-t1TblG5JYU3JuYusbEtlY6hhIhA79r-8l8zc3JlNk?purpose=fullsize
 
https://images.openai.com/static-rsc-4/1FlZoS0PoKYZPZc8XW6tgOPlCxDjhlumF3OVeKgVOM160p-P4kGU2t3AKGkyiOhi6RNl7agxyDUMD98CTFey3sJwVJT1HCn-8TxKC3bxhy9EU1obHKBUXPGs9vQzp9jh7JnxZa02hnRuaWdTgrBRNk7sani7Tw1IUxlJISBJW6J5wkiJqyGFgSAc-yS-VoZR?purpose=fullsize
 
7

Curl the fingers of your right hand in the direction of rotation.

Your thumb points in the direction of the angular velocity vector.

For counterclockwise rotation viewed from above, the angular velocity vector points upward from the plane.

For clockwise rotation, it points in the opposite direction.

For many introductory problems, using positive and negative signs is sufficient.


Instantaneous Angular Velocity from Data

Suppose angular position data are:

Time (s) θ (rad)
0 0
1 2
2 6
3 12
4 20

Average angular velocity from t = 2 s to t = 4 s is:

ω_avg = (20 − 6)/(4 − 2)

ω_avg = 14/2

ω_avg = 7 rad/s

The increasing changes in θ also show that the object is rotating faster as time passes.


Estimating Instantaneous Angular Velocity

Suppose we want the angular velocity at approximately:

t = 2 s

and have nearby data:

θ(1.9 s) = 5.61 rad

θ(2.1 s) = 6.41 rad

Approximate the instantaneous angular velocity using the small interval:

ω ≈ Δθ/Δt

ω ≈ (6.41 − 5.61)/(2.1 − 1.9)

ω ≈ 0.80/0.20

ω ≈ 4.0 rad/s

Using data close to the desired instant gives an estimate of instantaneous angular velocity.


Reversing Direction

Angular velocity can change sign.

Suppose:

  • initially ω = +5 rad/s
  • later ω = 0
  • finally ω = −3 rad/s

The object:

  1. initially rotates counterclockwise
  2. slows to a stop
  3. reverses direction
  4. rotates clockwise

Therefore, the sign of angular velocity contains important information about rotational direction.


Angular Velocity and Centripetal Acceleration

For circular motion:

a_c = v²/r

Since:

v = rω

substitute:

a_c = (rω)²/r

Therefore:

a_c = rω²

This connects angular velocity to centripetal acceleration.


Worked Example: Centripetal Acceleration

A point is:

0.50 m

from the centre of a rotating disk.

The disk rotates at:

ω = 8 rad/s

Then:

a_c = rω²

a_c = (0.50)(8²)

a_c = (0.50)(64)

a_c = 32 m/s²

Even constant angular velocity produces centripetal acceleration because the direction of linear velocity continually changes.


Constant Angular Velocity Does Not Mean Zero Acceleration

This is an important distinction.

If:

ω = constant

then angular velocity is not changing.

However, a point on the rotating object is continuously changing the direction of its linear velocity.

Therefore, it has centripetal acceleration toward the centre.

So:

constant angular velocity ≠ zero linear acceleration

for a point undergoing circular motion.


A Rotational Motion Comparison

Many linear-motion ideas have rotational equivalents:

Linear Quantity Rotational Quantity
Position x Angular position θ
Displacement Δx Angular displacement Δθ
Velocity v Angular velocity ω
Acceleration a Angular acceleration α
v = Δx/Δt ω = Δθ/Δt
x = x₀ + vt θ = θ₀ + ωt

These parallels make rotational motion easier to analyze once linear kinematics is understood.


Problem-Solving Strategy

When solving an angular velocity problem:

Identify the known quantities

Look for:

  • θ
  • Δθ
  • time
  • number of revolutions
  • frequency
  • period
  • radius
  • linear speed
  • rpm

Convert units if necessary

Remember:

1 rev = 2π rad

1 min = 60 s

180° = π rad

Choose the relationship

Average angular velocity:

ω_avg = Δθ/Δt

Constant angular velocity:

Δθ = ωt

Frequency:

ω = 2πf

Period:

ω = 2π/T

Linear speed:

v = rω

Then check whether the sign and units make sense.


Common Mistakes

Confusing angular velocity with linear velocity

Angular velocity is measured in rad/s; linear velocity is measured in m/s.

Forgetting direction

Angular velocity can be positive or negative.

Using degrees directly when rad/s is required

Convert degrees to radians before using standard rotational equations.

Forgetting that one revolution is 2π rad

It is not π rad.

Using rpm as though it were rad/s

rpm must be converted.

Thinking all points on a rotating disk have the same linear speed

They have the same angular velocity, but linear speed increases with radius.

Thinking a point at the centre has a large linear speed

At r = 0:

v = rω = 0

even though the disk has nonzero angular velocity.

Thinking constant angular velocity means no acceleration

Points moving in circles still have centripetal acceleration.

Ignoring the sign when rotation reverses

A change from positive to negative ω indicates a reversal of rotational direction.


Key Terms

Angular velocity (ω) — rate of change of angular position with time.

Average angular velocity — angular displacement divided by elapsed time.

Instantaneous angular velocity — rate of change of angular position at a particular instant.

Angular speed — magnitude of angular velocity.

Radian per second (rad/s) — SI unit of angular velocity.

Frequency (f) — number of complete revolutions or cycles per second.

Hertz (Hz) — unit of frequency equal to one cycle per second.

Period (T) — time required for one complete revolution.

Revolution per minute (rpm) — common unit of rotational speed.

Tangential velocity — instantaneous linear velocity tangent to a circular path.

Rigid body — object whose points remain fixed relative to one another.

Centripetal acceleration — inward acceleration required for circular motion.

Right-hand rule — method used to determine the vector direction of angular velocity.

Axis of rotation — line around which an object rotates.


Key Takeaways

  • Angular velocity describes how rapidly angular position changes.
  • Angular velocity is represented by ω.
  • The SI unit of angular velocity is rad/s.
  • Average angular velocity is ω_avg = Δθ/Δt.
  • Instantaneous angular velocity is the rate of change of θ at a particular instant.
  • The gradient of an angular position-time graph represents angular velocity.
  • Counterclockwise rotation is usually positive.
  • Clockwise rotation is usually negative.
  • Angular speed is the magnitude of angular velocity.
  • One complete revolution equals 2π rad.
  • Frequency and angular velocity are related by ω = 2πf.
  • Period and angular velocity are related by ω = 2π/T.
  • rpm can be converted to rad/s using ω = rpm × 2π/60.
  • Angular and linear velocity are connected by v = rω.
  • All points on a rigid rotating object have the same angular velocity.
  • Points farther from the axis have greater tangential speeds.
  • Rolling without slipping connects wheel rotation to vehicle speed through v = rω.
  • Meshing gears have equal tangential speeds at their contact point but different angular velocities if their radii differ.
  • Angular velocity can change sign when an object reverses rotational direction.
  • A point moving with constant angular velocity can still have centripetal acceleration.
  • Centripetal acceleration can be written as a_c = rω².

Check Your Understanding

  1. Define angular velocity and state its SI unit.
  2. Explain the difference between angular speed and angular velocity.
  3. A wheel rotates through 24 rad in 6 s. Calculate its average angular velocity.
  4. A disk rotates clockwise through 15 rad in 3 s. Calculate its average angular velocity using the usual sign convention.
  5. A motor rotates at a constant angular velocity of 8 rad/s for 12 s. Calculate its angular displacement.
  6. A wheel completes 30 revolutions in 5 s. Calculate its frequency and angular velocity.
  7. Convert 600 rpm to rad/s.
  8. A rotating platform has a period of 2.5 s. Calculate its angular velocity.
  9. A disk rotates at 10 rad/s. Calculate the tangential speed of a point 0.40 m from its centre.
  10. Two points are located 0.20 m and 0.80 m from the centre of a rigid disk rotating at 5 rad/s. Compare their angular velocities and calculate their tangential speeds.
  11. A bicycle travels at 7.0 m/s. Its wheels have radius 0.35 m. Assuming no slipping, calculate the angular velocity of the wheels.
  12. Gear A has radius 5 cm and rotates at 24 rad/s. It drives Gear B of radius 15 cm. Calculate Gear B's angular velocity, including its direction relative to Gear A.
  13. An angular position-time graph has a gradient of −6 rad/s. Explain what this tells you about the object's rotational motion.
  14. A point 0.25 m from the centre of a disk rotates at 12 rad/s. Calculate its tangential speed and centripetal acceleration.
  15. A student says, "Every point on a spinning wheel has the same velocity because the whole wheel has the same angular velocity." Evaluate this statement, clearly distinguishing between angular velocity and linear velocity.


3. Angular Acceleration

Learning outcomes
  • I can define angular acceleration.
  • I can calculate angular acceleration from changes in angular velocity.
  • I can interpret positive and negative angular acceleration.
  • I can analyze rotational motion graphs.
  • I can solve problems involving angular acceleration.

Key Topics:
  • Definition of center of mass.
  • Calculating the center of mass for simple systems.

Angular Acceleration

Angular acceleration describes how quickly an object's angular velocity changes.

It is the rotational equivalent of linear acceleration.

Angular acceleration is represented by the Greek letter:

α (alpha)

and its SI unit is:

radians per second squared (rad/s²)

An object has angular acceleration whenever its angular velocity changes in:

  • magnitude
  • direction
  • or both
https://images.openai.com/static-rsc-4/0n5N6fkIcMODklFDBUdn0YUYoq-ZN29ODkIp2EaT3OVDWO9ELXcrxFPzgV3QGVcd6rxX6xb4M4LWhavmLvl-e1d0QZvUryhmTCxGNi9qGIvV9pyvra0ptecbVqPN17hve_08PaGQPGS3kSVwSVWIgZOcBUZeLbUXs3UDoF4GmX3Fx7qZUY3WHhv1iezcCTnE?purpose=fullsize
 
https://images.openai.com/static-rsc-4/UG7XH8-pe6raMwFQNSydv9ONMcYVJucHvzrVWafpjRJGLKMorYcwG3k1TQ1JXJIxEKp6fb7ub7AdlvDdFXb0XRKiIPS8ZvN00tX4QSiYe_23EcgkEpVLw8Jg5TeG-zsTT1e0So_fohv57-Z0WbWA2TZYC1GLMTV2yv2DvG6dCRMLx61FGYnVWu6glqU5XWrX?purpose=fullsize
 
https://images.openai.com/static-rsc-4/bLTub5nGdZxg4yTZWLRAr2yaEoTd4Akh3AYLKhhzjSCxhm7yeQ7c8R45gnU3I_EAjz3eM6iNOYmZYnrQv5yBGSioJaSMboh_p85rChFBcP5QfNd1nqjow3tvdFE9sVs7dJXamlDODzAECNMyhLcbKjoxnH_OKNcXk_8t4y40z6qfJ3wDRSp2I8WUbKnxoTTd?purpose=fullsize
 
8

From Angular Velocity to Angular Acceleration

Angular velocity describes the rate of change of angular position:

ω = Δθ/Δt

Angular acceleration describes the rate of change of angular velocity.

Average angular acceleration is:

α_avg = Δω/Δt

or:

α_avg = (ω_f − ω_i)/Δt

where:

  • α_avg = average angular acceleration
  • ω_i = initial angular velocity
  • ω_f = final angular velocity
  • Δt = elapsed time

This closely parallels linear acceleration:

a = (v_f − v_i)/Δt


Units of Angular Acceleration

Angular velocity is measured in:

rad/s

If angular velocity changes each second, angular acceleration is measured in:

rad/s²

For example:

α = 4 rad/s²

means that the angular velocity changes by:

4 rad/s every second

when the angular acceleration is constant.


Example: Understanding the Unit

Suppose a wheel starts from rest and has constant angular acceleration:

α = 3 rad/s²

Its angular velocity changes as follows:

Time (s) Angular Velocity (rad/s)
0 0
1 3
2 6
3 9
4 12

Every second, angular velocity increases by:

3 rad/s

Therefore:

α = 3 rad/s²


Average Angular Acceleration

Suppose a motor's angular velocity increases from:

ω_i = 5 rad/s

to:

ω_f = 25 rad/s

in:

Δt = 4 s

Then:

α = (ω_f − ω_i)/Δt

α = (25 − 5)/4

α = 20/4

α = 5 rad/s²

The motor's angular velocity increases by 5 rad/s every second.


Worked Example: Slowing Rotation

A fan initially rotates at:

ω_i = 30 rad/s

After 5 seconds:

ω_f = 10 rad/s

Calculate its average angular acceleration.

α = (10 − 30)/5

α = −20/5

α = −4 rad/s²

The negative sign tells us the angular velocity is changing in the negative direction.

If the fan was rotating counterclockwise, this means it was slowing down.


Instantaneous Angular Acceleration

Angular acceleration does not have to remain constant.

Instantaneous angular acceleration describes the rate at which angular velocity changes at one particular instant.

Conceptually:

α = dω/dt

Since:

ω = dθ/dt

angular acceleration can also be written conceptually as:

α = d²θ/dt²

This means angular acceleration describes how the rate of rotation itself is changing.


Positive and Negative Angular Acceleration

The sign of angular acceleration depends on the chosen rotational direction.

Using the usual convention:

counterclockwise = positive

clockwise = negative

Therefore:

α > 0

means angular velocity is changing in the positive direction.

α < 0

means angular velocity is changing in the negative direction.

However, the sign of angular acceleration alone does not tell us whether the object is speeding up or slowing down.

We must compare the signs of:

ω and α

https://images.openai.com/static-rsc-4/fY3VrtZaJLkp6piESndHgJbgZNHa4LhFXk86i5zYFY-jXGlaXinNVKhLfRyssxbSAbFzxQNAdodIPnDBlRfiYLnQ13-dvYi482GHc1u7SbTl-mErwuQ9s9Dzpd1LiSSaDyUp8USRj_JmCWnbEFTqi93q3p422fiebbyMW4MhQN2HnHfnTN6yUYDVPnV_y9Mj?purpose=fullsize
 
https://images.openai.com/static-rsc-4/oXZ6C7x1YnZdIXlIiyArOjKS1mTWQra_9f-IoS6X8gxdTw96Im4nQ4tNRh8DCQ56fdNz5Rq6RmP3QSl1KgrUWKmpZcACHwZZZc79B2Qqekipp5iRfjwRoZegDJ-2Opcbrcx_3qvN7rIxoEVD9rZals1JXKwuvvVcT8FMPWO30KdnxlG_KFUbrnfOUX1HImDY?purpose=fullsize
 
https://images.openai.com/static-rsc-4/M_qk_UpaMkUsE7GnAgas6BnSDq7vGvtRqO0FPUwwsZZ2b3GFzzSBc6GjoA2UTeW6lYsRUzDhKbNE0Bofep64OLvCqm4C9nCbMJ1YGNaSjs0scx6e1gMClH9UaNTSEt3XMC8Gf7J5iZFd4Xk9TEzofL2wlkDvrI6UVfckMeL5k8xDjSKtgPEcMgly5bs4vFqy?purpose=fullsize
 
7

When Does an Object Speed Up?

An object speeds up rotationally when angular velocity and angular acceleration have the same sign.

Positive ω and Positive α

Example:

ω = +5 rad/s

α = +2 rad/s²

The object is rotating counterclockwise and speeding up.

Negative ω and Negative α

Example:

ω = −5 rad/s

α = −2 rad/s²

The object is rotating clockwise and speeding up.


When Does an Object Slow Down?

An object slows down when angular velocity and angular acceleration have opposite signs.

Positive ω and Negative α

Example:

ω = +10 rad/s

α = −3 rad/s²

The object rotates counterclockwise but slows down.

Negative ω and Positive α

Example:

ω = −10 rad/s

α = +3 rad/s²

The object rotates clockwise but slows down.


Sign Summary

Angular Velocity Angular Acceleration Motion
+ + Counterclockwise, speeding up
+ − Counterclockwise, slowing down
− − Clockwise, speeding up
− + Clockwise, slowing down

The key rule is:

same signs → speeding up

opposite signs → slowing down


Negative Acceleration Does Not Always Mean Slowing Down

This is one of the most important ideas in rotational motion.

Suppose:

ω = −8 rad/s

and:

α = −2 rad/s²

The angular velocity becomes increasingly negative:

−8 → −10 → −12 → −14 rad/s

The magnitude of angular velocity is increasing.

Therefore, the object is:

speeding up clockwise

even though its angular acceleration is negative.


Constant Angular Acceleration

If angular acceleration is constant:

α = (ω_f − ω_i)/t

Rearranging gives:

ω_f = ω_i + αt

This is the rotational equivalent of:

v_f = v_i + at


Worked Example: Speeding Up

A wheel has:

ω_i = 4 rad/s

α = 3 rad/s²

t = 6 s

Use:

ω_f = ω_i + αt

ω_f = 4 + (3)(6)

ω_f = 22 rad/s

Therefore:

ω_f = 22 rad/s


Worked Example: Slowing to Rest

A rotating disk has:

ω_i = 24 rad/s

α = −6 rad/s²

Find how long it takes to stop.

At rest:

ω_f = 0

Use:

ω_f = ω_i + αt

0 = 24 − 6t

6t = 24

t = 4 s

The disk takes 4 seconds to stop.


Direction Reversal

Angular acceleration can cause an object to stop and then reverse its rotational direction.

Suppose:

ω_i = +12 rad/s

α = −4 rad/s²

After 3 seconds:

ω = 12 + (−4)(3)

ω = 0

After 5 seconds:

ω = 12 + (−4)(5)

ω = −8 rad/s

Therefore, the object:

  • initially rotates counterclockwise
  • slows down
  • stops at t = 3 s
  • begins rotating clockwise
  • reaches −8 rad/s at t = 5 s
https://images.openai.com/static-rsc-4/fY3VrtZaJLkp6piESndHgJbgZNHa4LhFXk86i5zYFY-jXGlaXinNVKhLfRyssxbSAbFzxQNAdodIPnDBlRfiYLnQ13-dvYi482GHc1u7SbTl-mErwuQ9s9Dzpd1LiSSaDyUp8USRj_JmCWnbEFTqi93q3p422fiebbyMW4MhQN2HnHfnTN6yUYDVPnV_y9Mj?purpose=fullsize
 
https://images.openai.com/static-rsc-4/oXZ6C7x1YnZdIXlIiyArOjKS1mTWQra_9f-IoS6X8gxdTw96Im4nQ4tNRh8DCQ56fdNz5Rq6RmP3QSl1KgrUWKmpZcACHwZZZc79B2Qqekipp5iRfjwRoZegDJ-2Opcbrcx_3qvN7rIxoEVD9rZals1JXKwuvvVcT8FMPWO30KdnxlG_KFUbrnfOUX1HImDY?purpose=fullsize
 
https://images.openai.com/static-rsc-4/Tcw5Hnv0TmlFHGCGH5DS7uf2aDzCWY0dsUNfiiRmeritq4POcDqoPrlB6uW7VVSIx07l8fWKr12d51EcajSmRWEIg44a5b0RmvPcRtPKlUS1pqBo88SBdaoedvDec44WO7gA1CRvEoMoyXYDmPa2OJpawAnBT6sbGNslDDBUY1lN-OIkZvCBWld6pcj96uSl?purpose=fullsize
 
4

Angular Velocity-Time Graphs

An angular velocity-time graph is one of the most useful ways to analyze rotational motion.

The vertical axis represents:

ω

and the horizontal axis represents:

t

The gradient of the graph gives angular acceleration:

gradient = Δω/Δt = α

https://images.openai.com/static-rsc-4/fHLlmSotPmjgn1vuPucE22BlFSOigsMMgkzCIAmESeZSP7-BEeGMHfbgpXR45tokNqi85nHrT8JbVTog0em8G4cwtlA3bKrQMAXFrT_9b82CruXrnMZqqiQJ-o4g0LRJYOIlpYJJw-3OP6sfXShNTjDTvuO2PKHPu0rMfpHwG_gACj3X7lt5oGZyQvpRnmD2?purpose=fullsize
 
https://images.openai.com/static-rsc-4/IraHHfFFSQP-HHuHpe14P_AND8MrmZwmptfVlUIaZfEU2M9fpFlZZegwF9b1xHkGQpQqJtXDdHKo53y-DFSzTUT1RhTZnN6G8_R4-6hdFavgBAOazB8DUCtInnWWlzEaFWKvW7IkJjnkK8ZHIlQy-DBgf8wnyas6xFKQqIQ714r2tIZXvHZli1PfKR2ts5wD?purpose=fullsize
 
https://images.openai.com/static-rsc-4/BrWjjZH0Qi_zMnw5rIdA_dStI0MhdfaD56DyFPuspKC_DO-K0Z4VpraJ5O1jwdYzSeMWTBkU4iKsRmc1enL0Cst6BsFd3xsbBbu4djOrgFZb-Yi73ZzQUHUfnMiU4uVC3IT5K2xWYBgCao7I-FBVPo9d907MGwrCPs18P5KuVVNOuKKb8a87O5P6NWxcIZD1?purpose=fullsize
 
7

Positive Gradient

If the ω-t graph slopes upward:

α > 0

Angular velocity is becoming more positive.

This could mean:

  • positive rotation speeding up
  • negative rotation slowing down

depending on the value of ω.


Negative Gradient

If the ω-t graph slopes downward:

α < 0

Angular velocity is becoming more negative.

This could mean:

  • positive rotation slowing down
  • negative rotation speeding up

Horizontal Line

If the ω-t graph is horizontal:

α = 0

Angular velocity is constant.

The object may still be rotating rapidly.

Zero angular acceleration does not mean zero angular velocity.


Worked Graph Example

Suppose an ω-t graph changes from:

ω = 4 rad/s at t = 1 s

to:

ω = 16 rad/s at t = 5 s

Then:

α = Δω/Δt

α = (16 − 4)/(5 − 1)

α = 12/4

α = 3 rad/s²


Area Under an Angular Velocity-Time Graph

The area under an angular velocity-time graph represents:

angular displacement

because:

Δθ = ωΔt

for constant angular velocity.

More generally:

Δθ = area under the ω-t graph

This is the rotational equivalent of finding linear displacement from the area under a velocity-time graph.


Rectangular Area Example

Suppose:

ω = 6 rad/s

for:

5 s

The area under the graph is:

Δθ = (6)(5)

Δθ = 30 rad


Triangular Area Example

Suppose a wheel starts from rest and its angular velocity increases uniformly from:

0 rad/s

to:

20 rad/s

during:

4 s

The ω-t graph forms a triangle.

Area:

Δθ = 1/2 × base × height

Δθ = 1/2(4)(20)

Δθ = 40 rad


Trapezoidal Area Example

Suppose angular velocity increases uniformly from:

ω_i = 6 rad/s

to:

ω_f = 14 rad/s

over:

4 s

The area under the graph is a trapezoid:

Δθ = [(ω_i + ω_f)/2]t

Δθ = (6 + 14)/2

Δθ = (10)(4)

Δθ = 40 rad


Angular Acceleration-Time Graphs

An angular acceleration-time graph shows how α changes with time.

The area under an α-t graph represents:

change in angular velocity

because:

Δω = αΔt

for constant angular acceleration.

More generally:

Δω = area under the α-t graph

https://images.openai.com/static-rsc-4/yYDvlNOdGFERy-XD_taQPELGq4LGCTk1nl-oACXnlxQ4EUEbr965EbHYlX9Rxz3ILMHgogATE5quPQuS5vWqvgC8W8OMGSvW9nB3BASf0aBc4G_rzIRvnrDeo0vtY6QYKxEX80kcfJ9-YrBaPUUojMAOzw1fNNAE_zjjTDxmBUp5znToNptOwCkOVz9mJEzn?purpose=fullsize
 

Example: Area Under an α-t Graph

Suppose:

α = 4 rad/s²

for:

3 s

Then:

Δω = αt

Δω = (4)(3)

Δω = 12 rad/s

If:

ω_i = 5 rad/s

then:

ω_f = 5 + 12

ω_f = 17 rad/s


Angular Position-Time Graphs

Angular acceleration can also be interpreted using an angular position-time graph.

Remember:

gradient of θ-t graph = ω

Therefore, if the gradient changes, angular velocity changes.

That means:

α ≠ 0

https://images.openai.com/static-rsc-4/iD1C2W74ToPvmVd5bTPay5CFQQ6sUddP9DnaCSDTLkSw2iPdJsLq55i7VHcxPJkNNMoPlAcKIjNEsE-WYJD8PxhdPmaWNcGNo8FpGBNY8sjj5SnTM6bxxw4_uRQWNy5lIRoL2HDcBs3lZZfW2EorSY02AhFTQBIhf39L34q3dOe1XhOjDK7C329rFlzURkI0?purpose=fullsize
 
https://images.openai.com/static-rsc-4/e0uHBm1HuTyK0S92DlQtz_j5uPD0fSLMeyBZ-7uKGR0BaoXxLphDs_8NxYziqxKIjMqVXIeCHJrtCeiqmJinFpWB3dcO7EbXsVlX1r44XSRwrQRm9QMGGYA6YIT1upqF7wwnncQwQsbezj3XhJUa9mXf5sVXpI49EoKa36Sj2_vDtBFLZo7ARNQarPTARQIs?purpose=fullsize
 
https://images.openai.com/static-rsc-4/ds6WFatOqvLR7jNRJn9QriYQGq8gs96t2IyNnxXAz11Ahd5TJo4OzHSna91kJeRINGwo5ZKoCXFmK7uZPNKOBLAS3kE0h9vpL5GOiSdGsb7YEAsgE9h2KPDZdwAi1GZy8Bij4lorhnjTNIgY2wILgFmIjahLQ-KkLKlW4DRyLkZDgCgV6sMO-HvIBA0hQ0L8?purpose=fullsize
 
6

A curved θ-t graph therefore indicates changing angular velocity.

If the graph becomes increasingly steep in the positive direction, the angular velocity is increasing.


Comparing Rotational and Linear Kinematics

The equations for constant angular acceleration closely resemble the equations for constant linear acceleration.

Linear Motion Rotational Motion
x θ
v ω
a α
v_f = v_i + at ω_f = ω_i + αt
Δx = v_i t + 1/2 at² Δθ = ω_i t + 1/2 αt²
v_f² = v_i² + 2aΔx ω_f² = ω_i² + 2αΔθ
Δx = [(v_i + v_f)/2]t Δθ = [(ω_i + ω_f)/2]t

These rotational equations apply when:

angular acceleration is constant.


Angular Displacement with Constant Angular Acceleration

For constant α:

Δθ = ω_i t + 1/2 αt²

This allows angular displacement to be calculated when initial angular velocity, angular acceleration and time are known.


Worked Example

A wheel initially rotates at:

ω_i = 2 rad/s

It accelerates at:

α = 4 rad/s²

for:

t = 3 s

Calculate angular displacement.

Use:

Δθ = ω_i t + 1/2 αt²

Δθ = (2)(3) + 1/2(4)(3²)

Δθ = 6 + 18

Δθ = 24 rad


Finding Final Angular Velocity

For the same example:

ω_f = ω_i + αt

ω_f = 2 + (4)(3)

ω_f = 14 rad/s

The wheel rotates through 24 rad while increasing its angular velocity from 2 rad/s to 14 rad/s.


Equation Without Time

If time is not given, use:

ω_f² = ω_i² + 2αΔθ

This is the rotational equivalent of:

v_f² = v_i² + 2aΔx


Worked Example: Finding Angular Acceleration

A wheel changes from:

ω_i = 4 rad/s

to:

ω_f = 10 rad/s

while rotating through:

Δθ = 21 rad

Use:

ω_f² = ω_i² + 2αΔθ

10² = 4² + 2α(21)

100 = 16 + 42α

84 = 42α

α = 2 rad/s²


Average Angular Velocity During Constant Acceleration

When angular acceleration is constant:

ω_avg = (ω_i + ω_f)/2

Therefore:

Δθ = [(ω_i + ω_f)/2]t


Worked Example

A motor speeds up uniformly from:

10 rad/s

to:

30 rad/s

in:

5 s

Average angular velocity:

ω_avg = (10 + 30)/2

ω_avg = 20 rad/s

Angular displacement:

Δθ = ω_avg t

Δθ = (20)(5)

Δθ = 100 rad


Rotational Motion from Rest

If an object begins from rest:

ω_i = 0

The equations simplify.

Final angular velocity:

ω_f = αt

Angular displacement:

Δθ = 1/2 αt²

and:

ω_f² = 2αΔθ


Worked Example: Motor Starting from Rest

A motor starts from rest and accelerates uniformly at:

α = 5 rad/s²

for:

4 s

Final angular velocity:

ω_f = αt

ω_f = (5)(4)

ω_f = 20 rad/s

Angular displacement:

Δθ = 1/2 αt²

Δθ = 1/2(5)(4²)

Δθ = 40 rad

So the motor rotates through:

40 rad

during the acceleration.


Converting Angular Displacement to Revolutions

Suppose:

Δθ = 40 rad

Since:

1 revolution = 2π rad

number of revolutions:

N = 40/(2π)

N ≈ 6.37 revolutions


Slowing a Wheel to Rest

A wheel rotates initially at:

ω_i = 40 rad/s

It slows uniformly at:

α = −5 rad/s²

Find the stopping time.

Use:

ω_f = ω_i + αt

0 = 40 − 5t

t = 8 s

Now find the angular displacement:

Δθ = [(ω_i + ω_f)/2]t

Δθ = (40 + 0)/2

Δθ = 20(8)

Δθ = 160 rad

Number of revolutions:

N = 160/(2π)

≈ 25.5 revolutions

The wheel therefore makes more than 25 revolutions while slowing to rest.


Angular and Tangential Acceleration

Angular acceleration is related to the tangential acceleration of points on a rotating object.

Recall:

v = rω

If angular velocity changes:

a_t = rα

where:

  • a_t = tangential acceleration
  • r = distance from rotation axis
  • α = angular acceleration
https://images.openai.com/static-rsc-4/Tcw5Hnv0TmlFHGCGH5DS7uf2aDzCWY0dsUNfiiRmeritq4POcDqoPrlB6uW7VVSIx07l8fWKr12d51EcajSmRWEIg44a5b0RmvPcRtPKlUS1pqBo88SBdaoedvDec44WO7gA1CRvEoMoyXYDmPa2OJpawAnBT6sbGNslDDBUY1lN-OIkZvCBWld6pcj96uSl?purpose=fullsize
 
https://images.openai.com/static-rsc-4/r_dUQNYk5xvyn3cgHagMeVmD-RAu33laexdhLd9ZdYQkILlvC3IT-EthfwTCcGqQUSVrrT1iZqEhG_IrXoog3mbOuuKFYG302zJUY6Iqo8IPECjOG4V5UGHW_s1URLfUXnXxk7X1NxQ_hMgaI6TY7yAABYasBBIiKjzHf7SNyiiV-o394A5MVWv289XdF6pB?purpose=fullsize
 
https://images.openai.com/static-rsc-4/4afg-aRpcx75SrfGioijYuxoApXIVbITKPjGdnFMoYTJMkpq42TqAK3fDN9f89mW1VOxIBZ-ukfQ_jqSmdcSLmnsWr2s4UjubbJMcS_ou-t5ebqKwYH09M2fVps8bvf0CFB4Wxps1itOgyyvRoOZ_JwEQDEaIKEni0ILznZhugsl_r7N8AVT8K73uMOsAQLK?purpose=fullsize
 
8

Same Angular Acceleration, Different Tangential Accelerations

Every point on a rigid rotating object has the same angular acceleration.

But:

a_t = rα

so points farther from the axis have greater tangential acceleration.

Suppose:

α = 6 rad/s²

Point A:

r_A = 0.10 m

Point B:

r_B = 0.40 m

Then:

a_A = (0.10)(6)

a_A = 0.60 m/s²

and:

a_B = (0.40)(6)

a_B = 2.4 m/s²

Both have the same angular acceleration, but Point B has four times the tangential acceleration.


Tangential and Centripetal Acceleration

A point on an accelerating rotating object can experience two different components of linear acceleration.

Tangential acceleration:

a_t = rα

This changes the magnitude of the linear velocity.

Centripetal acceleration:

a_c = rω²

This changes the direction of the linear velocity.

https://images.openai.com/static-rsc-4/oXHzYDi0EkMWmRKLDNuMIyjpu5XCHCCDxrV_dvu7cOSWIQQ59WEiPDwQHh8mH00JDo3IVOEwkP-d48II34dTShS9RA2e6W4BlJFVEQTW0z--UnSLm_YNsBlIEhDvcVqTFVEQSYH1EBwnEonNwgU-f8SAnwx1TXIKBp7lNWDZ6U-9qTW1LP_LczWFgSG2rdZM?purpose=fullsize
 
https://images.openai.com/static-rsc-4/Tcw5Hnv0TmlFHGCGH5DS7uf2aDzCWY0dsUNfiiRmeritq4POcDqoPrlB6uW7VVSIx07l8fWKr12d51EcajSmRWEIg44a5b0RmvPcRtPKlUS1pqBo88SBdaoedvDec44WO7gA1CRvEoMoyXYDmPa2OJpawAnBT6sbGNslDDBUY1lN-OIkZvCBWld6pcj96uSl?purpose=fullsize
 
https://images.openai.com/static-rsc-4/NvA-vDy1t6qcahxAT6s70wKPKXWEkz2GdOi-oUiAgajOa_HT26aK1jMp4x9LrnxQ3EiMYweyPq6dCtDYclxjv7f9-i2SmsUKM3zhKv_PFez39u_R7yVibagfkbUvOM2ssvXD8E0nP-Aw1HvQehVa45osmxh1uAZLTjJ9gnFY7pxw0Hu6F_mJmfjkM8LJa7ME?purpose=fullsize
 
9

The two accelerations point in different directions:

  • tangential acceleration is tangent to the circular path
  • centripetal acceleration points toward the axis

Total Linear Acceleration

Because tangential and centripetal accelerations are perpendicular, the magnitude of the total acceleration can be found using:

a_total = √(a_t² + a_c²)


Worked Example

A point is:

r = 0.50 m

from the centre of a rotating disk.

At one instant:

ω = 4 rad/s

and:

α = 6 rad/s²

Tangential acceleration:

a_t = rα

a_t = (0.50)(6)

a_t = 3.0 m/s²

Centripetal acceleration:

a_c = rω²

a_c = (0.50)(4²)

a_c = 8.0 m/s²

Total acceleration:

a_total = √(3² + 8²)

a_total = √73

a_total ≈ 8.54 m/s²


Angular Acceleration in Wheels

When a vehicle accelerates, its wheels also experience angular acceleration.

For rolling without slipping:

v = rω

and:

a = rα

Therefore:

α = a/r

A smaller wheel requires greater angular acceleration to produce the same linear acceleration.


Worked Vehicle Example

A car accelerates at:

a = 3.0 m/s²

Its wheels have radius:

r = 0.30 m

Then:

α = a/r

α = 3.0/0.30

α = 10 rad/s²


Angular Acceleration in Gears

When meshing gears accelerate without slipping at their contact point:

r₁α₁ = r₂α₂

in magnitude.

Smaller gears therefore experience larger angular accelerations.

Because meshing gears rotate in opposite directions, their angular accelerations also have opposite signs when they are both speeding up.


Worked Gear Example

Gear A has radius:

4 cm

and angular acceleration:

+12 rad/s²

Gear B has radius:

12 cm

Then:

r_A α_A = r_B |α_B|

(4)(12) = (12)|α_B|

|α_B| = 4 rad/s²

Since the gears rotate in opposite directions:

α_B = −4 rad/s²


Angular Acceleration in Machinery

Angular acceleration is important whenever rotating machinery:

  • starts
  • stops
  • speeds up
  • slows down
  • reverses direction

Examples include:

  • electric motors
  • turbines
  • washing machines
  • fans
  • drills
  • vehicle wheels
  • robotic joints
  • industrial machinery

Rapid angular acceleration can produce large forces and stresses, so engineers often control how quickly machinery changes rotational speed.


Example: Washing Machine Spin Cycle

A washing-machine drum may begin nearly at rest and gradually increase its angular velocity.

The motor does not normally accelerate it instantly to full rotational speed.

Instead, angular acceleration is controlled to reduce:

  • mechanical stress
  • vibration
  • slipping
  • excessive forces on the motor and drum

When the spin cycle ends, negative angular acceleration slows the drum.


Angular Acceleration and Torque

Angular acceleration is closely connected to torque, which will become important when studying rotational dynamics.

In linear motion:

net force causes linear acceleration

In rotational motion:

net torque causes angular acceleration

The rotational equivalent of Newton's Second Law is:

τ_net = Iα

where:

  • τ_net = net torque
  • I = moment of inertia
  • α = angular acceleration

A greater net torque generally produces greater angular acceleration.

A larger moment of inertia makes an object more difficult to accelerate rotationally.


Interpreting Multiple Rotational Graphs

Three important rotational graphs are:

Angular Position-Time

gradient → angular velocity

Angular Velocity-Time

gradient → angular acceleration

area → angular displacement

Angular Acceleration-Time

area → change in angular velocity

These relationships closely parallel linear kinematics.


Graph Relationship Summary

Graph Gradient Represents Area Represents
θ vs t ω —
ω vs t α Δθ
α vs t — Δω

Understanding these relationships allows complex rotational motion to be analyzed without relying only on equations.


Example: Complete Graph Analysis

Suppose a wheel has:

ω = 4 rad/s at t = 0

and increases linearly to:

ω = 16 rad/s at t = 6 s

Angular Acceleration

α = (16 − 4)/6

α = 2 rad/s²

Angular Displacement

The area under the ω-t graph is a trapezoid:

Δθ = (4 + 16)/2

Δθ = (10)(6)

Δθ = 60 rad

Revolutions

N = 60/(2π)

N ≈ 9.55 revolutions

So the graph can provide angular acceleration, angular displacement and number of rotations.


Choosing a Rotational Kinematics Equation

For constant angular acceleration, choose an equation based on the quantities given.

If you know ω_i, α and t:

ω_f = ω_i + αt

If you know ω_i, α and t and need displacement:

Δθ = ω_i t + 1/2 αt²

If time is missing:

ω_f² = ω_i² + 2αΔθ

If you know both initial and final angular velocity:

Δθ = [(ω_i + ω_f)/2]t

This is very similar to choosing equations in linear kinematics.


Problem-Solving Strategy

When solving angular acceleration problems:

Choose a positive direction

Usually:

counterclockwise = positive.

Write the known values

Identify:

  • ω_i
  • ω_f
  • α
  • Δθ
  • t

Include signs

Clockwise quantities may be negative.

Choose the appropriate equation

Avoid using an equation containing unnecessary unknown quantities.

Calculate

Keep angular quantities in radians when using rotational kinematics equations.

Interpret the answer

Check:

  • sign
  • units
  • direction
  • whether the object is speeding up or slowing down

Common Mistakes

Thinking negative angular acceleration always means slowing down

An object with negative angular velocity and negative angular acceleration is speeding up clockwise.

Ignoring the sign of angular velocity

Both ω and α must be considered when deciding whether an object speeds up or slows down.

Confusing angular velocity and angular acceleration

Angular velocity is measured in rad/s.

Angular acceleration is measured in rad/s².

Thinking α = 0 means the object is stationary

It may be rotating at constant angular velocity.

Using degrees in rotational kinematics equations

Radians should normally be used.

Forgetting that area under an ω-t graph gives angular displacement

The gradient gives α; the area gives Δθ.

Confusing tangential and centripetal acceleration

Tangential acceleration changes speed.

Centripetal acceleration changes direction.

Assuming every point on a rotating object has the same tangential acceleration

They have the same angular acceleration, but a_t depends on radius.

Using constant-acceleration equations when α is changing

The standard rotational kinematics equations apply directly only when angular acceleration is constant.


Key Terms

Angular acceleration (α) — rate of change of angular velocity.

Average angular acceleration — change in angular velocity divided by elapsed time.

Instantaneous angular acceleration — rate of change of angular velocity at a particular instant.

Radian per second squared (rad/s²) — SI unit of angular acceleration.

Angular velocity (ω) — rate of change of angular position.

Angular displacement (Δθ) — change in angular position.

Positive angular acceleration — angular velocity changing in the positive rotational direction.

Negative angular acceleration — angular velocity changing in the negative rotational direction.

Tangential acceleration (a_t) — acceleration tangent to a circular path caused by changing angular speed.

Centripetal acceleration (a_c) — inward acceleration caused by changing direction during circular motion.

Constant angular acceleration — rotational motion in which angular velocity changes by equal amounts during equal time intervals.

Torque — turning effect of a force.

Moment of inertia — measure of an object's resistance to angular acceleration.

Rotational kinematics — study of rotational motion using angular position, velocity and acceleration.


Key Takeaways

  • Angular acceleration describes how rapidly angular velocity changes.
  • Angular acceleration is represented by α.
  • Its SI unit is rad/s².
  • Average angular acceleration is α = (ω_f − ω_i)/Δt.
  • Instantaneous angular acceleration describes the change in angular velocity at a particular moment.
  • Positive α means angular velocity is changing in the positive direction.
  • Negative α means angular velocity is changing in the negative direction.
  • Negative angular acceleration does not automatically mean slowing down.
  • When ω and α have the same sign, rotational speed increases.
  • When ω and α have opposite signs, rotational speed decreases.
  • An object can slow to zero angular velocity and then reverse direction.
  • The gradient of an angular velocity-time graph gives angular acceleration.
  • The area under an angular velocity-time graph gives angular displacement.
  • The area under an angular acceleration-time graph gives the change in angular velocity.
  • For constant angular acceleration, ω_f = ω_i + αt.
  • Angular displacement can be calculated using Δθ = ω_i t + 1/2 αt².
  • When time is unknown, ω_f² = ω_i² + 2αΔθ can be used.
  • Angular acceleration and tangential acceleration are related by a_t = rα.
  • Centripetal acceleration is a_c = rω².
  • Points on a rigid object share the same angular acceleration but can have different tangential accelerations.
  • Angular acceleration is the rotational counterpart of linear acceleration and forms the basis for rotational kinematics and dynamics.

Check Your Understanding

  1. Define angular acceleration and state its SI unit.
  2. A wheel's angular velocity increases from 4 rad/s to 20 rad/s in 4 s. Calculate its average angular acceleration.
  3. A fan slows from 30 rad/s to 6 rad/s in 8 s. Calculate its angular acceleration.
  4. An object has ω = −8 rad/s and α = −3 rad/s². State its rotational direction and determine whether it is speeding up or slowing down.
  5. An object has ω = −12 rad/s and α = +4 rad/s². Explain what is happening to its rotational motion.
  6. A motor initially rotates at 5 rad/s and accelerates uniformly at 3 rad/s² for 6 s. Calculate its final angular velocity.
  7. A wheel starts from rest and accelerates at 4 rad/s² for 5 s. Calculate its final angular velocity and angular displacement.
  8. A disk rotates initially at 25 rad/s and slows uniformly at −5 rad/s². Calculate how long it takes to stop.
  9. For Question 8, calculate the angular displacement before the disk stops and convert it to revolutions.
  10. A wheel increases its angular velocity uniformly from 6 rad/s to 18 rad/s in 4 s. Calculate the angular acceleration and angular displacement during this interval.
  11. A point lies 0.30 m from the centre of a disk with angular acceleration 8 rad/s². Calculate its tangential acceleration.
  12. At one instant, a point 0.40 m from a rotation axis has ω = 5 rad/s and α = 3 rad/s². Calculate its tangential acceleration, centripetal acceleration and total acceleration.
  13. An angular velocity-time graph rises linearly from −10 rad/s at t = 0 to +10 rad/s at t = 5 s. Calculate the angular acceleration and describe how the object's direction of rotation changes.
  14. Explain the meaning of the gradient and area of an angular velocity-time graph.
  15. A student says, "If angular acceleration is negative, the object must be slowing down." Evaluate this statement using examples involving both positive and negative angular velocity.

4. Rotational Motion Equations

Learning outcomes
  • I can use rotational kinematic equations.
  • I can identify variables in rotational motion problems.
  • I can solve constant-angular-acceleration problems.
  • I can compare rotational and linear kinematic equations.
  • I can apply equations to real-world situations.

Key Topics:
  • Definition of degrees of freedom.
  • Translational, rotational, and combined motions.

Rotational Motion Equations

Rotational motion can be analyzed using a set of rotational kinematic equations. These equations describe how angular position, angular velocity, and angular acceleration change with time.

They closely resemble the equations used for linear motion.

The key difference is that linear quantities are replaced by their rotational equivalents:

  • displacement Δx → angular displacement Δθ
  • velocity v → angular velocity ω
  • acceleration a → angular acceleration α

When angular acceleration is constant, the same mathematical patterns used in linear kinematics can be applied to rotation.

https://images.openai.com/static-rsc-4/SX8hjuqeIRpR6UdD_5y6chVCLoTOx_KMPpyqnXHu6cqPic05RUhzo7LiCjWQNeX0kvjeW5n_ZEnufbwj0CkatZo5I_zEf3CU9-wesUkTjSYuoIO_3d1JxcSMXDSdQmlMnyHOibCAUS8jiG1Sh9oFTtettZ7BxkfY38vHwr7UHU3g0AtKLlR56kjX12emgSzr?purpose=fullsize
 
https://images.openai.com/static-rsc-4/VD-LNbYwG4DpIi5SFw0MbHJvxmP0FQkzrsKaEG2hFfZdftEyfNJcF3wxjOkECHMV3UKAEYUjlNytBdK5alZ4VObm7bofwW5KuKZ1yBm3WwcLtC4MzEqH4pAzZ_KYwyXUiDNb7cERBehd_CX7p3mXbB6pXEu4FsPY696t4lvpYdI6luobc3eqi92SUjtMHlDu?purpose=fullsize
 
https://images.openai.com/static-rsc-4/1QZVJR43pwMRp2UdMk72B7n6Q55YS-V9KAhPJrJD-B3QL6hOHN3AZ_5b9mkWcZFL-az4U498d6FxG4aY54-G4CNtbF8CMEzXLJB90vBvY-_OEvzPCEbuZJ98nYBDdjNKf8xW-x2SiOjNJuB7iNwSRjPZZ8tV7LUt53zFkKGWQRI3pmTlb0XKOQtsYFENidAP?purpose=fullsize
 
9

The Main Rotational Variables

Before choosing an equation, identify the quantities involved.

Quantity Symbol SI Unit
Initial angular position θ_i rad
Final angular position θ_f rad
Angular displacement Δθ rad
Initial angular velocity ω_i rad/s
Final angular velocity ω_f rad/s
Angular acceleration α rad/s²
Time t s

Angular displacement is:

Δθ = θ_f − θ_i

These variables form the basis of rotational kinematics.


Sign Conventions

Direction must be included when solving rotational-motion problems.

A common convention is:

counterclockwise = positive

clockwise = negative

Therefore:

  • +ω → counterclockwise angular velocity
  • −ω → clockwise angular velocity
  • +α → angular velocity changing in the positive direction
  • −α → angular velocity changing in the negative direction

The sign of α does not automatically tell you whether the object is speeding up or slowing down.

The signs of both ω and α must be considered.


The Constant-Angular-Acceleration Equations

When angular acceleration is constant, four main equations are particularly useful.

Angular velocity and time

ω_f = ω_i + αt

Angular displacement and time

Δθ = ω_i t + 1/2 αt²

Angular velocity and displacement

ω_f² = ω_i² + 2αΔθ

Average angular velocity

Δθ = [(ω_i + ω_f)/2]t

These equations apply when:

α = constant

They should not be applied directly when angular acceleration varies significantly with time.


Comparing Linear and Rotational Equations

The rotational equations are almost identical to the familiar linear kinematic equations.

Linear Motion Rotational Motion
Δx Δθ
v_i ω_i
v_f ω_f
a α
v_f = v_i + at ω_f = ω_i + αt
Δx = v_i t + 1/2 at² Δθ = ω_i t + 1/2 αt²
v_f² = v_i² + 2aΔx ω_f² = ω_i² + 2αΔθ
Δx = [(v_i + v_f)/2]t Δθ = [(ω_i + ω_f)/2]t

This correspondence is extremely useful.

If you understand constant-acceleration linear motion, much of rotational kinematics follows the same mathematical structure.


Why the Equations Are Similar

Consider linear motion:

a = Δv/Δt

For rotational motion:

α = Δω/Δt

Both describe how a velocity changes with time.

Similarly:

v = Δx/Δt

corresponds to:

ω = Δθ/Δt

Rotation therefore has its own versions of position, velocity and acceleration.

https://images.openai.com/static-rsc-4/l9hQm121J6vJe52ggQhRqawHYGax55DjGrm_1tD89I1arOteicztB17vtGB4sgj0Gz7UWhiyUkJlSPW0o0tAWYGdWhUYTaRDg0Q0fb0d5nCdcLtlK5Uwt0zourV43OuqWYAfpuTD5pzcJC4EBF6lUKqte5bRx6fS9cU_hGfezvuQfu03Pmln_gFo1lOtHXfY?purpose=fullsize
 
https://images.openai.com/static-rsc-4/qt20j6Izw52xcKS6mvKBhZ5KaDUKTfpEFHhL7R8sCWReZStgLaR53G05br5g3YDxcVHogP79lelDWeOAuPsWmeTIP-sCDIAf7jpLpsuMvksbJi7Dqsp2ZSs483j2zctfMNwOdNa3qeR-H9FXBMsKUrg8Cwsq02sRe48_-kI1z9r2mUPbt_Bpr7U3iHaPodSQ?purpose=fullsize
 
https://images.openai.com/static-rsc-4/gnZKqMrnsk4TdnVMWcg9smrLFVo3trcGDtDljqSLssRwEPfo9ujtQFwlIpRDMGYF46WDF7fMdKiPgsmSDfOTapPRv2tk8WlUpG2qQo8bczd8BV_tzMFM87YD5Bo24hnGEzYnSphP2ut5e-M5_D8jiR1d4pHmZIUSxCk9luLo873WSvoYLV4IaVHV37TL1AeR?purpose=fullsize
 
7

Choosing the Correct Equation

A good strategy is to list the five major quantities:

ω_i, ω_f, α, Δθ, t

Then identify:

  • what you know
  • what you need to find
  • which quantity is not involved

Choose an equation that contains the known quantities and the unknown you want.


Equation Selection Table

If you know... Useful Equation
ω_i, α, t ω_f = ω_i + αt
ω_i, α, t Δθ = ω_i t + 1/2 αt²
ω_i, ω_f, α ω_f² = ω_i² + 2αΔθ
ω_i, ω_f, t Δθ = [(ω_i + ω_f)/2]t
ω_i, ω_f, t α = (ω_f − ω_i)/t

The best equation is usually the one containing only one unknown.


Angular Velocity and Time

The first rotational kinematic equation is:

ω_f = ω_i + αt

It describes how angular velocity changes when angular acceleration is constant.


Worked Example: Motor Speeding Up

A motor initially rotates at:

ω_i = 5 rad/s

It accelerates at:

α = 3 rad/s²

for:

t = 4 s

Calculate its final angular velocity.

Use:

ω_f = ω_i + αt

ω_f = 5 + (3)(4)

ω_f = 17 rad/s

Therefore:

ω_f = 17 rad/s


Worked Example: Slowing Wheel

A wheel rotates at:

ω_i = 30 rad/s

and experiences:

α = −5 rad/s²

for:

4 s

Then:

ω_f = 30 + (−5)(4)

ω_f = 10 rad/s

Therefore:

ω_f = 10 rad/s

The wheel is still rotating in the positive direction, but it has slowed.


Finding Angular Acceleration

The same equation can be rearranged:

α = (ω_f − ω_i)/t

Suppose a fan speeds up from:

10 rad/s

to:

40 rad/s

in:

6 s

Then:

α = (40 − 10)/6

α = 5 rad/s²

Therefore:

α = 5 rad/s²


Finding Time

The equation can also be rearranged:

t = (ω_f − ω_i)/α

Suppose:

ω_i = 8 rad/s

ω_f = 32 rad/s

α = 6 rad/s²

Then:

t = (32 − 8)/6

t = 4 s

Therefore:

t = 4 s


Angular Displacement and Time

When initial angular velocity, angular acceleration and time are known:

Δθ = ω_i t + 1/2 αt²

This equation includes two contributions to angular displacement.

ω_i t

represents the displacement that would occur because of the initial angular velocity.

1/2 αt²

represents the additional effect of angular acceleration.


Worked Example: Accelerating Wheel

A wheel initially rotates at:

ω_i = 4 rad/s

It accelerates at:

α = 2 rad/s²

for:

t = 5 s

Calculate its angular displacement.

Δθ = ω_i t + 1/2 αt²

Δθ = (4)(5) + 1/2(2)(5²)

Δθ = 20 + 25

Δθ = 45 rad


Starting from Rest

If an object begins from rest:

ω_i = 0

Then:

ω_f = αt

and:

Δθ = 1/2 αt²

These simplified equations are useful for motors, wheels and machinery that begin stationary.


Worked Example: Turntable Starting from Rest

A turntable starts from rest and accelerates at:

α = 2.5 rad/s²

for:

6 s

Final angular velocity:

ω_f = αt

ω_f = (2.5)(6)

ω_f = 15 rad/s

Angular displacement:

Δθ = 1/2 αt²

Δθ = 1/2(2.5)(6²)

Δθ = 45 rad

Therefore:

Δθ = 45 rad


Converting Angular Displacement to Revolutions

Angular displacement is usually calculated in radians.

One complete revolution is:

2π rad

Therefore:

N = Δθ/(2π)

where N is the number of revolutions.

For the previous example:

N = 45/(2π)

N ≈ 7.16 revolutions


Angular Velocity and Displacement

If time is not known, use:

ω_f² = ω_i² + 2αΔθ

This equation is particularly useful when a question asks:

  • how far an object rotates before stopping
  • how much rotation occurs before reaching a certain angular velocity
  • what angular acceleration is required over a particular angle

Worked Example: Finding Angular Displacement

A wheel speeds up from:

ω_i = 6 rad/s

to:

ω_f = 18 rad/s

with constant angular acceleration:

α = 4 rad/s²

Use:

ω_f² = ω_i² + 2αΔθ

18² = 6² + 2(4)Δθ

324 = 36 + 8Δθ

288 = 8Δθ

Δθ = 36 rad


Worked Example: Braking Distance in Rotation

A machine shaft rotates at:

ω_i = 40 rad/s

It is slowed with:

α = −8 rad/s²

How far does it rotate before stopping?

At rest:

ω_f = 0

Use:

ω_f² = ω_i² + 2αΔθ

0² = 40² + 2(−8)Δθ

0 = 1600 − 16Δθ

16Δθ = 1600

Δθ = 100 rad

Number of revolutions:

N = 100/(2π)

≈ 15.9 revolutions

The shaft completes almost 16 additional revolutions before stopping.


Average Angular Velocity

For constant angular acceleration:

ω_avg = (ω_i + ω_f)/2

Angular displacement can therefore be calculated using:

Δθ = [(ω_i + ω_f)/2]t


Worked Example

A fan increases its angular velocity uniformly from:

8 rad/s

to:

24 rad/s

during:

5 s

Average angular velocity:

ω_avg = (8 + 24)/2

ω_avg = 16 rad/s

Then:

Δθ = ω_avg t

Δθ = (16)(5)

Δθ = 80 rad


Why the Average Equation Works

If angular acceleration is constant, angular velocity changes uniformly.

For example:

8 → 12 → 16 → 20 → 24 rad/s

The average of the initial and final angular velocities represents the average angular velocity over the interval.

Therefore:

ω_avg = (ω_i + ω_f)/2

This relationship does not generally apply if angular acceleration varies unpredictably.


Rotational Motion Graphs

Rotational kinematic equations can also be understood graphically.

The three most useful graphs are:

  • angular position-time
  • angular velocity-time
  • angular acceleration-time
https://images.openai.com/static-rsc-4/6SC_oTounyX2h0gpuYqzte_q7HMJv2YSqGmR3NufK5o5ugZFD0GyYaHbv4I6s0FnLc5IxS5lrIWYMbZGu2aKo1nLQwxrGwc1mSUJFz1iymsVUnm8o3ajTm2ePu3rWriQ20uXklJhwyuwmegxOmESb2jRUitr1wgvxlua74F3gZajrMaffh2KTWNr_T47xEhr?purpose=fullsize
 
https://images.openai.com/static-rsc-4/1LZ9tS1d_WCgbyV_jN0RvnJNQm2P2NC1x7xkvVNzzdNe7KNemizBx8KWkK36EJlkXgZCezNpnJd53J83NpWxBF2aAMU3cUrrRVqYucWv3SHmsD9qqa7YWPJezyScrnCZOse6XO2uirVPNKeTR9AiMFClFTW3E2vG-SrRg6LPNf7f-19zYhAG6Y94VFOUWv1r?purpose=fullsize
 
https://images.openai.com/static-rsc-4/XafqcxiGzm7_25idxwJhyACX6fVLH0dT0Iq0wZSDDwKonusrXgmcJeeqycMO4xyP2NvkIpzdbq42yeSfvKrkfN7i0D5BGbKruXxJFkaYYDZ6K-Cf-VqWD5JSHn2y9su8hDelSHZ9GottdMYK0rGKmZvPnCL3NJyz8do4Fn-OKxWKa9Gfg-ABpnM7H_LhT8B6?purpose=fullsize
 
6

Angular Position-Time Graph

On a θ-t graph:

gradient = angular velocity

Therefore:

ω = gradient of θ-t graph

A straight line means constant angular velocity.

A curved line means angular velocity is changing.


Angular Velocity-Time Graph

On an ω-t graph:

gradient = angular acceleration

Therefore:

α = gradient of ω-t graph

The area under the graph represents:

angular displacement


Worked Graph Example

Suppose angular velocity increases uniformly from:

5 rad/s

to:

25 rad/s

over:

4 s

Angular acceleration:

α = (25 − 5)/4

α = 5 rad/s²

Angular displacement is the area under the ω-t graph:

Δθ = (5 + 25)/2

Δθ = (15)(4)

Δθ = 60 rad


Angular Acceleration-Time Graph

On an α-t graph:

area = change in angular velocity

For constant angular acceleration:

Δω = αt

Suppose:

α = 3 rad/s²

for:

t = 6 s

Then:

Δω = (3)(6)

Δω = 18 rad/s


Positive and Negative Motion

Correct use of signs is essential.

Suppose counterclockwise is positive.

A wheel has:

ω_i = +20 rad/s

α = −4 rad/s²

After 3 s:

ω_f = 20 + (−4)(3)

ω_f = +8 rad/s

The wheel is still rotating counterclockwise but slowing down.


Reversing Direction

Continue the previous motion for:

7 s

Then:

ω_f = 20 + (−4)(7)

ω_f = −8 rad/s

The negative final angular velocity means the wheel has reversed direction and is now rotating clockwise.

It must have passed through:

ω = 0

during the motion.


When Does It Reverse?

Use:

0 = 20 − 4t

4t = 20

t = 5 s

Therefore:

  • 0–5 s → counterclockwise and slowing
  • at 5 s → momentarily stationary
  • after 5 s → clockwise and speeding up

Angular Displacement During a Direction Reversal

For the same motion:

ω_i = 20 rad/s

α = −4 rad/s²

t = 7 s

Use:

Δθ = ω_i t + 1/2 αt²

Δθ = (20)(7) + 1/2(−4)(7²)

Δθ = 140 − 98

Δθ = +42 rad

The net angular displacement is +42 rad.

Notice that this is not the same as the total angular distance travelled because the wheel changed direction.


Angular Displacement Versus Total Rotation

When an object reverses direction, distinguish between:

angular displacement

and:

total angle rotated

Angular displacement depends only on the net change in angular position.

Total angular distance adds all rotation regardless of direction.

This is similar to the distinction between displacement and distance in linear motion.


Connecting Angular and Linear Motion

Rotational quantities can be connected to linear quantities.

Angular displacement:

s = rθ

Tangential speed:

v = rω

Tangential acceleration:

a_t = rα

https://images.openai.com/static-rsc-4/xpp-DfeAppUYRQ7FQkr3eQSUd_IdvYywdD7w1YNdqH41ftg1iO09w85kYsb0KLSoghuT4qefzSQQUD7t5vmqR8f4hLonvAY-12IPUWVRHDj-Z_TE5VHQVy27AoM2ySmvHzXgpcDfM03C6ltI1eKGArmvFp7A2pbYsUpBYKLGvda79cXKecOByq74OSTaLLhs?purpose=fullsize
 
https://images.openai.com/static-rsc-4/1pHYCciIA6OfjEJ2_hxJAChn5NJ3TXmR8Qg5J6OtmRd7Dupee6hsuR5h2V1N6N4LHhKArZ-dgMChmgjFKcZO-dBodO6v165fyd0j0PtUIFO3iDYwzGKiNoUPetr5-QSxQCEdgYC72huNP9lrtH0JeA1xGWwb45Es4RjKoDSs19Zj8k6cO_U2L0vvk_4rErDn?purpose=fullsize
 
https://images.openai.com/static-rsc-4/1QZVJR43pwMRp2UdMk72B7n6Q55YS-V9KAhPJrJD-B3QL6hOHN3AZ_5b9mkWcZFL-az4U498d6FxG4aY54-G4CNtbF8CMEzXLJB90vBvY-_OEvzPCEbuZJ98nYBDdjNKf8xW-x2SiOjNJuB7iNwSRjPZZ8tV7LUt53zFkKGWQRI3pmTlb0XKOQtsYFENidAP?purpose=fullsize
 
9

These relationships allow rotational equations to describe real moving objects such as:

  • wheels
  • pulleys
  • gears
  • turbines
  • motors

Worked Example: Accelerating Bicycle Wheel

A bicycle wheel has radius:

r = 0.35 m

It starts from rest and has:

α = 6 rad/s²

for:

t = 3 s

Final Angular Velocity

ω_f = αt

ω_f = (6)(3)

ω_f = 18 rad/s

Final Linear Speed

v = rω

v = (0.35)(18)

v = 6.3 m/s

Tangential Acceleration

a_t = rα

a_t = (0.35)(6)

a_t = 2.1 m/s²

Angular Displacement

Δθ = 1/2 αt²

Δθ = 1/2(6)(3²)

Δθ = 27 rad

Distance Travelled

s = rθ

s = (0.35)(27)

s = 9.45 m

The rotational equations therefore describe the forward motion of the bicycle as well.


Rolling Without Slipping

For a wheel rolling without slipping:

s = rθ

v = rω

a = rα

These relationships connect the rotation of the wheel with the translation of the vehicle.

https://images.openai.com/static-rsc-4/AghkCZct4Sxa9TuV0T_nuf9uUrcwd_Nxt0tGdsOcopC_GyXJ83z8CvSm2ikRVoe0YPym-1_FUj180ip3E8t7T13kfha8TEV9MziW8tj7UgEggDaHHUaM4BppTBq9qq-bon4NTO4tiDP8w7EToq1Sw3SzjrBwfx45sGnuaA97qtocKofayio8x7n7S2v_s-g3?purpose=fullsize
 
https://images.openai.com/static-rsc-4/-A08_q0aPxAC6Dc5xr7nnSiuTYSRzkn2cPX3ULE2t87BQA08cSwXHyC6DlH2XljOThmXjUhHZOqxCzHUqi4Uz1OPqZTep1rAfvf7BnWgwRecEfwwcurG0tapBvEMwgiAn4Kgl5Aceozb-K7wc4qscat5qtZg1ue6DN4-pcZ7Akx5jN5CFx-p2qXdSBjceJul?purpose=fullsize
 
https://images.openai.com/static-rsc-4/RC16bS_qZPD6UHcd5b1kt-7bZpm5GwuGJgG_xIv3h6oGMlTTijJAQ5WRKGg1R-GkmT41RSazUm1XExIKYSllb6vylmiN0hdOAEX7NdtuaIpuybRgb-zfioonvqM6UM08FmFTvcucl37tSgpauIig0c6vyHCVYkUvP3BtEI186L858hbox7qYs8FYv8v48MQW?purpose=fullsize
 
5

Worked Example: Car Accelerating

A car accelerates uniformly from rest at:

a = 2.5 m/s²

Its wheels have radius:

r = 0.40 m

Find the angular acceleration.

Use:

a = rα

α = a/r

α = 2.5/0.40

α = 6.25 rad/s²

After 8 seconds:

ω = αt

ω = (6.25)(8)

ω = 50 rad/s

The car's linear speed is:

v = rω

v = (0.40)(50)

v = 20 m/s

This agrees with linear kinematics:

v = at

v = (2.5)(8)

v = 20 m/s

Both approaches describe the same motion.


Rotating Machinery

Rotational kinematic equations are frequently used to describe motors and machinery.

Consider an industrial motor that starts from rest and reaches:

180 rad/s

in:

12 s

Assuming constant angular acceleration:

α = (180 − 0)/12

α = 15 rad/s²

Angular displacement during startup:

Δθ = (0 + 180)/2

Δθ = 90(12)

Δθ = 1080 rad

Number of revolutions:

N = 1080/(2π)

≈ 172 revolutions

Even during a short startup, high-speed machinery may complete many revolutions.


Braking a Rotating Machine

Suppose the same motor is rotating at:

180 rad/s

and must stop in:

15 s

Then:

α = (0 − 180)/15

α = −12 rad/s²

Angular displacement while stopping:

Δθ = (180 + 0)/2

Δθ = 90(15)

Δθ = 1350 rad

Number of revolutions:

N = 1350/(2π)

≈ 215 revolutions

A rapidly rotating machine can continue turning many times even while braking.


Washing Machine Example

A washing-machine drum starts from rest and reaches:

ω_f = 100 rad/s

in:

20 s

Assuming constant angular acceleration:

α = (100 − 0)/20

α = 5 rad/s²

Angular displacement:

Δθ = (0 + 100)/2

Δθ = 50(20)

Δθ = 1000 rad

Number of revolutions:

N = 1000/(2π)

≈ 159 revolutions


Converting rpm to Angular Velocity

Real machines often give rotational speed in:

revolutions per minute (rpm)

Convert using:

ω = rpm × 2π/60


Worked Example: 1200 rpm

A motor rotates at:

1200 rpm

Then:

ω = 1200 × 2π/60

ω = 40π

ω ≈ 126 rad/s

If the motor reaches this speed from rest in 10 s:

α = 126/10

α ≈ 12.6 rad/s²


Clock Hands

Rotational equations can also describe clock hands.

The minute hand completes:

2π rad

in:

3600 s

Its angular velocity magnitude is:

ω = 2π/3600

ω ≈ 1.75 × 10⁻³ rad/s

Because the motion is clockwise, if counterclockwise is positive:

ω ≈ −1.75 × 10⁻³ rad/s

Since the minute hand rotates at nearly constant angular velocity:

α ≈ 0


Gears

For two meshing gears without slipping, the points where the gears touch have the same tangential speed.

Therefore:

r₁ω₁ = r₂ω₂

and for angular acceleration magnitudes:

r₁α₁ = r₂α₂

https://images.openai.com/static-rsc-4/gJrsUkq4xNgw-M0fhvGxs7vB-iVuREE-_OJkpZJ1RbroaRvjfNkrgbLYFZ2_iv1y5s0W2S9mToLO4k60k4zvLwMRyVIlZvt04BxGrXLgOWEVwl1luHhbFGqz3gI9vhGtcympsRG7cl44n7gskw8X071XhTBg06Ho2f7fmyoEwP9BzTjuwc2v3Vv-802HeXYH?purpose=fullsize
 
https://images.openai.com/static-rsc-4/UhLQfsfuOeaC2T8qhL1ztB2TVIcgDYxTR-f9Mqf9X3DvB6nAMw5NqeXllZsjY6n6fa2hDW0R4-PCNOzWjZUBxMgsj__U2j4tbL9FWc6Vza-eSjYyK_r8mWp7JEBQIGXbpUWRaOu5xqLd-rFPyEShK-aj-Ju10muL9BjzkfNjzcW3a_ysK075X2setumcj_3a?purpose=fullsize
 
https://images.openai.com/static-rsc-4/UoNe1Yn_yvhG6FP-81nYEZzg7jgQjkVKR9t8zYRfHs1P5aY3seNPU-Y8rjDky-R8hFfxRa6G98kxBTR-xiR6Soesx9zlJSh1VhmcmGsz-IfxWaVu009kkT-yLKZNBhu674AxXfV05xz7EHA6aaUKwG5aIqQ82krSmmNePOBf3MxqTBd0v9afpSInlAIiXDfo?purpose=fullsize
 
7

A smaller gear rotates faster and usually has a greater angular acceleration magnitude.

Meshing gears also rotate in opposite directions.


Worked Gear Example

Gear A has radius:

r_A = 5 cm

Gear B has radius:

r_B = 20 cm

Gear A accelerates from rest at:

α_A = 12 rad/s²

Then:

r_A α_A = r_B |α_B|

(5)(12) = (20)|α_B|

|α_B| = 3 rad/s²

If Gear A's acceleration is positive:

α_B = −3 rad/s²

because Gear B accelerates rotationally in the opposite direction.


Pulley Systems

Rotating pulleys provide another application.

If a rope does not slip on a pulley:

v = rω

and:

a = rα

Therefore, the motion of the rope can be related directly to the rotation of the pulley.

This becomes important when studying:

  • elevators
  • cranes
  • belt drives
  • mechanical lifting systems

Selecting Equations Efficiently

Suppose a problem gives:

ω_i, ω_f and t

and asks for α.

Use:

α = (ω_f − ω_i)/t

Suppose it gives:

ω_i, α and t

and asks for Δθ.

Use:

Δθ = ω_i t + 1/2 αt²

Suppose it gives:

ω_i, ω_f and α

but no time.

Use:

ω_f² = ω_i² + 2αΔθ

The goal is not to memorize which equation belongs to which question.

Instead:

identify the variables first.


A Useful Variable Table

For longer problems, make a table before calculating.

Variable Value
ω_i ?
ω_f ?
α ?
Δθ ?
t ?

Fill in everything given by the problem.

Then select an equation containing:

  • the required unknown
  • the known quantities
  • no unnecessary unknown

This greatly reduces equation-selection errors.


Multi-Step Problems

Many real problems require more than one equation.

For example:

A wheel starts from rest, accelerates at 4 rad/s² for 5 s, and has radius 0.30 m.

Find its final linear speed.

First find angular velocity:

ω_f = ω_i + αt

ω_f = 0 + (4)(5)

ω_f = 20 rad/s

Then convert to linear speed:

v = rω

v = (0.30)(20)

v = 6.0 m/s

The problem combines rotational kinematics with the angular-linear relationship.


Real-World Applications

Rotational kinematic equations are used in the analysis of:

  • vehicle wheels
  • electric motors
  • turbines
  • wind turbines
  • generators
  • robotic joints
  • gears
  • pulleys
  • flywheels
  • washing machines
  • industrial equipment
  • amusement rides
https://images.openai.com/static-rsc-4/pBmsLcHVWcaDJLSHkiJO5QUdNdFnlsTtwr1L0aoOyS1rrToQg3bNF2YH4ymNEKBNCTbsa14TD52VJHjoYV_s6qAhiX7_tEfm9DWPA1W9hwxuBWfw1wdT0L57T8o_7X-lB-5kPSluaXKioz6SpL9s-7fNH53poGazWYoEsyR_BAfscymht4St0Z8JMXImbXM7?purpose=fullsize
 
https://images.openai.com/static-rsc-4/-Yj3kVbUAN-X-xf9cw9v5fha_JOet_RvwBqp-UCJuJkj7S7xJ6UDhmDPQw2qdg_02_98biMC4JQhyn3HzdV_wh44qnoHoUCbPn_QpKSMC8GbJE5wAGUfNsEGPSmSJgqDIYO_N-WUtGU_RRYWevc66YP63cXWidoSdg5rk9ZD5c7eQKuXe_KwNYN9L8Wr6EPz?purpose=fullsize
 
https://images.openai.com/static-rsc-4/LScXCGEYhWP3taUdeoaZw01fUj17vGq4Rk8B3_iNpsUurnMDaqP_p5h153mBKNQPSFCUiuk1egksyBv2ucArPyX-FttvJpX_Cdlwp_8D-_Fz0CghTQVwf8vis_dtT1y_LW2L-ceGtXSqBroeXEsY6-moeY_cVuPfzcDnI_432rw-LsW1tgZU6vV08vnMiH9h?purpose=fullsize
 
7

Engineers often need to determine how quickly rotating equipment can safely:

  • start
  • stop
  • accelerate
  • reverse direction

Rotational Motion and Safety

A rotating machine cannot usually stop instantly.

Its angular velocity must decrease over time.

Rotational kinematics can determine:

  • stopping time
  • stopping angle
  • number of revolutions before stopping

This information is important when designing:

  • brakes
  • emergency shutdown systems
  • industrial machinery
  • vehicles

A Complete Worked Problem

A wheel initially rotates counterclockwise at:

ω_i = 10 rad/s

It accelerates uniformly at:

α = 4 rad/s²

for:

t = 6 s

The wheel has radius:

r = 0.25 m

Final Angular Velocity

ω_f = ω_i + αt

ω_f = 10 + (4)(6)

ω_f = 34 rad/s

Angular Displacement

Δθ = ω_i t + 1/2 αt²

Δθ = (10)(6) + 1/2(4)(6²)

Δθ = 60 + 72

Δθ = 132 rad

Number of Revolutions

N = 132/(2π)

N ≈ 21.0 revolutions

Final Tangential Speed

v = rω

v = (0.25)(34)

v = 8.5 m/s

Tangential Acceleration

a_t = rα

a_t = (0.25)(4)

a_t = 1.0 m/s²

One problem can therefore connect several rotational quantities.


Checking Your Answer

After solving a rotational problem, ask:

Are the units correct?

  • θ → rad
  • ω → rad/s
  • α → rad/s²
  • t → s

Does the sign make sense?

If an object is slowing while rotating positively, α should be negative.

Is the magnitude reasonable?

A wheel should not suddenly gain thousands of rad/s unless the situation supports such a large acceleration.

Did I use radians where necessary?

Rotational equations normally use radians.

Did I assume constant α?

If the equation requires constant angular acceleration, make sure that assumption is justified.


Common Mistakes

Mixing linear and rotational variables

Do not substitute v where ω is required or a where α is required.

Using degrees instead of radians

Rotational kinematic calculations should generally use radians.

Forgetting direction

Clockwise and counterclockwise quantities may require different signs.

Thinking negative α always means slowing down

Whether the object speeds up or slows down depends on both ω and α.

Using the wrong equation

List the known and unknown variables before choosing an equation.

Forgetting that 1 revolution = 2π rad

Do not treat revolutions and radians as interchangeable numbers.

Using rpm directly as rad/s

Convert before using rotational equations.

Assuming constant angular acceleration when it is not constant

These four main equations require constant α.

Confusing angular displacement with number of revolutions

Convert using:

N = Δθ/(2π)

Forgetting radius when converting to linear quantities

Use:

s = rθ

v = rω

a_t = rα


Key Terms

Rotational kinematics — study of rotational motion without focusing on the forces or torques causing it.

Angular position (θ) — orientation of an object relative to a reference direction.

Angular displacement (Δθ) — change in angular position.

Angular velocity (ω) — rate of change of angular position.

Initial angular velocity (ω_i) — angular velocity at the beginning of an interval.

Final angular velocity (ω_f) — angular velocity at the end of an interval.

Angular acceleration (α) — rate of change of angular velocity.

Constant angular acceleration — motion in which angular velocity changes by equal amounts during equal time intervals.

Radian (rad) — standard angular unit used in rotational equations.

Radian per second (rad/s) — SI unit of angular velocity.

Radian per second squared (rad/s²) — SI unit of angular acceleration.

Revolution — one complete rotation equal to 2π rad.

Tangential speed — linear speed of a point moving along a circular path.

Tangential acceleration — linear acceleration associated with changing angular speed.

Rolling without slipping — motion in which rotation and translation satisfy s = rθ, v = rω and a = rα.


Key Takeaways

  • Rotational kinematics uses angular quantities to describe rotational motion.
  • The main variables are Δθ, ω_i, ω_f, α and t.
  • Rotational equations closely parallel linear kinematic equations.
  • The equations apply directly when angular acceleration is constant.
  • ω_f = ω_i + αt relates angular velocity, acceleration and time.
  • Δθ = ω_i t + 1/2 αt² relates angular displacement to time.
  • ω_f² = ω_i² + 2αΔθ is useful when time is unknown.
  • Δθ = [(ω_i + ω_f)/2]t uses average angular velocity.
  • A good problem-solving method is to identify known and unknown variables before choosing an equation.
  • Direction must be represented consistently using positive and negative signs.
  • Angular displacement is measured in radians.
  • Angular velocity is measured in rad/s.
  • Angular acceleration is measured in rad/s².
  • One revolution equals 2π rad.
  • Rotational quantities connect to linear quantities through s = rθ, v = rω, and a_t = rα.
  • Rolling wheels provide a direct connection between rotational and translational motion.
  • The gradient of an ω-t graph gives angular acceleration.
  • The area under an ω-t graph gives angular displacement.
  • Real-world applications include wheels, motors, turbines, gears, pulleys and robotic systems.
  • Rotational kinematics can predict starting motion, stopping motion and direction reversals.

Check Your Understanding

  1. Identify the symbols and SI units for angular displacement, angular velocity and angular acceleration.
  2. Write the four main rotational kinematic equations for constant angular acceleration.
  3. A wheel starts at ω_i = 5 rad/s and accelerates at 3 rad/s² for 4 s. Calculate its final angular velocity.
  4. For Question 3, calculate the wheel's angular displacement.
  5. A fan starts from rest and accelerates uniformly at 2.5 rad/s² for 8 s. Calculate its final angular velocity and angular displacement.
  6. A disk slows from 40 rad/s to 10 rad/s in 6 s. Calculate its angular acceleration.
  7. A wheel rotating at 30 rad/s slows uniformly at −5 rad/s². Calculate how long it takes to stop.
  8. For Question 7, calculate the angular displacement before the wheel stops and convert it to revolutions.
  9. A motor increases its angular velocity from 10 rad/s to 50 rad/s while rotating through 120 rad. Calculate its angular acceleration.
  10. A wheel accelerates uniformly from 8 rad/s to 24 rad/s in 5 s. Calculate its angular displacement using average angular velocity.
  11. A bicycle wheel has radius 0.35 m and angular velocity 18 rad/s. Calculate the bicycle's linear speed if the wheel rolls without slipping.
  12. A car accelerates at 3.0 m/s². Its wheels have radius 0.30 m. Calculate their angular acceleration.
  13. A wheel initially rotates counterclockwise at +18 rad/s and experiences constant angular acceleration −6 rad/s². Determine when it stops and describe its motion after that time if the acceleration continues.
  14. An ω-t graph rises uniformly from 4 rad/s at t = 0 to 28 rad/s at t = 6 s. Determine the angular acceleration and angular displacement during the six seconds.
  15. A rotating amusement ride starts from rest, reaches 12 rad/s in 8 s, and has radius 5 m. Assuming constant angular acceleration, calculate its angular acceleration, angular displacement, number of revolutions, and the final tangential speed of a rider at the outer edge.


5. Linear and Angular Relationships

Learning outcomes
  • I can relate linear and angular displacement.
  • I can relate tangential velocity to angular velocity.
  • I can calculate centripetal acceleration from angular quantities.
  • I can explain how rotational motion produces linear motion.
  • I can solve problems involving rotating systems.

Key Topics:
  • Engineering and design of structures.
  • Applications in robotics and machinery.

Linear and Angular Relationships

Rotational motion and linear motion are closely connected. When an object rotates, points on the object move along circular paths. Their motion can therefore be described using both angular quantities and linear quantities.

The most important relationships are:

s = rθ

v = rω

a_t = rα

a_c = rω²

where:

  • s = distance travelled along the circular path
  • r = radius
  • θ = angular displacement in radians
  • v = tangential or linear speed
  • ω = angular velocity
  • a_t = tangential acceleration
  • α = angular acceleration
  • a_c = centripetal acceleration

These equations allow us to move between rotational and linear descriptions of the same motion.

https://images.openai.com/static-rsc-4/xpp-DfeAppUYRQ7FQkr3eQSUd_IdvYywdD7w1YNdqH41ftg1iO09w85kYsb0KLSoghuT4qefzSQQUD7t5vmqR8f4hLonvAY-12IPUWVRHDj-Z_TE5VHQVy27AoM2ySmvHzXgpcDfM03C6ltI1eKGArmvFp7A2pbYsUpBYKLGvda79cXKecOByq74OSTaLLhs?purpose=fullsize
 
https://images.openai.com/static-rsc-4/1pHYCciIA6OfjEJ2_hxJAChn5NJ3TXmR8Qg5J6OtmRd7Dupee6hsuR5h2V1N6N4LHhKArZ-dgMChmgjFKcZO-dBodO6v165fyd0j0PtUIFO3iDYwzGKiNoUPetr5-QSxQCEdgYC72huNP9lrtH0JeA1xGWwb45Es4RjKoDSs19Zj8k6cO_U2L0vvk_4rErDn?purpose=fullsize
 
https://images.openai.com/static-rsc-4/JZ3Jxc6hN-m1ToGy_M6jdM4C2OoZbA1NBgvtrQlna9t4Bo2CoW4hozLt0CGKf8SJm1FW3ik-aUUprmFI_b5BTuvpS0NBV0KwIC4u6IXcVJgvn7nBJB4XkaJTpLHb-Tjqv42CvJuI3VTsR_jqLpVydg1foIde7-8uK62Ump7RynmRIdkIoDd1_D7EV-NHpLkj?purpose=fullsize
 
7

Angular Displacement and Linear Distance

Consider a point on a rotating wheel.

As the wheel rotates through an angular displacement θ, the point travels along a circular arc.

The length of this arc is:

s = rθ

This equation connects angular displacement to linear distance.

It applies when:

θ is measured in radians.


Understanding s = rθ

Suppose a wheel has radius:

r = 0.50 m

and rotates through:

θ = 2 rad

Then:

s = rθ

s = (0.50)(2)

s = 1.0 m

A point on the edge of the wheel travels 1.0 m along its circular path.


Why Radius Matters

Consider two points on the same rotating disk.

Point A is:

0.10 m

from the centre.

Point B is:

0.40 m

from the centre.

The disk rotates through:

θ = 3 rad

For Point A:

s_A = rθ

s_A = (0.10)(3)

s_A = 0.30 m

For Point B:

s_B = (0.40)(3)

s_B = 1.20 m

Both points experience the same angular displacement, but Point B travels four times farther.

https://images.openai.com/static-rsc-4/QmbqgFDR9KvyE5472nsQNWznyZrTgyu-FuNki364bOXuVk8c0LJsE5iTniBNPrsp8xDShUKF1so-TzTT32I4dkyirW9_MVp4-9bAlSu66DgS2dumswrm46C1s0rWpgram-c7GKt_zDQK-pgmdm1TPNqs2hPTjAHgVGMpGwO059GWDIA2mxNHVQ_CmCXTx-dD?purpose=fullsize
 
https://images.openai.com/static-rsc-4/U8U9cT2vpJzFaw-02YW0lPMn-i-gF_jmJPVITsK_-f6glQ1Y83r3rmwslxftdh9LOsKBPRjj3iIw5i264xyhiOB-QEq9WlzuAw7rvFKFn3qYf9TqxCui3rYua__LJydrRPy7iQGcT6Sl2Pb-XLFcis9_b9CxFsRab_dbnzZX07S_F-klRBwhu0dyYJbRZeAW?purpose=fullsize
 
https://images.openai.com/static-rsc-4/b0RRs8WV1y-KNPijwOmBaqkMDmTgKWtlZCGCv2nnqDKqWXTqlsFBo88Q4g0O99_Hx3dX0M7y2qoMSf1yReykITFauzsi8-8GPMyl613Nk3E9SH5FsCFKmE1YRRWTK0cGee47I9GcljGrhez9H5OeuH6cxtKDK9G9jgrA4uBkMFY0Oplvv-uaQuFA5BFZTleU?purpose=fullsize
 
7

Same Angle, Different Distance

Every point on a rigid rotating object rotates through the same angular displacement.

However:

s = rθ

Therefore, the farther a point is from the axis:

the greater its linear distance travelled.

For the same θ:

s ∝ r

A point twice as far from the centre travels twice the distance.


Finding Angular Displacement

The relationship can be rearranged:

θ = s/r

Suppose a point on the edge of a wheel travels:

s = 4.5 m

and the wheel has radius:

r = 0.30 m

Then:

θ = 4.5/0.30

θ = 15 rad

Number of revolutions:

N = θ/(2π)

N = 15/(2π)

N ≈ 2.39 revolutions


Degrees Must Be Converted to Radians

The equation:

s = rθ

requires θ to be measured in radians.

Suppose a wheel of radius 0.40 m rotates through:

90°

First convert:

90° = π/2 rad

Then:

s = (0.40)(π/2)

s ≈ 0.628 m

Using 90 directly in the equation would give an incorrect answer.


Angular Velocity and Tangential Velocity

Angular velocity describes how quickly an object's angular position changes.

Tangential velocity describes how quickly a point moves along its circular path.

They are related by:

v = rω

This relationship comes directly from:

s = rθ

Divide both sides by time:

s/t = r(θ/t)

Since:

v = s/t

and:

ω = θ/t

then:

v = rω

https://images.openai.com/static-rsc-4/1pHYCciIA6OfjEJ2_hxJAChn5NJ3TXmR8Qg5J6OtmRd7Dupee6hsuR5h2V1N6N4LHhKArZ-dgMChmgjFKcZO-dBodO6v165fyd0j0PtUIFO3iDYwzGKiNoUPetr5-QSxQCEdgYC72huNP9lrtH0JeA1xGWwb45Es4RjKoDSs19Zj8k6cO_U2L0vvk_4rErDn?purpose=fullsize
 
https://images.openai.com/static-rsc-4/wesOS_8W_nCT0S9kOLJVHzj0Tlgjxp8nS85x9HWzsKdk7EuGsKucMLEiVdLRBaYRu1aDEKMUFkTtBwrH8a3JO-Dq8AtsoeYJv0QHaiU3nfDN65Ew26i4VW0_eS3-advLxSDd1jB78FrOH8Kz3rnk1dpUDoo0mXp2zM-_HYzpu-cUoXG73cFaW0sqC7W-OnKA?purpose=fullsize
 
https://images.openai.com/static-rsc-4/LRayyxK_E9nV3ZakjNXTgpWNZQSk0fzgwmJLaNpGL-JthbK_m9q4UVkdbBTdfrnpTqEHUgTXsXIFjA4dNUI1TME1rzGinP5idfdD1KlktGPTsoboaNm_BzJ057GakDZaZ_kYWLNa2stqzTtZeWfk6_vV6B84noMBUancD2yH99ebkgeDj89_iS--SrXcygbj?purpose=fullsize
 
8

Direction of Tangential Velocity

The instantaneous linear velocity of a point moving in a circle is directed:

tangent to the circular path

It is not directed toward the centre.

At every moment:

  • the radius points from the centre to the object
  • tangential velocity is perpendicular to the radius

The direction of the velocity continually changes as the object rotates.


Same Angular Velocity, Different Linear Velocity

Every point on a rigid rotating object has the same angular velocity.

However:

v = rω

so linear speed increases with radius.

Suppose a disk rotates at:

ω = 8 rad/s

Point A:

r_A = 0.20 m

Point B:

r_B = 0.50 m

For Point A:

v_A = (0.20)(8)

v_A = 1.6 m/s

For Point B:

v_B = (0.50)(8)

v_B = 4.0 m/s

The outer point moves faster.


What Happens at the Axis?

At the axis:

r = 0

Therefore:

v = rω

v = 0

A point exactly on the rotation axis has:

zero tangential speed

even though the object itself may have a large angular velocity.

This illustrates the difference between angular and linear motion.


Angular Velocity from Linear Velocity

The equation can be rearranged:

ω = v/r

Suppose a point moves around a circular path at:

v = 12 m/s

with radius:

r = 0.60 m

Then:

ω = 12/0.60

ω = 20 rad/s


Frequency and Linear Speed

Angular velocity can also be related to frequency:

ω = 2πf

Combining this with:

v = rω

gives:

v = 2πrf

This makes sense because:

2πr

is the circumference of the circle.

If an object completes f revolutions each second, it travels f circumferences each second.


Worked Example: Rotating Platform

A platform has radius:

r = 2.0 m

and rotates at:

f = 0.50 Hz

Angular velocity:

ω = 2πf

ω = 2π(0.50)

ω = π rad/s

A person at the outer edge has tangential speed:

v = rω

v = (2.0)(π)

v ≈ 6.28 m/s

A person halfway from the centre at r = 1.0 m has:

v = (1.0)(π)

v ≈ 3.14 m/s

Both people have the same angular velocity but different tangential speeds.


Period and Linear Speed

Since:

ω = 2π/T

and:

v = rω

we can write:

v = 2πr/T

This is another way to calculate the speed of an object undergoing uniform circular motion.


Worked Example

A point travels in a circle of radius:

r = 3.0 m

and completes one revolution every:

T = 4.0 s

Then:

v = 2πr/T

v = 2π(3.0)/4.0

v ≈ 4.71 m/s


Angular Acceleration and Tangential Acceleration

If angular velocity changes, the tangential velocity of points on the rotating object also changes.

The relationship is:

a_t = rα

This is the acceleration equivalent of:

v = rω

https://images.openai.com/static-rsc-4/5FjVU-YXr-iKfc2LhD9dPPlFWC8Xi1cTiM3w3aF7Xvil9i91mG1lcHm8K5rGtMojmnAetL3lgvmE4TWZN3qmJMWhrcg2cEOqFCsBbgU4oLAou0Yw0CMs20mgNaFDrDd_tupUKnYFKSnUvndEIHBKnhPsXOnApR0JazCmCsRy_2yTCLElsoC1bDXJiHoYRskA?purpose=fullsize
 
https://images.openai.com/static-rsc-4/NvA-vDy1t6qcahxAT6s70wKPKXWEkz2GdOi-oUiAgajOa_HT26aK1jMp4x9LrnxQ3EiMYweyPq6dCtDYclxjv7f9-i2SmsUKM3zhKv_PFez39u_R7yVibagfkbUvOM2ssvXD8E0nP-Aw1HvQehVa45osmxh1uAZLTjJ9gnFY7pxw0Hu6F_mJmfjkM8LJa7ME?purpose=fullsize
 
https://images.openai.com/static-rsc-4/sGJ2gl63VbrCivf32ANEFq_rzZqidsW7sXdRIYHFvT3Bhg0AxU6ZAUX9UKMFLlGzTGjcMP-jhhzhpP8dYYIZYVsKVV7FBv_tjjMpKdaeu1OCT4tySWWumU9stIkXYy9KFduQkwF2UtGEH0e_AQ88DhfT6AHb-mJK2Tyvdztq3mlZiPCmpPSpOmKwr5pGMyII?purpose=fullsize
 
8

Worked Example

A wheel has radius:

r = 0.40 m

and angular acceleration:

α = 5 rad/s²

The tangential acceleration at its edge is:

a_t = rα

a_t = (0.40)(5)

a_t = 2.0 m/s²


Same Angular Acceleration, Different Tangential Acceleration

All points on a rigid rotating body have the same angular acceleration.

However:

a_t = rα

Therefore, points farther from the axis experience greater tangential acceleration.

For example, if:

α = 4 rad/s²

then:

Radius Tangential Acceleration
0.10 m 0.40 m/s²
0.20 m 0.80 m/s²
0.50 m 2.0 m/s²
1.00 m 4.0 m/s²

Tangential acceleration increases directly with radius.


Centripetal Acceleration

Even if angular velocity is constant, a point moving in a circle is accelerating.

Why?

Because its velocity direction is continuously changing.

This inward acceleration is called centripetal acceleration.

The familiar linear equation is:

a_c = v²/r

Centripetal acceleration always points:

toward the centre of the circular path.

https://images.openai.com/static-rsc-4/Qsyw-UcogpZ-TczQ5QdA_CxZeb38PRTIgyvyy8yOaXE3roAK3trVg7TbLlGcjT1FIHkpGVyz0bQtOsrIMgHhQQmyMkt9-GXuMmo7LGF0962y-UCib9h3J3beduvpRH_25LUdOcQbP3wD6GGEfAowCsGq05XlL6BUJUvhODfjnHsuvaiTdmHqVnTts1T6TPDE?purpose=fullsize
 
https://images.openai.com/static-rsc-4/oHMYGzNXv8EL1VIrIi1GuF5NIXFrnOucrnnraEEV0atvOfF7SM4q-lFS_OTCa0n6D7-ezMU7r6EgpSJK1an8Yt5Oq6tq5fE8yhPXrRs9U9FJkIbBk0_Da0YfxAL0Qsu7i-uC6dJL-T0aHfqbyxV1Q51cfSEnFNHgbaGiKx1O5wVFkZ5_YuXAoZnk5FzvkdBS?purpose=fullsize
 
https://images.openai.com/static-rsc-4/CfWL9xC5ZfW_MmkqMuP9IqkdDxAUYr_V33U-_OvLLIOR6XvT6gu8SGSttFfsiAts1RFKN5lTMoKV7EiQtCtq-JwZ13fiNCzcQmDUK43Fc9kiikqoNZhS6shvPGlDH6NdLhJcnMWbHQcxxqtMwNITSRUD4PLvZ8rSP7mYIu5GbOw22zZNp_i2FG1zT9Dpt_Yy?purpose=fullsize
 
8

Centripetal Acceleration Using Angular Velocity

Since:

v = rω

substitute into:

a_c = v²/r

Then:

a_c = (rω)²/r

a_c = r²ω²/r

Therefore:

a_c = rω²

This is one of the most important connections between angular and linear motion.


Worked Example

A point is:

r = 0.50 m

from the centre of a disk rotating at:

ω = 6 rad/s

Then:

a_c = rω²

a_c = (0.50)(6²)

a_c = (0.50)(36)

a_c = 18 m/s²


The Effect of Angular Velocity

Centripetal acceleration depends on:

ω²

Therefore:

a_c ∝ ω²

If angular velocity doubles:

a_c becomes four times larger.

If angular velocity triples:

a_c becomes nine times larger.

This makes high-speed rotation capable of producing very large accelerations.


Example: Doubling Angular Velocity

Suppose:

r = 0.40 m

ω = 5 rad/s

Then:

a_c = (0.40)(5²)

a_c = 10 m/s²

Now double the angular velocity:

ω = 10 rad/s

a_c = (0.40)(10²)

a_c = 40 m/s²

Doubling ω increased centripetal acceleration by a factor of four.


The Effect of Radius

For the same angular velocity:

a_c = rω²

Therefore:

a_c ∝ r

A point twice as far from the axis experiences twice the centripetal acceleration if both points share the same angular velocity.

This may initially seem different from:

a_c = v²/r

but remember that for a rigid rotating object:

v increases with radius.


Tangential and Centripetal Acceleration

When a rotating object's angular speed changes, a point on it can have two acceleration components.

Tangential acceleration:

a_t = rα

This changes the magnitude of the velocity.

Centripetal acceleration:

a_c = rω²

This changes the direction of the velocity.

https://images.openai.com/static-rsc-4/Tcw5Hnv0TmlFHGCGH5DS7uf2aDzCWY0dsUNfiiRmeritq4POcDqoPrlB6uW7VVSIx07l8fWKr12d51EcajSmRWEIg44a5b0RmvPcRtPKlUS1pqBo88SBdaoedvDec44WO7gA1CRvEoMoyXYDmPa2OJpawAnBT6sbGNslDDBUY1lN-OIkZvCBWld6pcj96uSl?purpose=fullsize
 
https://images.openai.com/static-rsc-4/oXHzYDi0EkMWmRKLDNuMIyjpu5XCHCCDxrV_dvu7cOSWIQQ59WEiPDwQHh8mH00JDo3IVOEwkP-d48II34dTShS9RA2e6W4BlJFVEQTW0z--UnSLm_YNsBlIEhDvcVqTFVEQSYH1EBwnEonNwgU-f8SAnwx1TXIKBp7lNWDZ6U-9qTW1LP_LczWFgSG2rdZM?purpose=fullsize
 
https://images.openai.com/static-rsc-4/NvA-vDy1t6qcahxAT6s70wKPKXWEkz2GdOi-oUiAgajOa_HT26aK1jMp4x9LrnxQ3EiMYweyPq6dCtDYclxjv7f9-i2SmsUKM3zhKv_PFez39u_R7yVibagfkbUvOM2ssvXD8E0nP-Aw1HvQehVa45osmxh1uAZLTjJ9gnFY7pxw0Hu6F_mJmfjkM8LJa7ME?purpose=fullsize
 
8

These accelerations are perpendicular to each other.


Total Acceleration

If both tangential and centripetal acceleration are present:

a_total = √(a_t² + a_c²)

because the two acceleration components are perpendicular.


Worked Example

A point is:

r = 0.30 m

from the axis of rotation.

At one instant:

ω = 8 rad/s

and:

α = 5 rad/s²

Tangential acceleration:

a_t = rα

a_t = (0.30)(5)

a_t = 1.5 m/s²

Centripetal acceleration:

a_c = rω²

a_c = (0.30)(8²)

a_c = 19.2 m/s²

Total acceleration:

a_total = √(1.5² + 19.2²)

a_total ≈ 19.3 m/s²

Notice that the centripetal acceleration is much larger in this example.


Constant Angular Velocity

If:

ω = constant

then:

α = 0

Therefore:

a_t = rα = 0

However:

a_c = rω²

is still present.

So an object moving in a circle at constant speed still accelerates because the direction of its velocity changes.


Rotational Motion Producing Linear Motion

Many machines convert rotational motion into linear motion.

Examples include:

  • wheels moving vehicles
  • pulleys lifting loads
  • gears driving machinery
  • winches pulling cables
  • conveyor-belt rollers
  • rack-and-pinion steering
  • screws and threaded mechanisms
https://images.openai.com/static-rsc-4/gC2pH2yaG5aA85LZZUELpFY3O2l0F087Dv8XAGesNsC3DRXVkSkjNqZ6LFbIuEyuEmrOv2ahQfClW8NrAJz2_YrDyW2On1JcMaV1bLcFGXUJ5WUgNOXiRpnBUe9ukoL5T69s8O18R4AfruHIvLUoT3FA9YbN72oq8-6MzusZvOoGBE0WMztcnKFadV8A6l4e?purpose=fullsize
 
https://images.openai.com/static-rsc-4/Tw59T-vngkwNmHqs2KFK84mfq_JxkvxXXid-rK6PoB6YtOPLLCvQGd_fYw6sflR69wywJioRiNWUSjQjPpJqX7GhjxIm-nSWw7nikl-FQZDxH59e0b2-S_UhhkJ5464vzGEaG1_a9CdUeBKEdSfIeDXvQyqzWhhoj8imeFg3ADGsIxA-YxGrW-yJJzOViRf_?purpose=fullsize
 
https://images.openai.com/static-rsc-4/Hz81s_htDmZqliA4cq3ospjevGL2aDm7VANl_3gx8UwoVMhhQu9KDsZiBeF4W7XMqefRv7zfJ42Tc3uVdnln-2xQTb3M7BFMAOYt4n24jqnTIAtll9zgWoubo048O5c_YnsTW_TTfeP-ZqsQeHcQHbpkblMlSidNe9XZmKgOcqJlzkRJ8quXOJsK27gJhbt5?purpose=fullsize
 
7

The relationships:

s = rθ

v = rω

a = rα

allow us to calculate the resulting linear motion.


Rolling Without Slipping

A wheel rolling along a surface combines:

  • rotational motion around its centre
  • linear motion of its centre

If the wheel rolls without slipping:

s = rθ

v = rω

a = rα

where v and a describe the linear motion of the wheel's centre.


Worked Example: Bicycle Wheel

A bicycle wheel has radius:

r = 0.35 m

and rotates at:

ω = 20 rad/s

The bicycle's speed is:

v = rω

v = (0.35)(20)

v = 7.0 m/s

Convert to km/h:

7.0 × 3.6

v = 25.2 km/h


Distance from Wheel Rotation

Suppose the same bicycle wheel rotates through:

θ = 100 rad

Then:

s = rθ

s = (0.35)(100)

s = 35 m

If there is no slipping, the bicycle moves forward 35 m.


Number of Wheel Revolutions

Since:

1 revolution = 2π rad

the circumference of a wheel is:

2πr

After one revolution:

θ = 2π

so:

s = r(2π)

s = 2πr

This shows why the familiar circumference formula is consistent with:

s = rθ


Worked Vehicle Problem

A car wheel has radius:

0.32 m

The car travels:

100 m

without slipping.

Find the angular displacement of the wheel.

θ = s/r

θ = 100/0.32

θ = 312.5 rad

Number of revolutions:

N = 312.5/(2π)

N ≈ 49.7 revolutions


Vehicle Acceleration

Suppose a car accelerates at:

3.0 m/s²

and its wheel radius is:

0.30 m

For rolling without slipping:

a = rα

Therefore:

α = a/r

α = 3.0/0.30

α = 10 rad/s²


A Complete Wheel Problem

A bicycle wheel has radius:

r = 0.40 m

It starts from rest and accelerates at:

α = 3 rad/s²

for:

t = 5 s

Final Angular Velocity

ω_f = ω_i + αt

ω_f = 0 + (3)(5)

ω_f = 15 rad/s

Final Linear Speed

v = rω

v = (0.40)(15)

v = 6.0 m/s

Angular Displacement

Δθ = 1/2 αt²

Δθ = 1/2(3)(5²)

Δθ = 37.5 rad

Linear Distance

s = rθ

s = (0.40)(37.5)

s = 15 m

Tangential Acceleration

a_t = rα

a_t = (0.40)(3)

a_t = 1.2 m/s²

Final Centripetal Acceleration

a_c = rω²

a_c = (0.40)(15²)

a_c = 90 m/s²

This single example connects rotational kinematics to linear motion.


Pulleys

A rotating pulley can produce linear motion in a rope or cable.

If the rope does not slip:

s = rθ

v = rω

a = rα

https://images.openai.com/static-rsc-4/BgUIFja0FzVhTgwiHT8ihNRObitK1Rei_7Zh3UWxpU52tbttmZK2GuREb3hcJfBMT354__KTSTbRZzAaQKLrM_E8nRu-saJ6EvWJDRRcy8qmV_lSU0S6quRnA_mB3qo6Db1QFrKrn0sJAzHzHzcfwW1n9ualyUwtNuiVrI2tpjAVUrRPpeEJTpjRvnMTMKSS?purpose=fullsize
 

Worked Pulley Example

A pulley has radius:

r = 0.20 m

and rotates at:

ω = 15 rad/s

The rope moves at:

v = rω

v = (0.20)(15)

v = 3.0 m/s

If:

α = 4 rad/s²

then the rope's acceleration is:

a = rα

a = (0.20)(4)

a = 0.80 m/s²


Winches

A winch uses a rotating drum to wind or unwind a cable.

Suppose a winch drum has radius:

0.25 m

and rotates through:

20 rad

The cable moves:

s = rθ

s = (0.25)(20)

s = 5.0 m

If the drum rotates at:

8 rad/s

the cable speed is:

v = rω

v = (0.25)(8)

v = 2.0 m/s


Gears

Meshing gears connect rotational motion between objects.

At their contact point, the tangential speeds must be equal if there is no slipping.

Therefore:

v₁ = v₂

Since:

v = rω

then:

r₁ω₁ = r₂ω₂

https://images.openai.com/static-rsc-4/cPZEZJz10TV6-Q0qr_8I7mRPS1MWGoGvJ-MNMPJz8ceomL1PaCcI7J6Kq62H-P6dzMHQq1WDjjKiYqiCvBc8vcT3Kv7GAwFN2VTe0Db_iAVf2xFC4f4K-RpFX9d66t1qi-x58rO5BcXdFKpQ0H7yZyN_h4PQx2LTYkO0k7-3sSU6Zi6ldVtXNU__D-rsR5Yb?purpose=fullsize
 
https://images.openai.com/static-rsc-4/MkKMKrY6Ftk1CSV-PV43nd9rDLAUuZumCwMJ1RMP_GBj8fGuzObb_ooQMq4-3vnj1p4d0OkzTVGN7SLAH2xqLhj8TAl2Stc_a98onT7EgIntNzfQNNGVPeD7dRt8nMUFgcx6Zc3qcFtlmM7ZCcS2K1nxgC6JJh6FxkcGUFEo9RJjw0w-ESfiGSTLkDxzam9e?purpose=fullsize
 
https://images.openai.com/static-rsc-4/KjFVMH3dx-qRcdL5FofnUj897npUHlx5GcPAYddt8Mrt9vUIoXvAp2pv93dQ_UjS5HlgjcOlM8WG5COPWNVYJu36sMn2ZE_WnVbjf0RKosv4LhYES_Wdqg7FwAnuQWS885CIKy5vOzn8Ey3QpEAzQwXIDkSp9KzZLZpMc_LvzNJgLI67NTkunrvTkvMric7b?purpose=fullsize
 
8

Worked Gear Example

Gear A has radius:

r_A = 5 cm

and rotates at:

ω_A = 24 rad/s

Gear B has radius:

r_B = 15 cm

Then:

r_A ω_A = r_B |ω_B|

(5)(24) = (15)|ω_B|

|ω_B| = 8 rad/s

The gears rotate in opposite directions.

If:

ω_A = +24 rad/s

then:

ω_B = −8 rad/s


Gear Ratios

From:

r₁ω₁ = r₂ω₂

we obtain:

ω₂/ω₁ = r₁/r₂

Therefore:

  • smaller gears rotate faster
  • larger gears rotate slower

A small driving gear connected to a larger gear reduces angular speed.

A large driving gear connected to a smaller gear increases angular speed.

This principle is used in:

  • bicycles
  • cars
  • clocks
  • industrial machines
  • mechanical transmissions

Belt-Driven Systems

Two pulleys connected by a belt behave similarly.

If the belt does not slip:

r₁ω₁ = r₂ω₂

because both pulley edges move at the same linear speed as the belt.

Unlike directly meshing gears, an uncrossed belt usually causes both pulleys to rotate in the same direction.


Conveyor Belts

A rotating roller can drive a conveyor belt.

Suppose a roller has:

r = 0.15 m

ω = 10 rad/s

Then:

v = rω

v = (0.15)(10)

v = 1.5 m/s

The conveyor belt moves at approximately 1.5 m/s if there is no slipping.


Rotational Motion in Motors

Electric motors produce rotational motion.

That rotation can be converted into linear motion through:

  • wheels
  • gears
  • pulleys
  • belts
  • screws
  • rack-and-pinion systems

For example, a motor rotating a wheel can propel a robot forward.

The motor's angular velocity determines the wheel's linear speed through:

v = rω


Robot Wheel Example

A robot has wheels of radius:

0.08 m

Each wheel rotates at:

25 rad/s

Then:

v = rω

v = (0.08)(25)

v = 2.0 m/s

If the motor increases angular velocity at:

α = 10 rad/s²

then:

a = rα

a = (0.08)(10)

a = 0.80 m/s²

assuming rolling without slipping.


Ferris Wheel Example

A Ferris wheel has radius:

r = 15 m

and rotates with angular velocity:

ω = 0.10 rad/s

Every passenger has the same angular velocity.

However, because passengers are all approximately the same distance from the axis, they also have approximately the same tangential speed:

v = rω

v = (15)(0.10)

v = 1.5 m/s

Their centripetal acceleration is:

a_c = rω²

a_c = (15)(0.10²)

a_c = 0.15 m/s²

https://images.openai.com/static-rsc-4/NvA-vDy1t6qcahxAT6s70wKPKXWEkz2GdOi-oUiAgajOa_HT26aK1jMp4x9LrnxQ3EiMYweyPq6dCtDYclxjv7f9-i2SmsUKM3zhKv_PFez39u_R7yVibagfkbUvOM2ssvXD8E0nP-Aw1HvQehVa45osmxh1uAZLTjJ9gnFY7pxw0Hu6F_mJmfjkM8LJa7ME?purpose=fullsize
 
https://images.openai.com/static-rsc-4/c_azf9Y2oEi6TrMsQCp9_FEiDC44LGbokZbyD_ENVUAfPlEh6J3MM6SgZmL4B-eHaM-5Q41a8-g7Fx8BoTQYmrOWaIQ5JFxP2MIUnki_B4ddEUt0jUSS0UD5pD32DUmt2xr_p4T4xMowes51JZoyKIcA09dSTSKLlKbQgJnfnLqyiZHBnrZWv-jYqXQH1pN5?purpose=fullsize
 
https://images.openai.com/static-rsc-4/IaZ9HG0RDr6XJ550Crlrp-3JqQurD7Kn_PDP-hxqmPMCeaYdY1zCz13W1LglXjSjSX1R2Ot7BbczURnUsvcXE-FZ4ePqsRGstvqDwuOS7P-eDKeLVfnCB-jUuIgTtsueUg2uxmuoirigjatcVzaH5TG3qTyrP8MU6wPuVX9MW58MOWNhimbdRD1QEcLuT8Zb?purpose=fullsize
 
5

Rotating Platform Example

A rotating platform has angular velocity:

ω = 2 rad/s

Person A stands:

1 m

from the centre.

Person B stands:

3 m

from the centre.

Angular Velocity

Both have:

ω = 2 rad/s

Tangential Speed

Person A:

v_A = (1)(2)

v_A = 2 m/s

Person B:

v_B = (3)(2)

v_B = 6 m/s

Centripetal Acceleration

Person A:

a_c = (1)(2²)

a_c = 4 m/s²

Person B:

a_c = (3)(2²)

a_c = 12 m/s²

The person farther from the centre experiences greater tangential speed and greater centripetal acceleration.


Centripetal Force

Centripetal acceleration requires a net inward force.

Newton's Second Law gives:

F_c = ma_c

Using:

a_c = rω²

gives:

F_c = mrω²

This force is not a new type of force.

"Centripetal force" means the net inward force provided by forces such as:

  • friction
  • tension
  • gravity
  • normal force

For example, friction between tires and a road can provide the centripetal force needed for a car to turn.


Comparing Two Ways to Calculate Centripetal Acceleration

Centripetal acceleration can be calculated using:

a_c = v²/r

or:

a_c = rω²

Use whichever equation matches the information provided.

If v is known:

a_c = v²/r

If ω is known:

a_c = rω²

Both describe exactly the same physical acceleration.


Worked Example Using Both Methods

A point moves in a circle of radius:

r = 2.0 m

with:

ω = 3.0 rad/s

First find linear speed:

v = rω

v = (2.0)(3.0)

v = 6.0 m/s

Using angular quantities:

a_c = rω²

a_c = (2.0)(3.0²)

a_c = 18 m/s²

Using linear quantities:

a_c = v²/r

a_c = 6.0²/2.0

a_c = 18 m/s²

Both methods give the same answer.


Rotational and Linear Quantity Pairs

The major relationships can be summarized as:

Angular Quantity Linear Quantity Relationship
Angular displacement θ Arc length s s = rθ
Angular velocity ω Tangential velocity v v = rω
Angular acceleration α Tangential acceleration a_t a_t = rα
Angular velocity ω Centripetal acceleration a_c a_c = rω²

The radius connects the rotational description to the linear description.


The Importance of Radius

Radius plays a central role because points farther from the axis must travel farther during the same rotation.

For a fixed θ:

s ∝ r

For a fixed ω:

v ∝ r

For a fixed α:

a_t ∝ r

For a fixed ω:

a_c ∝ r

Therefore, even though every point on a rigid object shares the same angular motion, its linear motion depends strongly on its distance from the axis.


A Complete Rotating-System Problem

A rotating disk has radius:

r = 0.60 m

It starts from rest and accelerates uniformly at:

α = 4 rad/s²

for:

t = 3 s

Angular Velocity

ω = αt

ω = (4)(3)

ω = 12 rad/s

Angular Displacement

θ = 1/2 αt²

θ = 1/2(4)(3²)

θ = 18 rad

Distance Travelled at the Edge

s = rθ

s = (0.60)(18)

s = 10.8 m

Tangential Speed

v = rω

v = (0.60)(12)

v = 7.2 m/s

Tangential Acceleration

a_t = rα

a_t = (0.60)(4)

a_t = 2.4 m/s²

Centripetal Acceleration

a_c = rω²

a_c = (0.60)(12²)

a_c = 86.4 m/s²

Total Acceleration

a_total = √(a_t² + a_c²)

a_total = √(2.4² + 86.4²)

a_total ≈ 86.4 m/s²

At high angular speeds, centripetal acceleration can become much larger than tangential acceleration.


A Strategy for Rotating-System Problems

First identify the rotational quantities:

  • θ
  • ω
  • α
  • t

Then identify the radius:

r

If necessary, use rotational kinematics to find the missing angular quantity.

Then convert to the required linear quantity.

Use:

s = rθ

for distance.

Use:

v = rω

for tangential speed.

Use:

a_t = rα

for tangential acceleration.

Use:

a_c = rω²

for centripetal acceleration.

Finally, check that the units and physical interpretation make sense.


Common Mistakes

Confusing angular and linear quantities

Angular velocity is measured in rad/s, while linear velocity is measured in m/s.

Thinking all points on a rotating object have the same linear speed

They have the same angular velocity, but their linear speeds depend on radius.

Using degrees in s = rθ

θ must be in radians.

Forgetting radius

The radius is what connects angular quantities to linear quantities.

Using a_t and a_c as though they were the same acceleration

Tangential acceleration changes speed. Centripetal acceleration changes direction.

Thinking constant angular velocity means zero acceleration

Tangential acceleration is zero, but centripetal acceleration is still present.

Thinking centripetal acceleration points along the motion

It points toward the centre.

Thinking centripetal force is a separate type of force

It is the name given to the net inward force responsible for circular motion.

Using v = rω when slipping occurs

The rolling relationship between wheel rotation and vehicle motion assumes rolling without slipping.

Forgetting that ω is squared in a_c = rω²

Doubling angular velocity makes centripetal acceleration four times larger.


Key Terms

Linear displacement — change in position measured along a linear path.

Angular displacement (θ) — amount through which an object rotates.

Arc length (s) — distance measured along a circular path.

Radius (r) — distance from the axis of rotation to a point.

Angular velocity (ω) — rate of change of angular position.

Tangential velocity (v) — instantaneous linear velocity of a point moving along a circular path.

Angular acceleration (α) — rate of change of angular velocity.

Tangential acceleration (a_t) — acceleration that changes the magnitude of tangential velocity.

Centripetal acceleration (a_c) — inward acceleration that changes the direction of velocity.

Centripetal force — net inward force responsible for centripetal acceleration.

Rolling without slipping — motion in which wheel rotation and forward translation are directly related.

Rigid body — object in which points maintain fixed positions relative to one another.

Axis of rotation — line around which an object rotates.

Frequency (f) — number of complete rotations per second.

Period (T) — time required for one complete rotation.


Key Takeaways

  • Linear and angular motion describe different aspects of the same rotating system.
  • Angular displacement and linear distance are related by s = rθ.
  • Angular displacement must be measured in radians when using s = rθ.
  • Angular velocity and tangential velocity are related by v = rω.
  • Angular acceleration and tangential acceleration are related by a_t = rα.
  • Centripetal acceleration can be calculated using a_c = rω².
  • Centripetal acceleration can also be calculated using a_c = v²/r.
  • All points on a rigid rotating object have the same angular displacement.
  • All points on a rigid rotating object have the same angular velocity.
  • All points on a rigid rotating object have the same angular acceleration.
  • Linear distance, tangential speed and tangential acceleration depend on radius.
  • Points farther from the rotation axis travel farther and move faster for the same angular motion.
  • Centripetal acceleration points toward the centre of rotation.
  • Tangential velocity points tangent to the circular path.
  • Tangential acceleration and centripetal acceleration are perpendicular.
  • For rolling without slipping, s = rθ, v = rω, and a = rα connect wheel rotation with vehicle motion.
  • Rotational motion can produce linear motion in wheels, pulleys, winches and conveyor systems.
  • Meshing gears have equal tangential speeds at their contact point.
  • Smaller gears rotate faster than larger gears when their edges move at the same speed.
  • Radius is the key quantity connecting angular and linear motion.

Check Your Understanding

  1. State the relationship between angular displacement θ and arc length s.
  2. A wheel of radius 0.40 m rotates through 5 rad. Calculate the distance travelled by a point on its edge.
  3. A point on the edge of a 0.25 m radius disk travels 3.0 m along its circular path. Calculate the angular displacement.
  4. Explain why two points on the same rotating disk can have the same angular velocity but different linear speeds.
  5. A disk rotates at 8 rad/s. Calculate the tangential speed of a point 0.30 m from the centre.
  6. Two points are located 0.20 m and 0.80 m from the centre of a disk rotating at 5 rad/s. Calculate the tangential speed of each point.
  7. A wheel has radius 0.50 m and angular acceleration 6 rad/s². Calculate the tangential acceleration at its edge.
  8. A point 0.40 m from the axis rotates at 10 rad/s. Calculate its centripetal acceleration.
  9. If the angular velocity in Question 8 doubles while the radius remains unchanged, calculate the new centripetal acceleration and explain why it increases by that amount.
  10. A bicycle wheel has radius 0.35 m and rotates at 18 rad/s. Calculate the bicycle's speed assuming no slipping.
  11. A car travels at 24 m/s on wheels of radius 0.30 m. Calculate the angular velocity of the wheels.
  12. A pulley of radius 0.20 m rotates at 12 rad/s with angular acceleration 5 rad/s². Calculate the linear speed and acceleration of a rope that does not slip on the pulley.
  13. Gear A has radius 6 cm and rotates at 30 rad/s. It drives Gear B with radius 18 cm. Calculate Gear B's angular velocity and state its direction relative to Gear A.
  14. A rotating platform has angular velocity 3 rad/s. Two students stand 1.0 m and 2.5 m from the centre. Compare their angular velocities, tangential speeds and centripetal accelerations.
  15. A wheel of radius 0.40 m starts from rest and accelerates uniformly at 5 rad/s² for 4 s. Calculate its final angular velocity, angular displacement, linear distance travelled, final tangential speed, tangential acceleration and final centripetal acceleration.