Transformations of Graphs
5. Applications of Transformations
Learning outcomes
- I can apply transformations to solve problems.
- I can recognize transformations in real-life graphs.
- I can model situations using transformed functions.
- I can explain why transformations are useful.
- I can analyze transformed graphs.
Introduction
Graph transformations are not simply techniques for moving or changing the shape of mathematical graphs. They are powerful tools for understanding and modeling real-world situations.
Many relationships in science, economics, engineering, biology, and technology can be represented using familiar mathematical functions. Instead of constructing a completely new model for every situation, we can often transform an existing function to describe new conditions.
For example, consider the quadratic function:
y = x²
This is a basic mathematical model with a U-shaped graph.
Now consider:
h(t) = −5(t − 2)² + 25
This transformed quadratic function could represent the height of a projectile over time.
The transformations tell us that:
-
The graph opens downward because of the negative coefficient.
-
The vertical scale is changed by a factor of 5.
-
The maximum height occurs at t = 2 seconds.
-
The maximum height is 25 metres.
By recognising the transformations, we can understand important features of the model without performing lengthy calculations.
In this topic, we will explore how transformations are used to solve problems, recognise patterns in real-world graphs, build mathematical models, and interpret the meaning of transformed functions.
Why Are Transformations Useful?
A transformation allows us to modify a familiar mathematical relationship to represent a different situation.
For example, suppose a business has a cost function:
C(x) = 12x
This represents a production cost of $12 per item.
If the business must also pay a fixed operating cost of $500, the new function becomes:
C(x) = 12x + 500
The graph is translated upward by 500 units.
We do not need to develop a completely new mathematical structure. We simply adjust the original function.
Transformations are useful because they allow us to:
-
Adapt existing models to new conditions.
-
Predict how graphs change when parameters change.
-
Compare different scenarios.
-
Identify maximum and minimum values.
-
Interpret shifts in time or position.
-
Understand changes in amplitude, scale, and growth.
-
Simplify mathematical calculations.
-
Make predictions using transformed functions.
Reviewing the Main Transformations
Consider a parent function:
y = f(x)
The main transformations are:
|
Transformation |
Equation |
Effect |
|---|---|---|
|
Vertical translation |
y = f(x) + k |
Moves graph up or down |
|
Horizontal translation |
y = f(x − h) |
Moves graph right or left |
|
Reflection across x-axis |
y = −f(x) |
Reverses output signs |
|
Reflection across y-axis |
y = f(−x) |
Reverses input signs |
|
Vertical stretch |
y = af(x), a > 1 |
Multiplies outputs by a |
|
Vertical compression |
y = af(x), 0 < a < 1 |
Reduces output magnitudes |
|
Horizontal stretch |
y = f(x/b), b > 1 |
Increases horizontal distances |
|
Horizontal compression |
y = f(bx), b > 1 |
Decreases horizontal distances |
These transformations can be combined to represent more complicated situations.
General transformation model
A useful general equation is:
g(x) = af(b(x − h)) + k
where:
-
a controls vertical scaling and possible reflection.
-
b controls horizontal scaling and possible reflection.
-
h controls horizontal translation.
-
k controls vertical translation.
The values of these parameters can often be interpreted directly in a real-world context.
Recognising Transformations in Real-Life Graphs
When examining a real-world graph, look for changes in its important features.
Ask:
-
Has the graph moved upward or downward?
-
Does the same event occur earlier or later?
-
Have the maximum and minimum values changed?
-
Has the graph become steeper or flatter?
-
Has the period of a repeating pattern changed?
-
Has the graph been reflected?
-
Has the general shape remained the same?
Example: Comparing two temperature models
Suppose the temperature in one location is modeled by:
T₁(t) = 8 sin(πt/12) + 25
A second location has the model:
T₂(t) = 8 sin(πt/12) + 29
The second function is:
T₂(t) = T₁(t) + 4
Therefore, the second temperature graph is translated vertically upward by 4°C.
The models have:
-
The same amplitude.
-
The same period.
-
The same timing of maximum and minimum temperatures.
-
Different average temperatures.
The second location is modeled as being 4°C warmer at every corresponding time.
This is a simple example of how a vertical translation can represent a real-world difference.
Application: Projectile Motion
Projectile motion is one of the clearest applications of transformed quadratic functions.
When an object moves vertically under approximately constant gravitational acceleration, its height can be modeled by:
h(t) = h₀ + v₀t − ½gt²
where:
-
h(t) = height at time t.
-
h₀ = initial height.
-
v₀ = initial vertical velocity.
-
g = gravitational field strength.
-
t = time.
Near Earth's surface, g is approximately 9.8 m/s².
This equation is quadratic because it contains t².
Worked Example: A ball thrown upward
A ball is thrown upward from a platform 5 m above the ground with an initial vertical velocity of 20 m/s.
Using g = 10 m/s² for simplicity:
h(t) = 5 + 20t − 5t²
Rearrange:
h(t) = −5t² + 20t + 5
Step 1: Write in vertex form
Factor −5 from the quadratic terms:
h(t) = −5(t² − 4t) + 5
Complete the square:
t² − 4t = (t − 2)² − 4
Therefore:
h(t) = −5[(t − 2)² − 4] + 5
Expand:
h(t) = −5(t − 2)² + 25
Step 2: Interpret the transformations
Compared with y = x²:
-
Reflect across the x-axis.
-
Stretch vertically by a factor of 5.
-
Translate 2 units right.
-
Translate 25 units up.
Step 3: Identify the maximum height
The vertex is:
(2, 25)
Therefore:
Maximum height = 25 m
Time to maximum height = 2 s
Step 4: Find when the ball reaches the ground
Set h(t) = 0:
−5t² + 20t + 5 = 0
Divide by −5:
t² − 4t − 1 = 0
Apply the quadratic formula:
t = (4 ± √(16 + 4))/2
t = (4 ± √20)/2
t = 2 ± √5
The positive solution is:
t ≈ 4.24 s
The negative solution is not relevant because the model begins at t = 0.
The ball reaches the ground after approximately 4.24 seconds.
Why transformations are useful here
The vertex form makes the maximum height and its timing immediately visible.
We can also compare different launch conditions by examining how the parameters change.
For example, increasing the initial height while keeping the initial velocity unchanged translates the height-time graph upward.
Application: Business Revenue and Profit
Quadratic transformations are useful for modeling revenue and profit when these quantities depend on price or production.
Worked Example: Maximum profit
Suppose a business models its monthly profit using:
P(x) = −2(x − 40)² + 3200
where:
-
x = number of products sold, measured in hundreds.
-
P(x) = monthly profit in dollars.
Step 1: Identify the parent function
The parent function is:
y = x²
Step 2: Identify the transformations
The profit function has:
-
A reflection across the x-axis.
-
A vertical stretch by a factor of 2.
-
A horizontal translation 40 units right.
-
A vertical translation 3200 units up.
Step 3: Interpret the vertex
The vertex is:
(40, 3200)
Therefore:
Maximum modeled profit = $3,200
This occurs when x = 40, corresponding to 4,000 products sold.
Step 4: Compare different sales levels
At x = 30:
P(30) = −2(30 − 40)² + 3200
P(30) = −200 + 3200
P(30) = $3,000
At x = 50:
P(50) = −2(50 − 40)² + 3200
P(50) = $3,000
The model is symmetric about x = 40.
Interpretation
Selling 3,000 or 5,000 products gives the same modeled profit of $3,000.
The model suggests that profit decreases when sales move away from the optimal level.
This is an illustrative model; real business profit relationships may be more complicated.
Application: Comparing Production Costs
Linear functions are frequently used to model production costs.
Suppose a company has:
C₁(x) = 15x + 400
where:
-
x = number of products.
-
C₁(x) = total cost in dollars.
Now suppose the fixed operating cost increases by $200.
The new function becomes:
C₂(x) = 15x + 600
This is a vertical translation upward by 200 units.
Comparing the graphs
Both functions have gradient 15.
Therefore, the cost per additional product remains $15.
However, the second graph has a y-intercept of 600 instead of 400.
The difference between the functions is:
C₂(x) − C₁(x) = 200
This means the second production system costs $200 more at every production level.
Extension: Increasing variable costs
Suppose the variable cost increases from $15 to $18 per item, while the fixed cost stays at $400.
The new function is:
C₃(x) = 18x + 400
The gradient increases.
The graphs share the same y-intercept, but C₃(x) rises more quickly.
This is not a pure vertical stretch of the entire original function C₁(x), because a vertical stretch would also multiply the fixed cost.
Recognising this distinction is important when interpreting real-world models.
Application: Population Growth
Exponential functions are useful for modeling growth processes.
Suppose a population is modeled by:
P(t) = 500(1.08)ᵗ
where t is time in years.
The population begins at 500 and grows by 8% per year.
Scenario A: Doubling the initial population
If the initial population doubles but the growth rate remains unchanged:
P₂(t) = 1000(1.08)ᵗ
This can be written as:
P₂(t) = 2P(t)
The new graph is a vertical stretch by a factor of 2.
At every time t, the population is twice the original modeled population.
Scenario B: Growth begins 3 years later
Suppose the same growth pattern is delayed by 3 years.
A shifted model is:
P₃(t) = 500(1.08)⁽ᵗ ⁻ ³⁾
This is a horizontal translation 3 years to the right.
However, the model must be interpreted carefully.
If population growth is intended to begin only at t = 3, the shifted exponential model should be used for t ≥ 3, with the earlier period described separately.
Why transformations are useful
Transformations allow us to compare:
-
Different starting populations.
-
Different starting times.
-
Different measurement scales.
-
Growth patterns under different assumptions.
Application: Sound Waves and Oscillations
Many physical systems involve repeating patterns.
Examples include:
-
Sound waves.
-
Vibrating springs.
-
Pendulums at small angles.
-
Alternating electrical currents.
-
Rotating machinery.
These patterns can often be modeled using sine and cosine functions.
The general form is:
y = A sin(B(t − C)) + D
where:
-
A controls amplitude and possible reflection.
-
B controls the period.
-
C controls horizontal translation, or phase shift.
-
D controls vertical translation.
The amplitude is:
|A|
The period is:
2π/|B|
for B ≠ 0.
Worked Example: A vibrating object
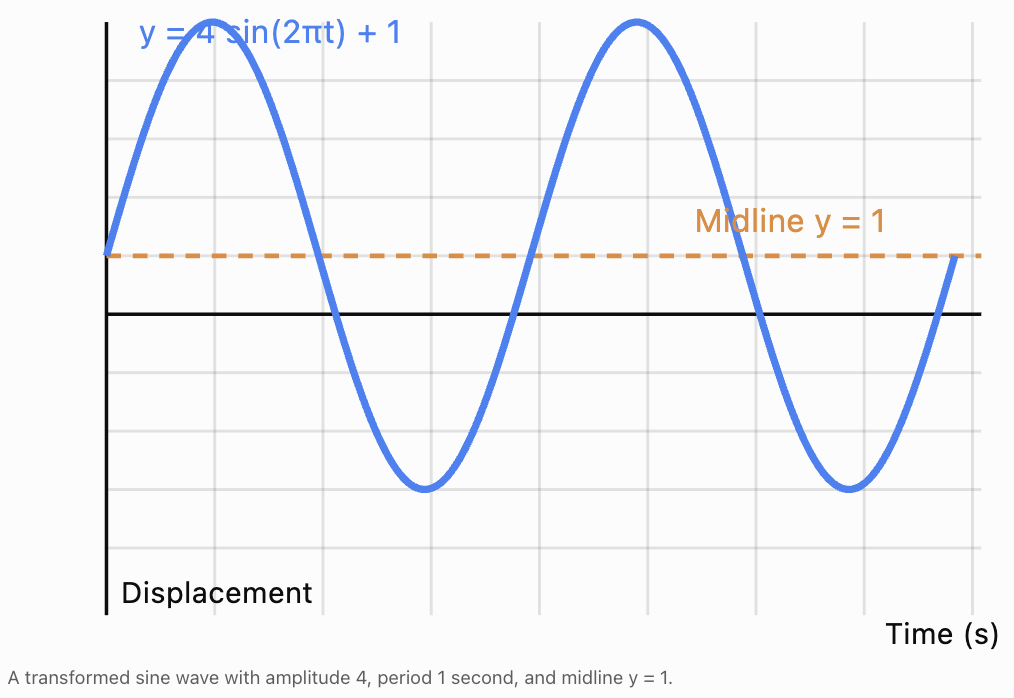
Suppose the displacement of a vibrating object is:
y = 4 sin(2πt) + 1
where y is measured in centimetres and t in seconds.
Step 1: Identify the amplitude
A = 4
Therefore:
Amplitude = 4 cm
Step 2: Identify the period
B = 2π
Period = 2π/(2π)
Period = 1 s
Step 3: Identify the vertical translation
D = 1
The graph is translated upward by 1 cm.
Its midline is:
y = 1
Step 4: Determine maximum and minimum displacement
Maximum:
1 + 4 = 5 cm
Minimum:
1 − 4 = −3 cm
Interpretation
The object oscillates around a position 1 cm above the original reference level.
Its maximum displacement from that midline is 4 cm.
It completes one full cycle every second.
Application: Electrical Signals
Electronic signals can be modified using transformations.
Suppose an electrical signal is represented by:
V(t) = 2 sin(100πt)
where V is voltage in volts and t is time in seconds.
Increasing the amplitude
If the signal is amplified by a factor of 3:
V₂(t) = 6 sin(100πt)
This is a vertical stretch by a factor of 3.
The amplitude increases from 2 V to 6 V.
Introducing a time delay
If the signal is delayed by 0.005 seconds:
V₃(t) = 2 sin[100π(t − 0.005)]
This is a horizontal translation 0.005 seconds to the right.
Reversing polarity
If the signal's polarity is reversed:
V₄(t) = −2 sin(100πt)
This is a reflection across the horizontal axis.
Why transformations are useful
Engineers use these mathematical ideas to understand:
-
Signal amplification.
-
Time delays.
-
Phase differences.
-
Signal inversion.
-
Changes in frequency.
Application: Medical and Biological Signals
Some biological processes produce repeating electrical or mechanical patterns.
Examples include heartbeats, breathing cycles, and certain neural signals.
A simplified periodic signal might be modeled by:
S(t) = 2 sin(π(t − 1)) + 5
Compared with y = sin t:
-
Vertical stretch by factor 2.
-
Horizontal compression by factor 1/π.
-
Translation 1 time unit right.
-
Translation 5 units up.
The midline is 5.
The amplitude is 2.
The period is:
2π/π = 2 time units.
Real biological signals are often more complex than simple sine waves, but transformed functions can help describe basic features such as amplitude, timing, and frequency.
Application: Transformations in Geometry and Computer Graphics
Transformations are widely used in computer graphics, animation, engineering design, and digital mapping.
A point in a two-dimensional coordinate system can be transformed using coordinate rules.
Translation
Move a point h units horizontally and k units vertically:
(x, y) → (x + h, y + k)
Reflection across the x-axis
(x, y) → (x, −y)
Reflection across the y-axis
(x, y) → (−x, y)
Vertical scaling
(x, y) → (x, ay)
Horizontal scaling
(x, y) → (bx, y)
Worked Example: Transforming a digital shape
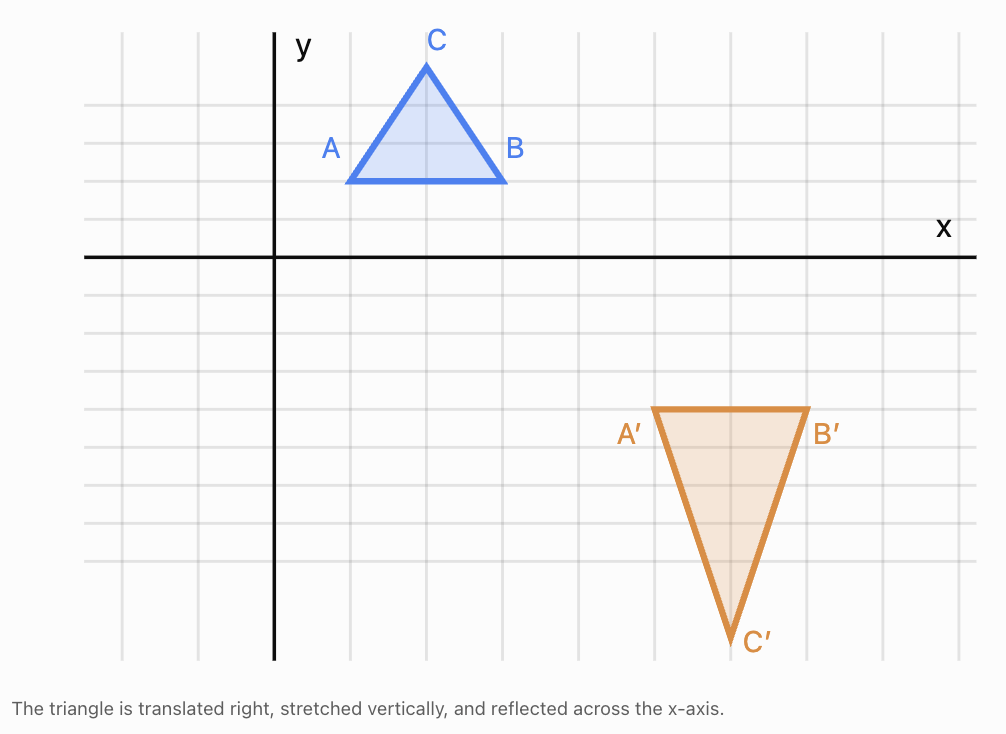
A triangle has vertices:
A(1, 2)
B(3, 2)
C(2, 5)
The triangle undergoes:
-
A horizontal translation 4 units right.
-
A vertical stretch by factor 2.
-
A reflection across the x-axis.
Step 1: Write the coordinate rule
The combined rule is:
(x, y) → (x + 4, −2y)
Step 2: Transform each vertex
A(1, 2):
A′ = (5, −4)
B(3, 2):
B′ = (7, −4)
C(2, 5):
C′ = (6, −10)
Step 3: Interpret the result
The triangle has moved right, become twice as tall, and been reflected vertically.
Unlike a pure translation or reflection, the vertical stretch changes its shape.
Modeling Real Situations Using Transformed Functions
When building a mathematical model, begin by identifying the general shape of the relationship.
Step 1: Identify the parent function
Ask whether the situation resembles:
-
A straight line.
-
A parabola.
-
An exponential curve.
-
A square root curve.
-
A periodic sine or cosine wave.
Step 2: Identify important features
These might include:
-
Starting value.
-
Maximum or minimum.
-
Time of an important event.
-
Rate of change.
-
Amplitude.
-
Period.
-
Long-term behaviour.
Step 3: Select transformations
Use translations, stretches, compressions, or reflections to match the required features.
Step 4: Construct the equation
For example, a quadratic model can be written:
y = a(x − h)² + k
The vertex is (h, k).
The value of a controls the vertical scale and direction of opening.
Step 5: Verify the model
Substitute known data points and check whether the model satisfies the conditions.
Step 6: Evaluate limitations
A mathematical model is a simplified representation of reality.
Its accuracy depends on the assumptions and the range of values for which it is used.
Worked Example: Building a Quadratic Model
A water fountain produces an arch of water.
The water reaches a maximum height of 4 m at a horizontal distance of 2 m from the nozzle.
The nozzle is located at ground level.
Find a quadratic equation modeling the height of the water.
Step 1: Choose the model
Use vertex form:
h(x) = a(x − p)² + q
The vertex is (2, 4).
Therefore:
h(x) = a(x − 2)² + 4
Step 2: Use the starting point
The water begins at (0, 0).
Substitute:
0 = a(0 − 2)² + 4
0 = 4a + 4
a = −1
Step 3: Write the equation
h(x) = −(x − 2)² + 4
Step 4: Determine where the water lands
Set h(x) = 0:
0 = −(x − 2)² + 4
(x − 2)² = 4
x − 2 = ±2
x = 0 or x = 4
The water returns to ground level at:
x = 4 m
Interpretation
The water travels 4 m horizontally from the nozzle before returning to the ground.
The model assumes an ideal parabolic trajectory and ignores air resistance and other effects.
Analyzing Transformed Graphs
When analyzing a transformed graph, consider the following questions.
What is the parent function?
Identify the familiar graph shape.
Which transformations have occurred?
Look for translations, reflections, stretches, and compressions.
What are the important features?
Determine vertices, intercepts, asymptotes, maxima, minima, and other significant points.
What do the parameters mean?
Relate each parameter to the real-world situation.
What are the domain and range?
Identify the mathematically permitted values and the values that make sense in context.
What predictions can the model make?
Use the equation to calculate unknown values.
What are the model's limitations?
Consider whether the assumptions remain reasonable outside the observed data.
Example: Interpreting a transformed graph
Suppose a model is:
y = −3(x − 5)² + 75
We can immediately identify:
-
Parent function: y = x².
-
Reflection across the x-axis.
-
Vertical stretch by factor 3.
-
Translation 5 units right.
-
Translation 75 units up.
-
Vertex: (5, 75).
-
Maximum value: 75.
-
Axis of symmetry: x = 5.
If y represents height, this might describe an object reaching a maximum height of 75 units when x = 5.
If y represents profit, it might describe a maximum profit of 75 units at an input value of 5.
The mathematical structure is the same, but the interpretation depends on the context.
Comparing Multiple Transformed Models
Suppose three objects follow these height models:
A: h(t) = −5(t − 2)² + 20
B: h(t) = −5(t − 2)² + 30
C: h(t) = −10(t − 2)² + 20
Comparing A and B
Model B is a vertical translation of Model A upward by 10 m.
Both objects:
-
Reach their maximum height at t = 2 s.
-
Have the same quadratic coefficient.
-
Have the same curvature.
However, Model B is always 10 m higher than Model A at corresponding times.
Comparing A and C
Model C has a quadratic coefficient of −10 rather than −5.
Compared with Model A, its vertical deviations from the shared maximum height of 20 m are doubled.
Model C therefore has a narrower parabola.
Both models have their maximum at:
(2, 20)
However, Model C decreases more rapidly as t moves away from 2.
Comparison table
|
Feature |
Model A |
Model B |
Model C |
|---|---|---|---|
|
Maximum height |
20 m |
30 m |
20 m |
|
Time of maximum |
2 s |
2 s |
2 s |
|
Quadratic coefficient |
−5 |
−5 |
−10 |
|
Graph width |
Standard relative to A |
Same as A |
Narrower |
|
Axis of symmetry |
t = 2 |
t = 2 |
t = 2 |
This comparison shows how transformed equations allow us to understand several models without plotting every point.
Evaluating the Usefulness of Transformations
Transformations are particularly valuable when we want to compare models that share a common mathematical structure.
They can help us:
-
Identify changes quickly.
-
Reduce the amount of calculation required.
-
Explain differences between related situations.
-
Estimate important values.
-
Predict the effects of changing parameters.
-
Communicate mathematical relationships clearly.
However, transformations do not guarantee that a model accurately represents reality.
A good model must also be supported by appropriate assumptions and data.
For example, a transformed quadratic may accurately describe the short-term motion of a projectile, but it may not be suitable for modeling the entire flight of an object experiencing significant air resistance.
Similarly, an exponential growth model may work over a limited period but become unrealistic when resources are limited.
Common Mistakes
Confusing mathematical transformations with real-world changes
A vertical translation represents adding the same amount to every output. Not every real-world increase is a vertical translation.
Ignoring units
A vertical shift of 5 might represent 5 metres, 5 dollars, or 5°C depending on the context.
Misinterpreting the vertex
In a quadratic model, the vertex may represent a maximum or minimum. Its meaning depends on the situation.
Confusing stretches with translations
Multiplying outputs changes their scale, while adding a constant shifts them vertically.
Forgetting horizontal translation directions
In f(x − 3), the graph moves 3 units right.
Using unrealistic domains
A time model may be mathematically defined for negative values, but negative time may not be meaningful in the problem.
Assuming a model is valid indefinitely
Real-world relationships often have practical limits.
Failing to check the equation against known data
A model should reproduce the given conditions.
Assuming every parameter has an independent physical meaning
Some mathematical transformations can be described in different ways. The interpretation should be supported by the context.
Key Terms
-
Transformation: A change to the position, orientation, or scale of a graph.
-
Mathematical model: An equation or mathematical relationship representing a real-world situation.
-
Parent function: A basic function used as the starting point for transformations.
-
Translation: A transformation moving a graph horizontally or vertically.
-
Reflection: A transformation producing a mirror image across a line.
-
Vertical stretch: Multiplying all outputs by a factor greater than 1.
-
Vertical compression: Multiplying all outputs by a positive factor less than 1.
-
Horizontal stretch: Increasing horizontal distances by a scale factor.
-
Horizontal compression: Decreasing horizontal distances by a scale factor.
-
Scale factor: A multiplier describing how coordinates or distances change.
-
Vertex: The turning point of a parabola.
-
Maximum value: The greatest output of a function over its specified domain.
-
Minimum value: The smallest output of a function over its specified domain.
-
Amplitude: The maximum displacement of a periodic function from its midline.
-
Period: The interval required for one complete cycle.
-
Phase shift: A horizontal translation of a periodic function.
-
Midline: The central horizontal line around which a periodic function oscillates.
-
Domain: The set of allowed input values.
-
Range: The set of possible output values.
-
Asymptote: A line approached by a graph in a specified limiting direction.
-
Model assumptions: Conditions accepted as true when constructing a mathematical model.
-
Model limitations: Factors restricting how accurately or widely a model can be applied.
Key Takeaways
-
Graph transformations are useful for adapting mathematical models to new situations.
-
Vertical translations can represent fixed increases or decreases.
-
Horizontal translations can represent time delays or shifts in position.
-
Vertical stretches and compressions can represent changes in amplitude or scale.
-
Reflections can represent changes in direction or sign.
-
Quadratic transformations help identify maximum and minimum values.
-
Exponential transformations help compare growth processes.
-
Trigonometric transformations help model periodic phenomena.
-
Transformations allow related models to be compared efficiently.
-
Real-world interpretation requires attention to units, domains, and assumptions.
-
Mathematical models should be verified using known information.
-
The usefulness of a transformed function depends on how well it represents the situation being studied.
Check Your Understanding
Recall and Understanding
1. Explain why graph transformations are useful in mathematical modeling.
2. Give a real-world example of a vertical translation.
3. Explain how a horizontal translation might represent a time delay.
4. Describe the difference between increasing the amplitude and increasing the frequency of a periodic function.
Application
5. A company's cost function is C(x) = 20x + 300. Fixed costs increase by $150. Write the new cost function and describe the transformation.
6. A population is modeled by P(t) = 400(1.05)ᵗ. The initial population doubles while the growth rate remains unchanged. Write the new function.
7. A vibrating object has displacement y = 3 sin(2πt). Its amplitude increases by a factor of 2. Write the new equation and state its amplitude.
8. A quadratic function is given by h(t) = −5(t − 3)² + 45. Determine the maximum height and the time at which it occurs.
9. A business models profit using P(x) = −4(x − 20)² + 2000. Determine the maximum profit and the value of x at which it occurs.
10. A signal is represented by V(t) = 5 sin(10t). Write the equation after a reflection across the horizontal axis.
Analysis and Challenge
11. A ball is thrown upward from ground level with an initial vertical velocity of 30 m/s. Using g = 10 m/s², construct a quadratic height model and determine its maximum height.
12. A fountain produces a parabolic water arc with a maximum height of 6 m at a horizontal distance of 3 m from the nozzle. The water begins at ground level. Find an equation for the arc and determine where the water lands.
13. Compare the functions:
A: y = −2(x − 4)² + 30
B: y = −2(x − 4)² + 40
C: y = −4(x − 4)² + 30
Describe the transformations and compare their maximum values.
14. A periodic function is modeled by y = 5 sin(π(t − 2)) + 10. Determine its amplitude, period, phase shift, midline, maximum, and minimum.
15. A student claims that doubling the fixed costs of a business always produces a vertical stretch of its total cost graph. Explain why this is incorrect.
Answers to Check Your Understanding
1. Transformations allow familiar functions to be adapted to new situations without constructing completely new models. They help us interpret changes, compare scenarios, and make predictions.
2. An increase in a company's fixed operating costs adds the same amount to the total cost at every production level, producing a vertical translation upward.
3. Replacing f(t) with f(t − h), where h > 0, moves the graph h time units to the right. This can represent an event occurring later.
4. Increasing amplitude changes the maximum displacement from the midline. Increasing frequency increases the number of cycles per unit time and decreases the period.
5.
Original:
C(x) = 20x + 300
New fixed cost:
300 + 150 = 450
C(x) = 20x + 450
Transformation: Vertical translation upward by 150.
6.
Original:
P(t) = 400(1.05)ᵗ
Double the initial population:
P₂(t) = 800(1.05)ᵗ
This is a vertical stretch by factor 2.
7.
Original:
y = 3 sin(2πt)
Double the amplitude:
y = 6 sin(2πt)
Amplitude = 6.
8.
h(t) = −5(t − 3)² + 45
Vertex:
(3, 45)
Maximum height = 45 m
Time = 3 s
9.
P(x) = −4(x − 20)² + 2000
Vertex:
(20, 2000)
Maximum profit = $2,000
This occurs at x = 20.
10.
Original:
V(t) = 5 sin(10t)
Reflection across the horizontal axis:
V(t) = −5 sin(10t)
11.
Use:
h(t) = v₀t − ½gt²
Substitute:
h(t) = 30t − 5t²
Complete the square:
h(t) = −5(t² − 6t)
h(t) = −5[(t − 3)² − 9]
h(t) = −5(t − 3)² + 45
Vertex:
(3, 45)
Maximum height = 45 m
This occurs after 3 seconds.
12.
Use vertex form:
h(x) = a(x − 3)² + 6
The water begins at (0, 0).
Substitute:
0 = a(0 − 3)² + 6
0 = 9a + 6
a = −6/9 = −2/3
Therefore:
h(x) = −(2/3)(x − 3)² + 6
To find where the water lands:
0 = −(2/3)(x − 3)² + 6
(2/3)(x − 3)² = 6
(x − 3)² = 9
x − 3 = ±3
x = 0 or x = 6
The water lands at:
x = 6 m
13.
Model A:
y = −2(x − 4)² + 30
Maximum = 30 at x = 4.
Model B:
y = −2(x − 4)² + 40
Maximum = 40 at x = 4.
Model C:
y = −4(x − 4)² + 30
Maximum = 30 at x = 4.
Comparison:
-
B is A translated upward by 10 units.
-
C has the same vertex as A but is vertically stretched by factor 2 relative to its vertex level, making it narrower.
-
All three graphs open downward.
-
All three have their maximum at x = 4.
14.
Given:
y = 5 sin(π(t − 2)) + 10
Amplitude:
5
Period:
2π/π = 2
Phase shift:
2 units right
Midline:
y = 10
Maximum:
10 + 5 = 15
Minimum:
10 − 5 = 5
15.
Doubling fixed costs changes the constant term of a cost function, not necessarily every output by the same factor.
For example:
Original:
C(x) = 10x + 200
Doubling fixed costs:
C₂(x) = 10x + 400
This is a vertical translation upward by 200.
A vertical stretch by factor 2 would instead give:
2C(x) = 20x + 400
This doubles both the variable cost and the fixed cost.
Therefore, doubling fixed costs does not generally produce a vertical stretch of the total cost graph.
Final Summary
Applications of transformations demonstrate how familiar mathematical functions can be adapted to represent real-world situations.
Translations can model shifts in position, time, or baseline values. Stretches and compressions can represent changes in scale or amplitude. Reflections can represent reversals in direction or sign.
By recognising these transformations, we can construct models, compare different scenarios, identify important graph features, and make useful predictions.
The central idea is that understanding how a function changes is often just as important as knowing the function itself.